Application case of integrated stepper/servo motor in three-axis conveyor platform equipment
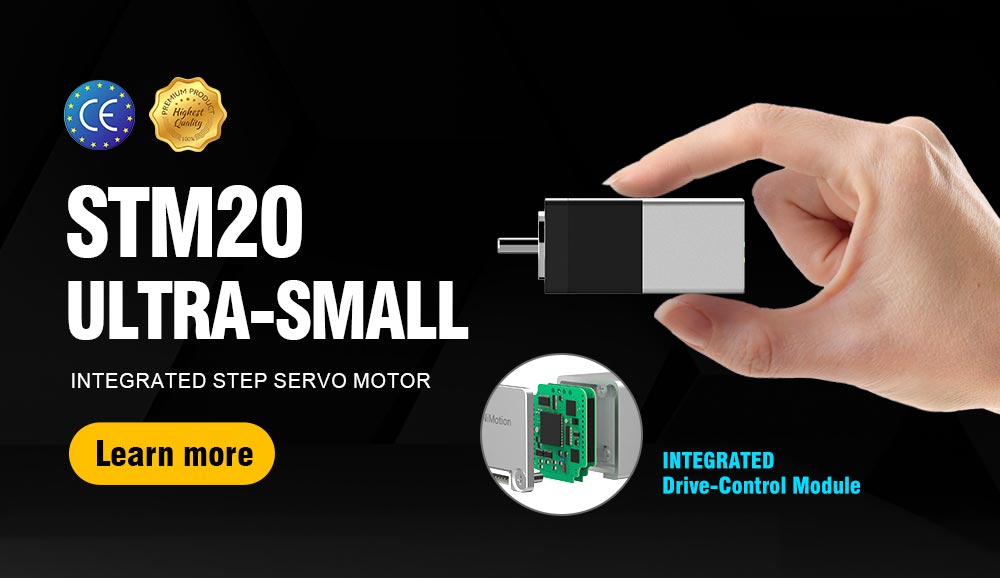
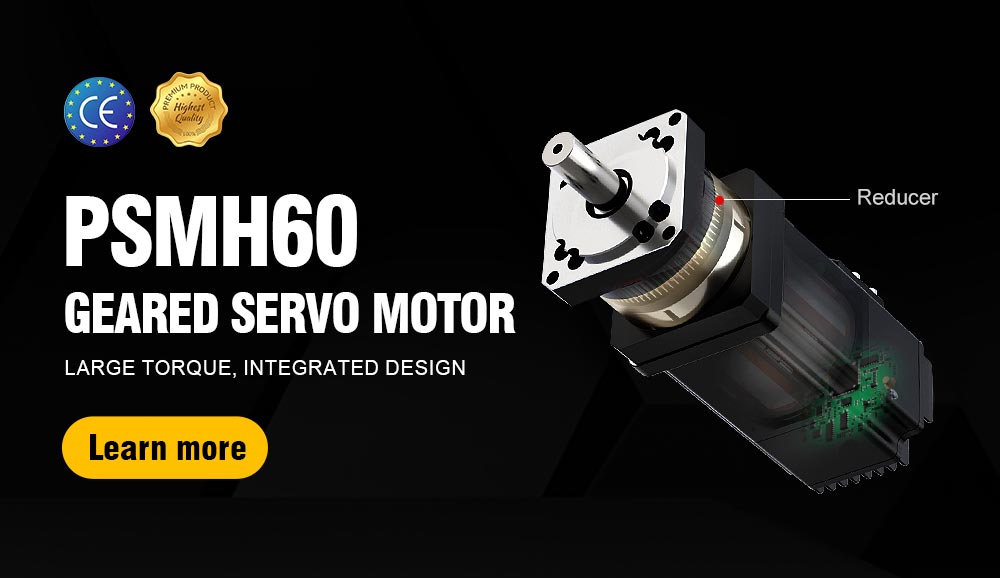
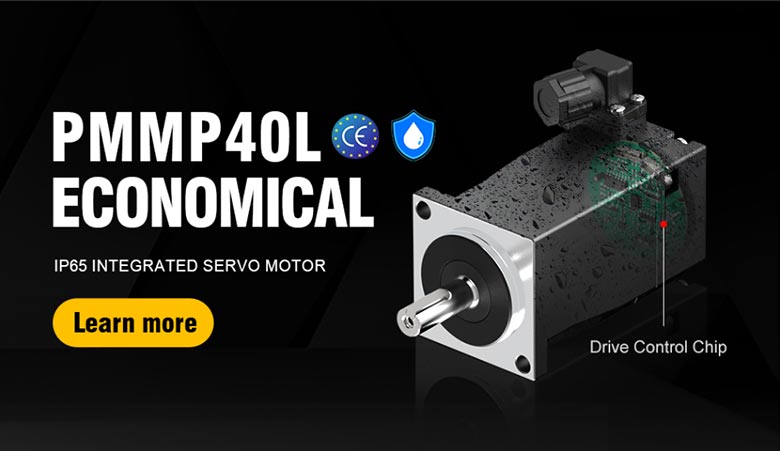
In the field of logistics automation, three-axis conveyor platforms are core equipment for precise cargo sorting and efficient transfer. To address the issues of insufficient positioning accuracy and low multi-axis coordination efficiency in traditional conveyor equipment, a combination of the PMM6040 integrated servo motor and the STM86M/57M integrated stepper motor is employed. This solution achieves three-axis linkage control through contour positioning mode, significantly improving the conveyor platform's operational accuracy and efficiency.
1. Equipment Overview
The three-axis conveyor platform consists of three linear motion axes: X, Y, and Z. Core requirements include:
Multi-axis coordination: Synchronous control of the three axes is required, with positioning accuracy of ±0.1mm;
Load adaptation: The Z axis must overcome gravity loads, and the X/Y axes must accommodate differences in belt/gear transmissions;
Dynamic response: A single handling cycle of ≤3 seconds is required.
2. Application Solutions and Products
(1) Core Product Configuration
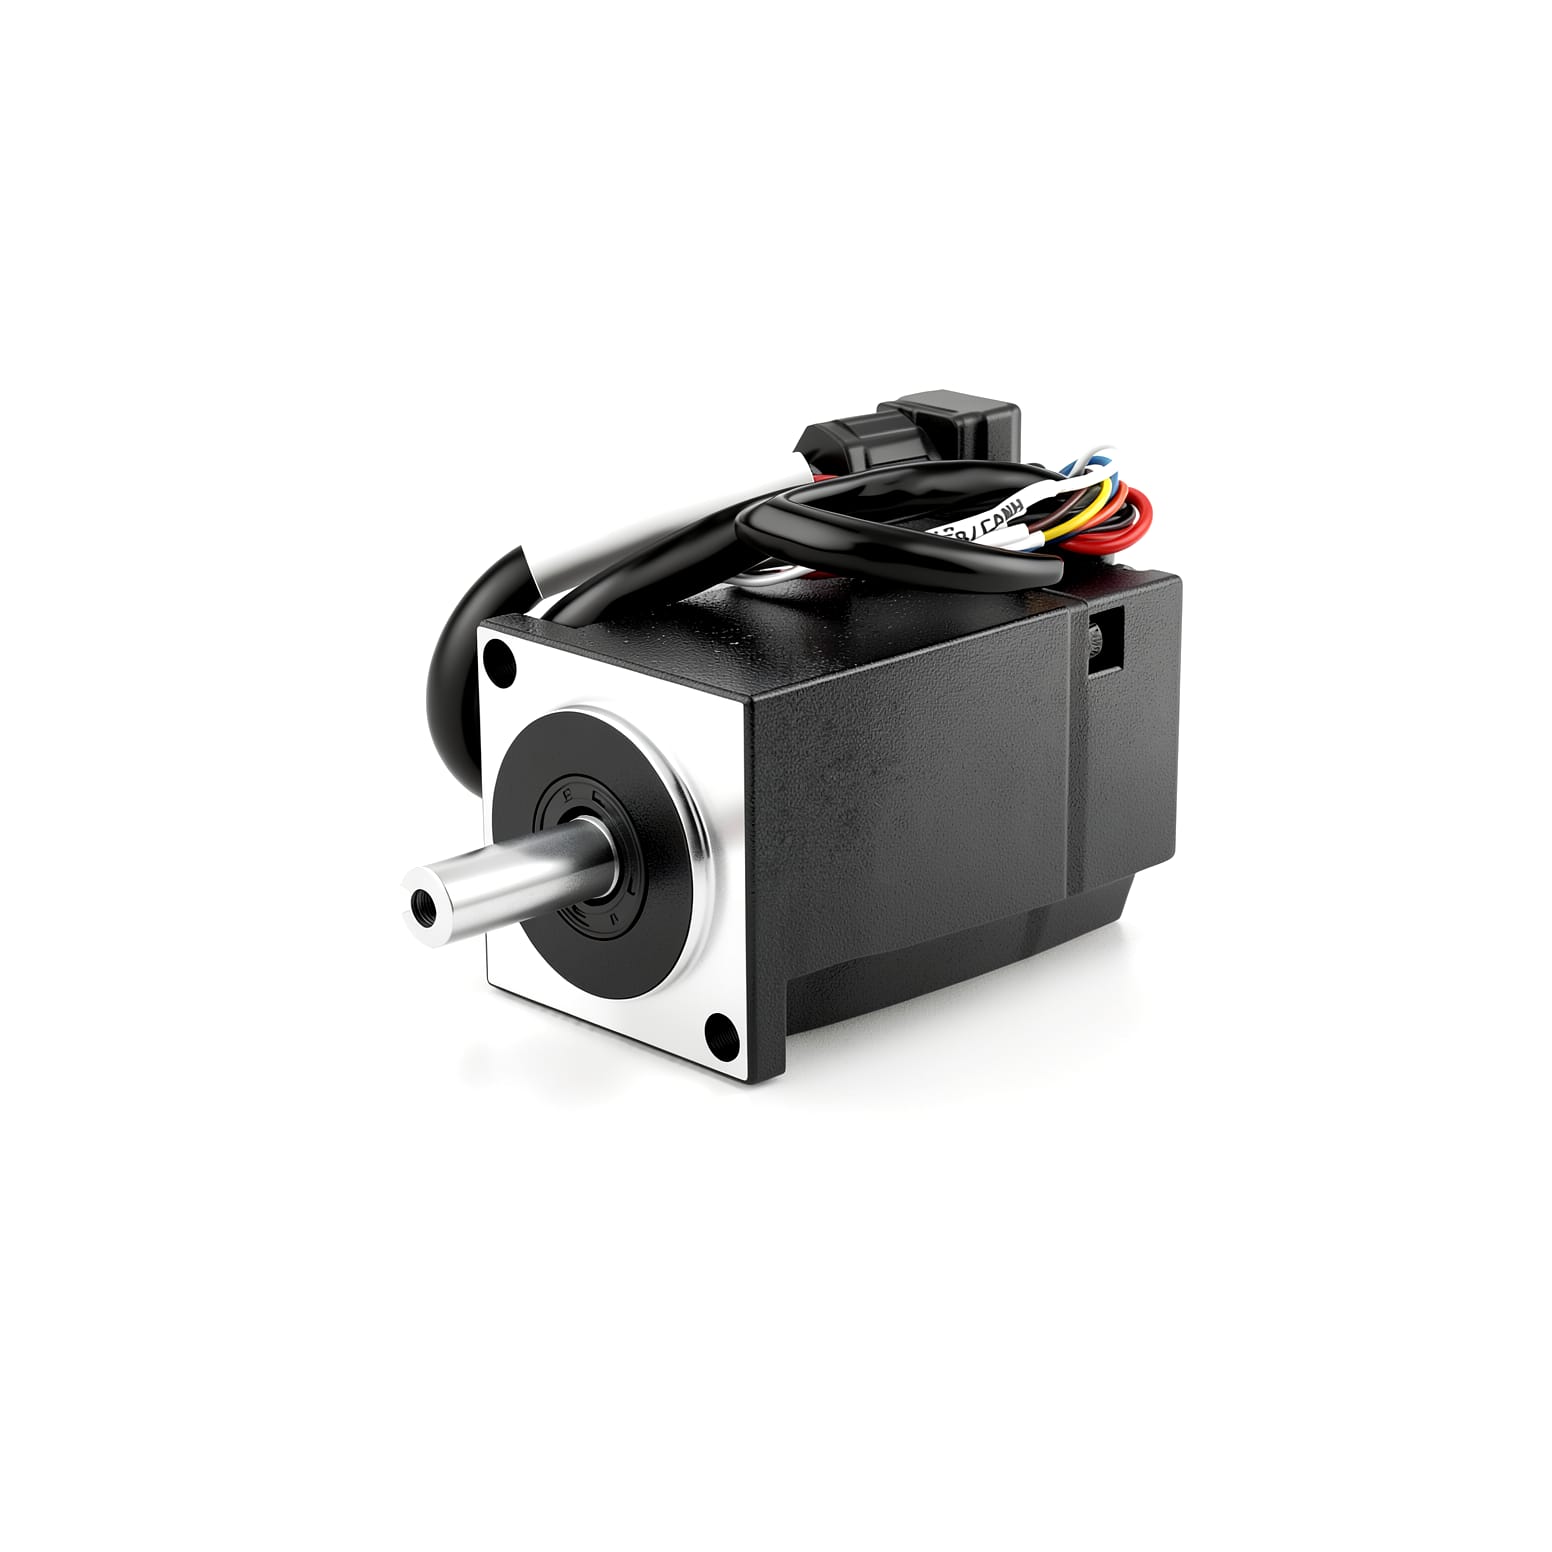
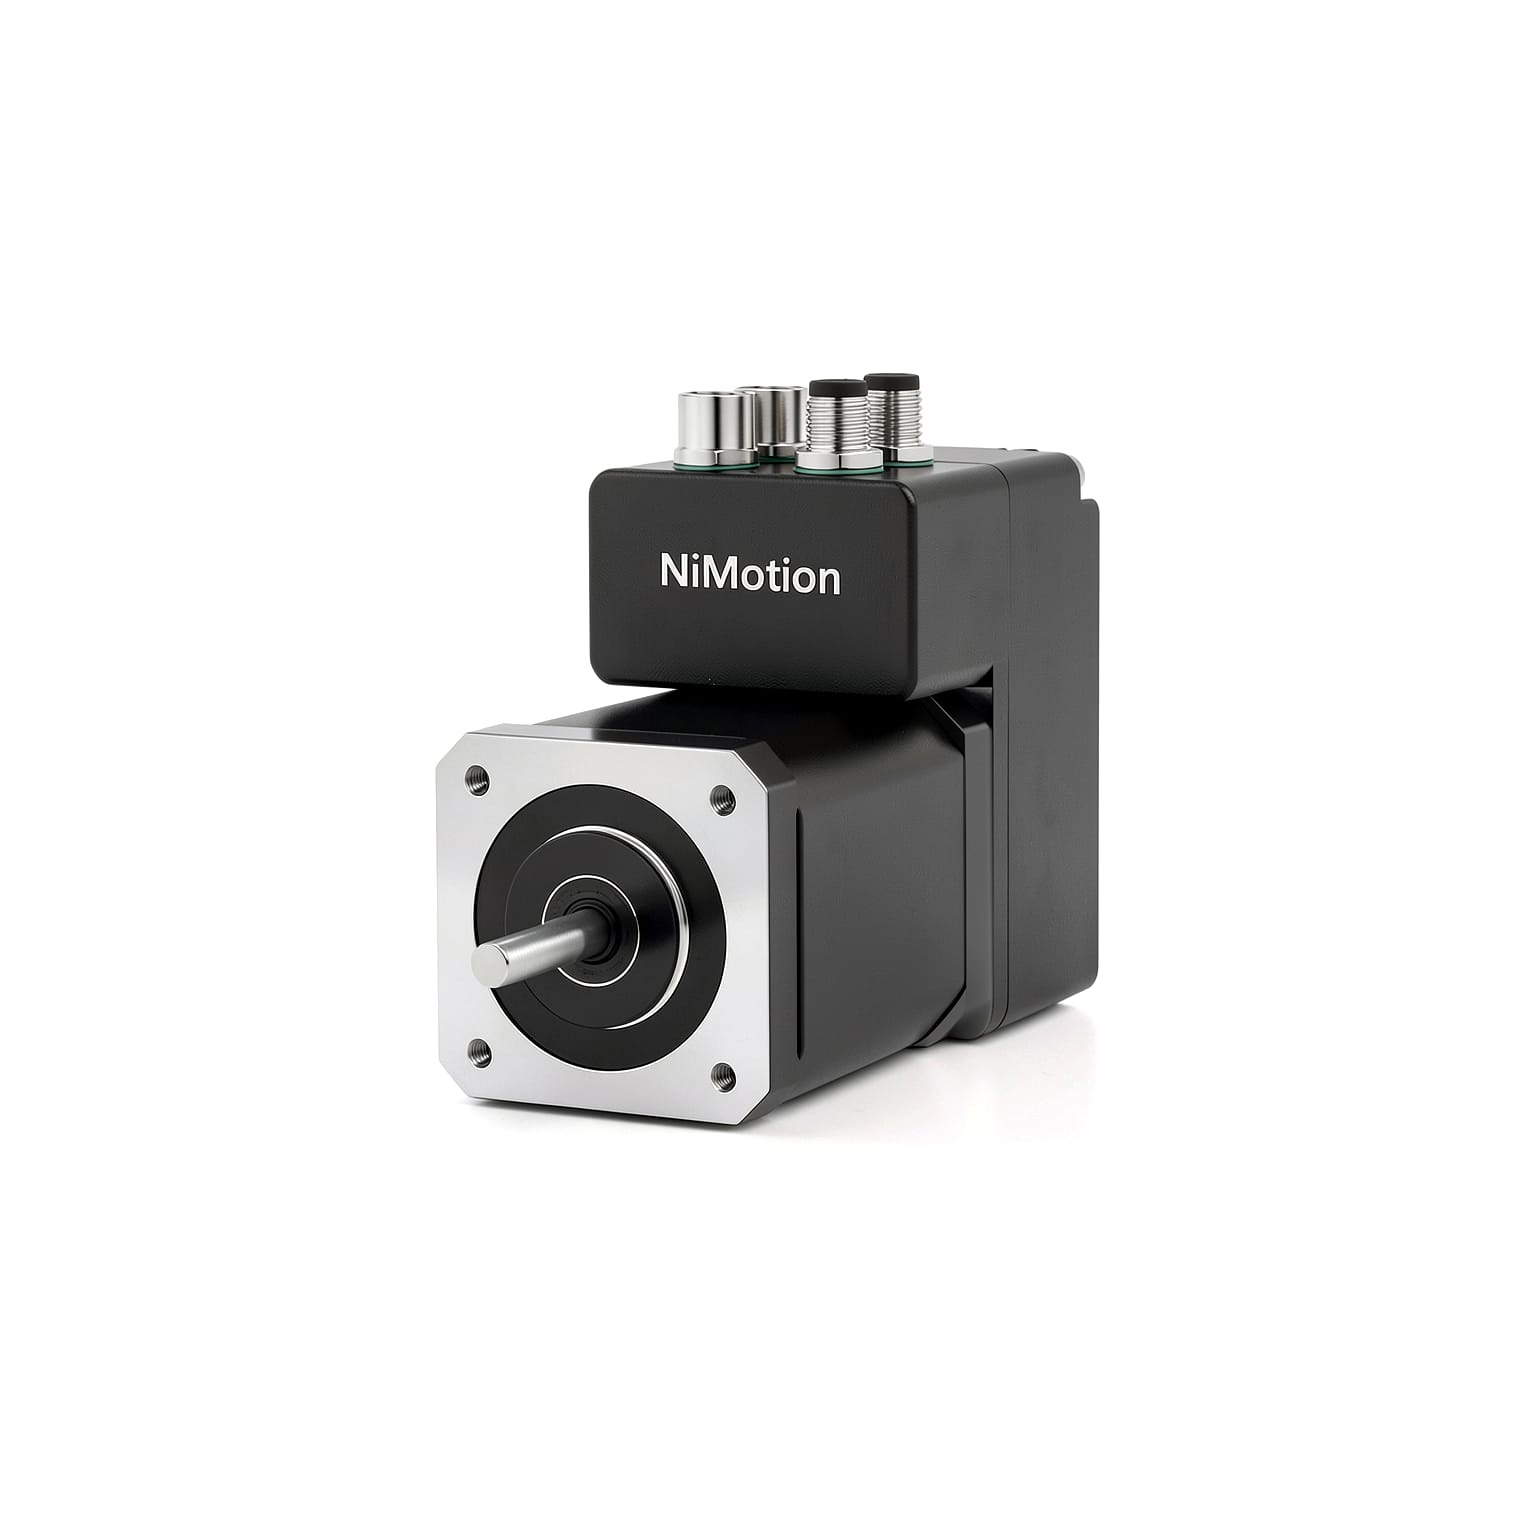
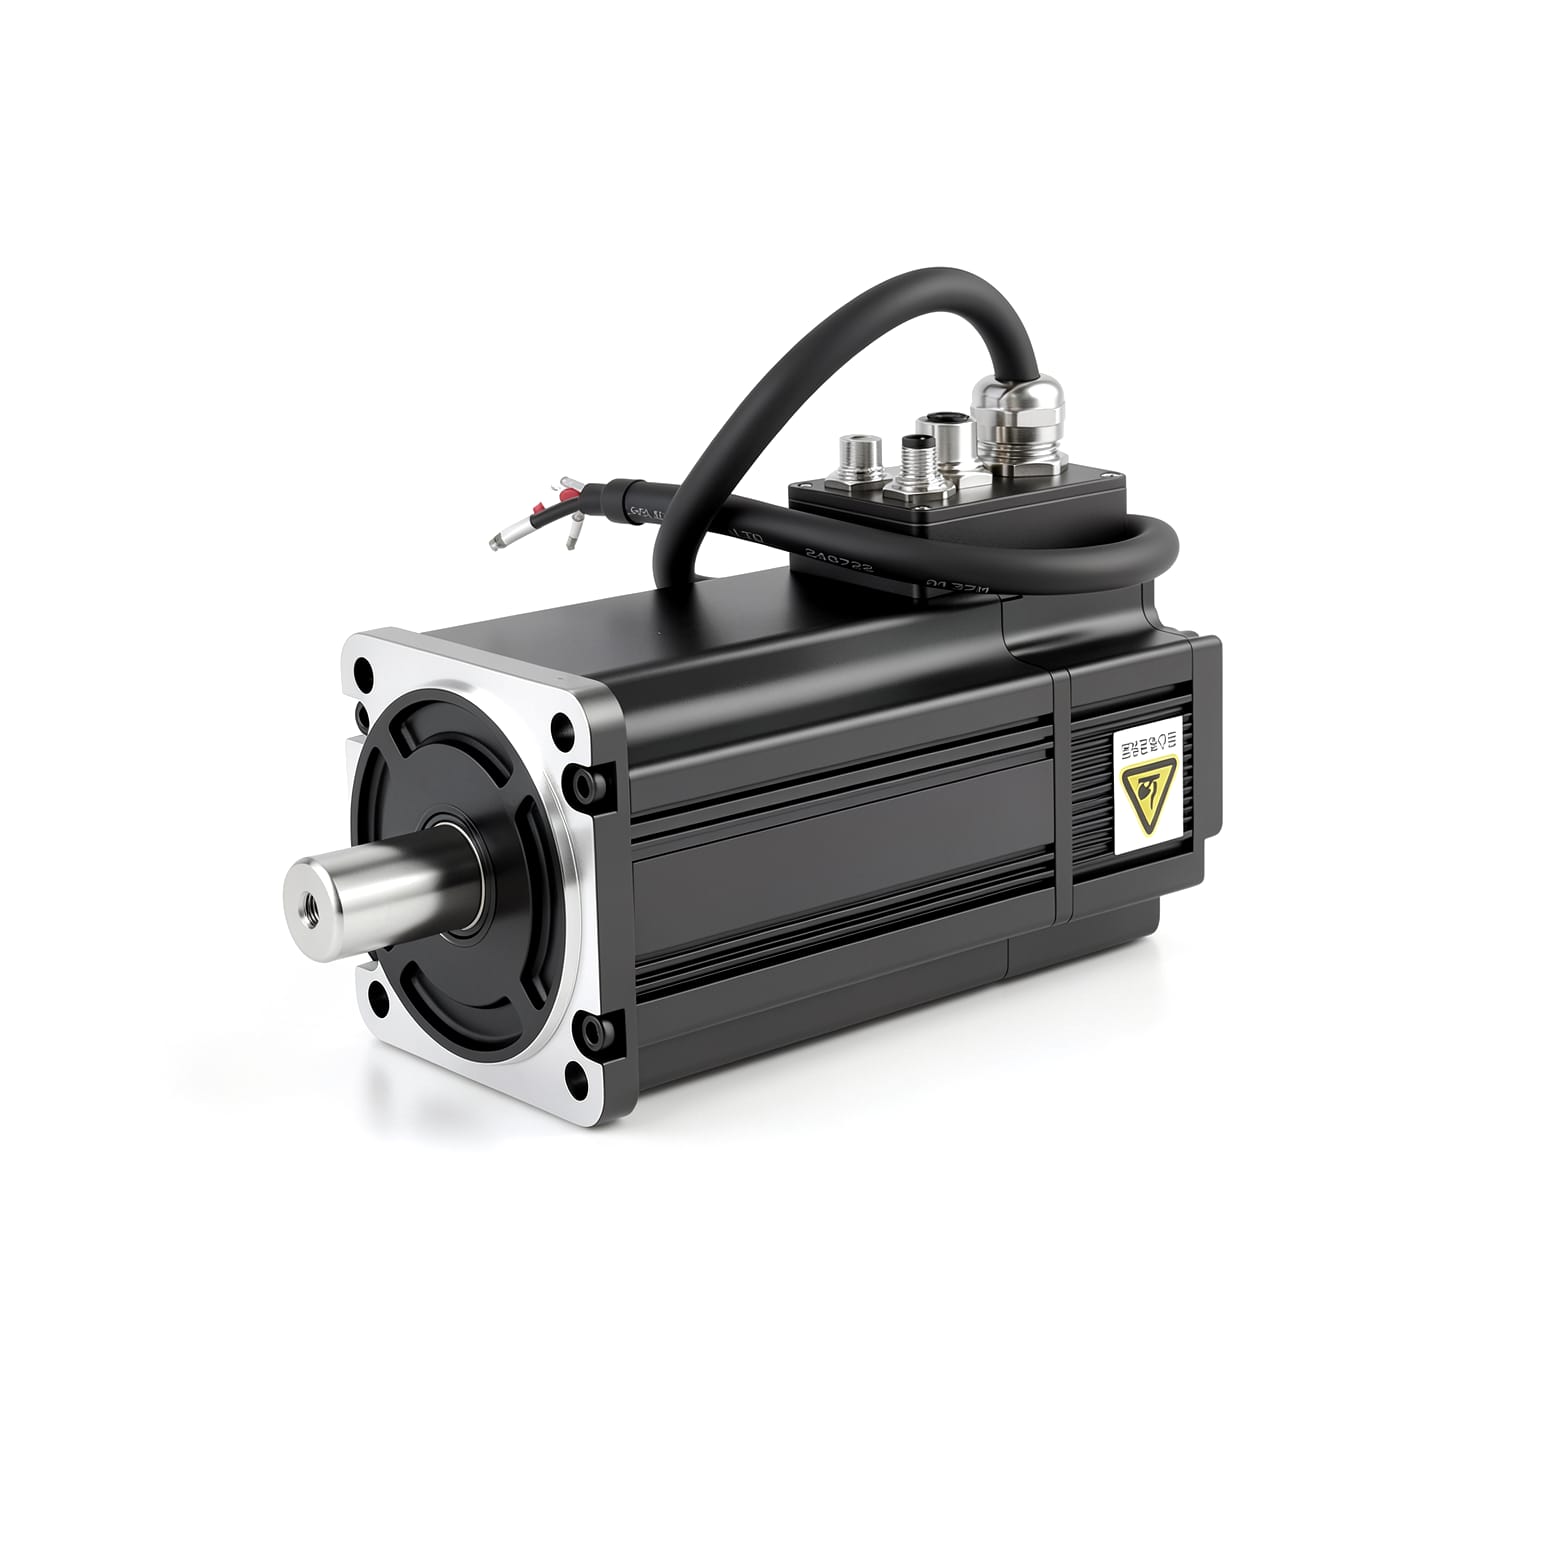
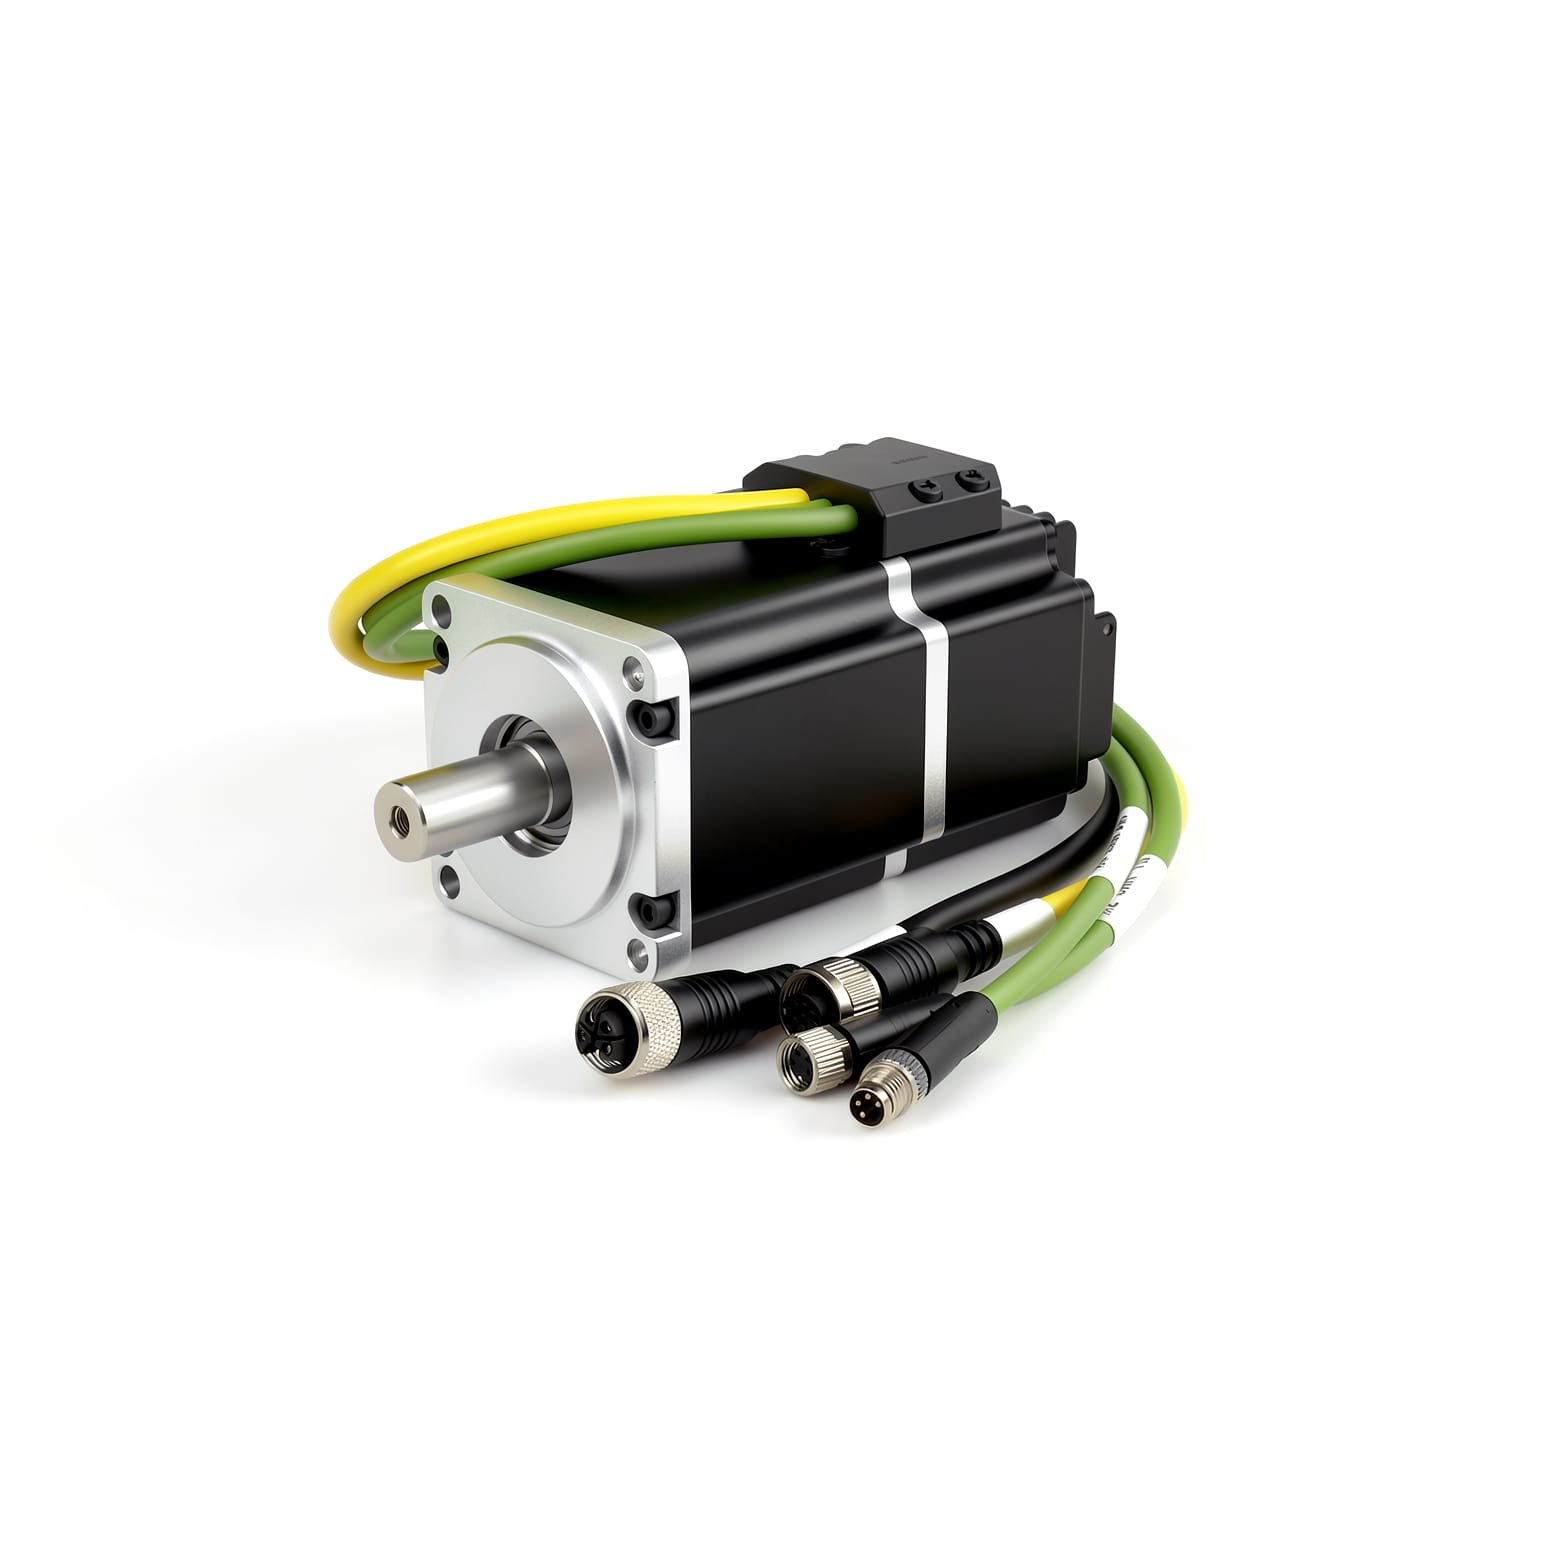
AxisDrive SelectionTransmission TypeLoad CharacteristicsX-axisPMM6040 servo motor + reducerBelt driveModerate output torqueY-axisSTM57M stepper motorRack and pinion driveLight loadZ-axisSTM86M stepper motor + reducerVertical loadHigh torque requirement
(2) Control Strategy
Uses the "Profile Position Mode" to plan motion trajectories and achieve three-axis interpolation motion;
Synchronizes X/Y-axis motion using the electronic cam function to prevent material jitter.
3. Application Results
Improved Precision: Three-axis repeatability reaches ±0.08mm, reducing the sorting error rate to 0.05%;
Optimized Energy Efficiency: The servo-stepper hybrid solution consumes 25% less energy than a full stepper system;
Easier Maintenance: The integrated motor design eliminates the need for external drivers and reduces troubleshooting time by 40%.
4. Summary
This case study achieved a balance between precision, efficiency, and cost for a three-axis conveyor platform through the differentiated configuration of servo and stepper motors. This solution validates the feasibility of hybrid drive strategies in logistics equipment and provides a standardized reference for scenarios such as warehouse sorting and production line material handling. Future applications can be expanded to include complex scenarios such as four-axis robotic arm collaborative operations.