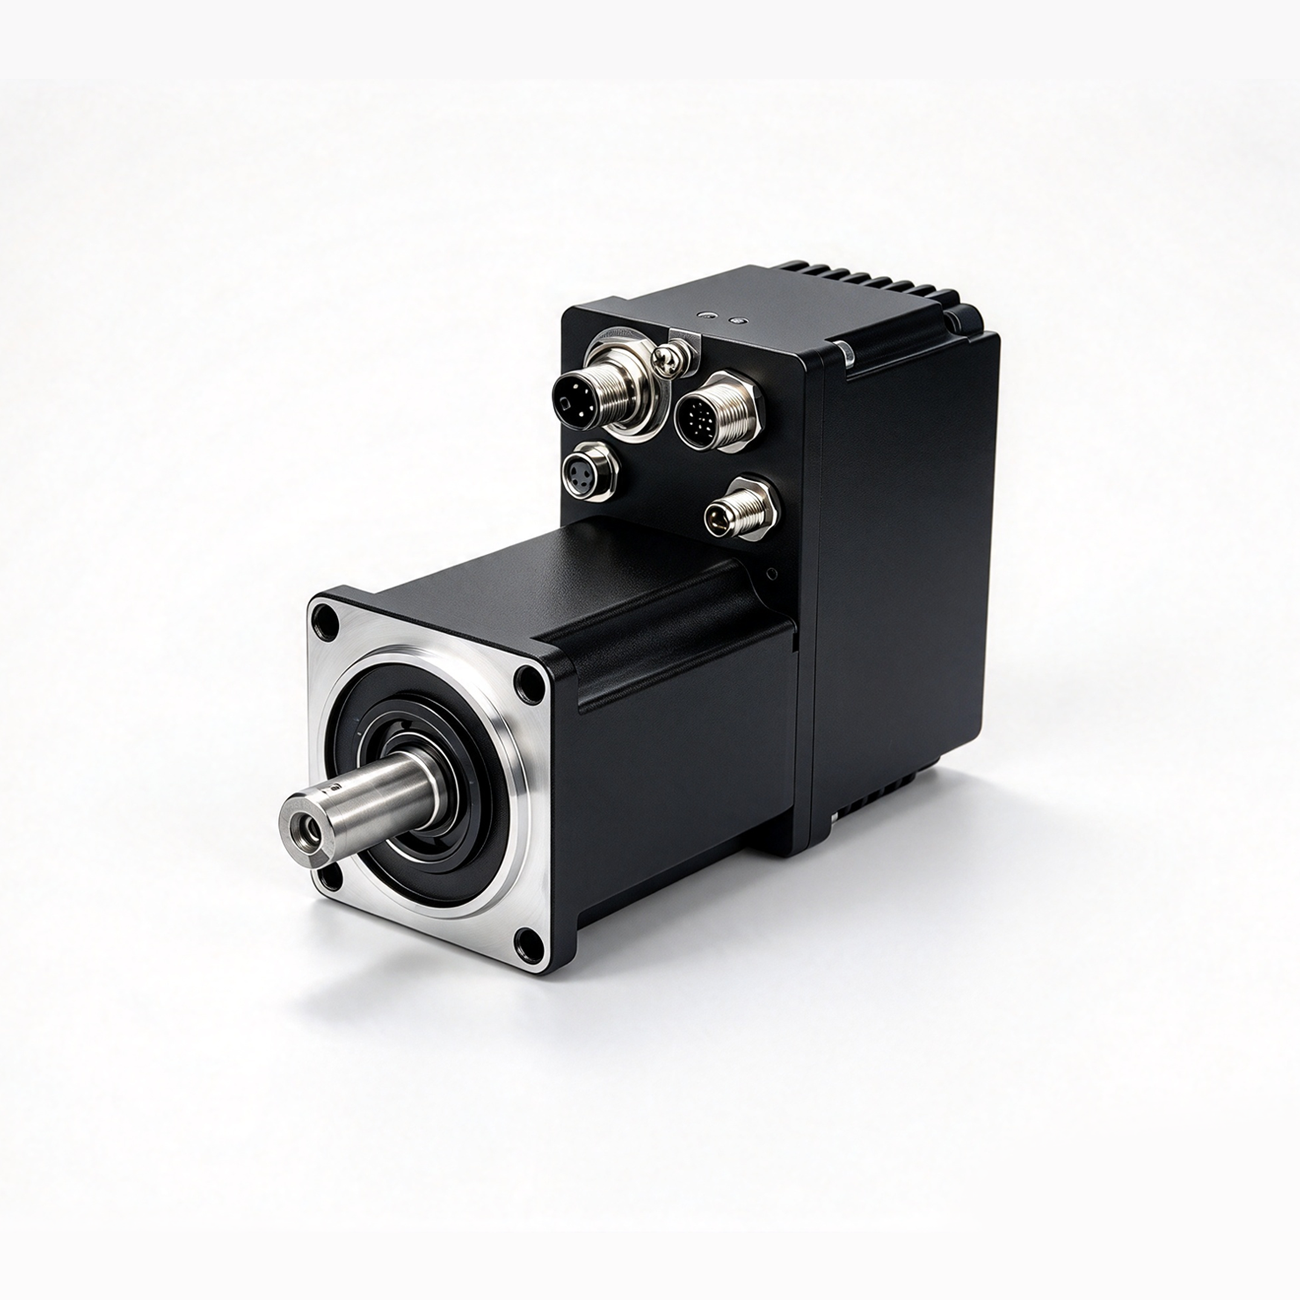
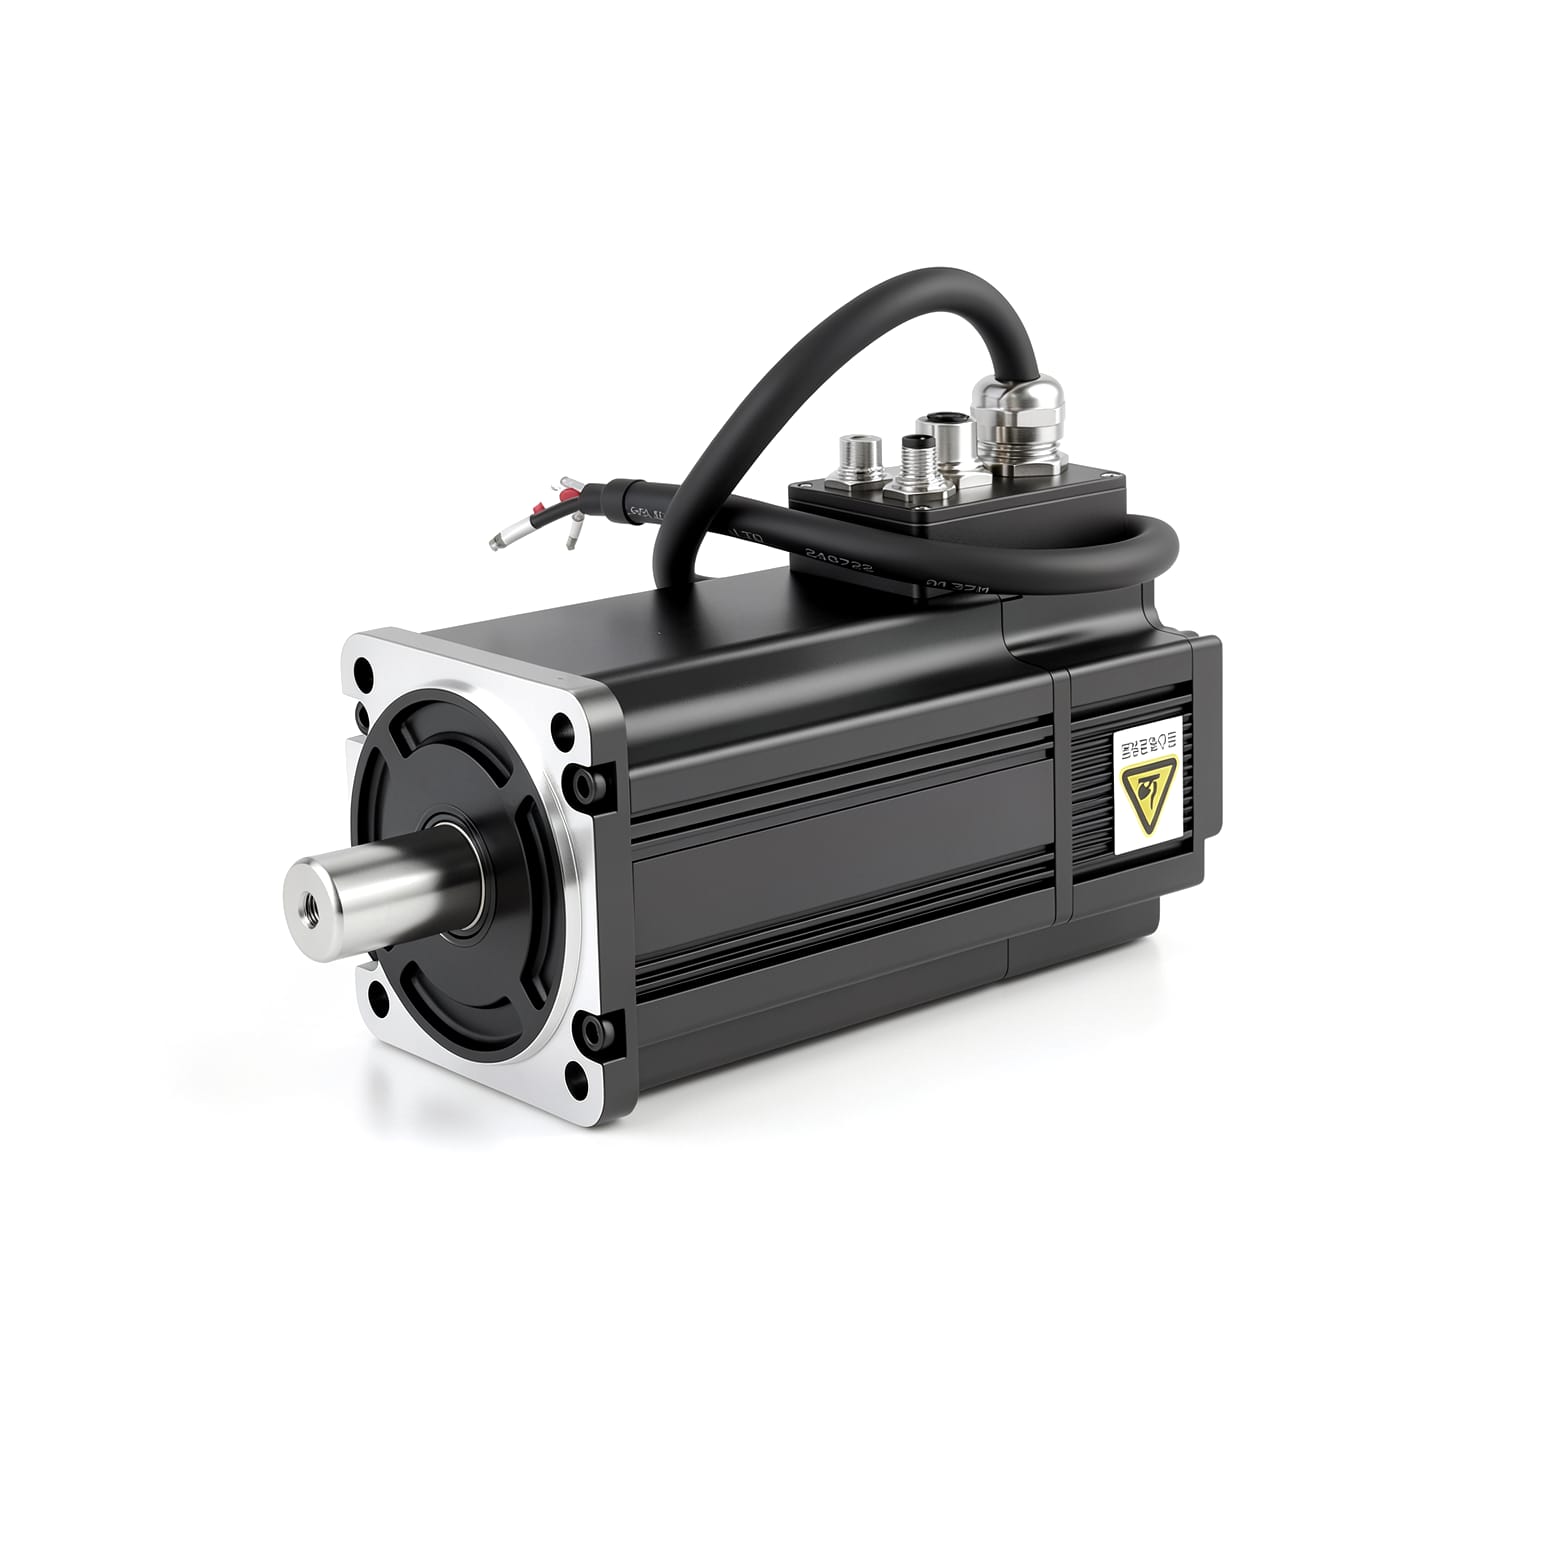
Models & Specifications
| Specifications | PAMP6040B-F | PAMP6040B-S-F | PAMP6040D-F | PAMP6040D-S-F |
|---|---|---|---|---|
| Flange Size | 60 | 60 | 60 | 60 |
| Encoder | 17-bit single-turn absolute magnetic encoder | 17-bit single-turn absolute magnetic encoder | 17-bit multi-turn absolute magnetic encoder | 17-bit multi-turn absolute magnetic encoder |
| Communication Method | CANopen,RS485,Pulse,EtherCAT | CANopen,RS485,Pulse,EtherCAT | CANopen,RS485,Pulse,EtherCAT | CANopen,RS485,Pulse,EtherCAT |
| Rated Speed | 3000 rpm | 3000 rpm | 3000 rpm | 3000 rpm |
| Rated Power | 400 W | 400 W | 400 W | 400 W |
| Rated Voltage | 220 VAC | 220 VAC | 220 VAC | 220 VAC |
| Rated Current | 2.5 A | 2.5 A | 2.5 A | 2.5 A |
| Torque | 1.27 N·m | 1.27 N·m | 1.27 N·m | 1.27 N·m |
| Inertia | 0.52×10^-4 kg·m² | 0.52×10^-4 kg·m² | 0.52×10^-4 kg·m² | 0.52×10^-4 kg·m² |
| Brake | No | No | No | No |
| Protection Level | IP65 | IP65 | IP65 | IP65 |
| STO Function | No | Yes | No | Yes |
| Body Length | 135 mm | 135 mm | 135 mm | 135 mm |
| Weight | 1.55 kg | 1.55 kg | 1.55 kg | 1.55 kg |
* Scroll horizontally within the table area when the content is wide.
Specifications
| Shaft Diameter | Φ14 |
| Voltage Range | 220±10% VAC |
| Drive Mode | Adopting FOC field-oriented control technology and SVPWM |
| Encoder | 17-bit single-turn absolute magnetic encoder or17-bit multi-turn absolute magnetic encoder |
| NiMotion Mode | Position mode: Pulse control, multi-segment position control, digital input control, analog input control Speed mode: Pulse control, multi-segment speed control, digital input control, analog input control Torque mode: Digital input control, analog input control |
| CiA402 Mode | PP, VM, PV, PT, HM, IP, CSP, CSV, CST |
| DI (Digital Input) | Quantity: 3, high-speed unidirectional optocoupler, supported maximum PWM pulse frequency: 2MHz; Supports PNP, NPN and differential input; At high levels, it is 5 to 24V; at low levels, it is 0 to 0.5V. Configurable functions: 1. Use as a switch 2. Use as a pulse input channel |
| DO (Digital Output) | Quantity: 1; Supports optocoupler output with open collector; Maximum current: 100mA; Maximum voltage: 55V(≥1KHz,Configurable functions: 1. Regular DO port; 2. The motor stops running; 3. Goal achievement; 4. Alarm output |
| AI (Analog Input) | Quantity: 1; Input Type: Single-ended; Signal Type: Voltage; Resolution: 12-bit; Voltage: -10V~10V; Accuracy: Reference error ≤1%; Configurable Functions: Dead zone, Filtering, Offset, Scaling, Direction |
| Operating Temperature | 0 to 40°C, 0°C to +40°C do not require reduction in rating. When the temperature exceeds 40°C, the rating should be reduced. For every 1°C increase, the rating is reduced by 2%. |
| Operating Altitude | <1000m |
| Fault Alarm | Overvoltage, undervoltage, overtemperature, locked rotor, overload, overspeed |
| Servo Function | Soft limit, gain switching, S-curve planning, vibration suppression, parameter identification, online upgrade |
Torque-Speed Characteristics
PAMP6040X- COE/CANopen/485-X
Product Details
Downloads
Companion Products
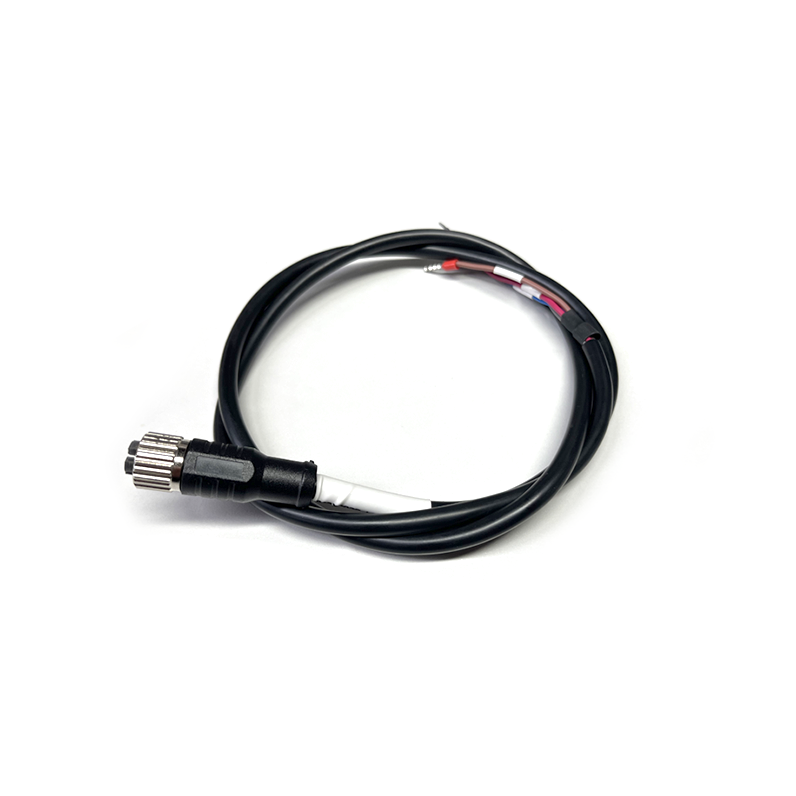
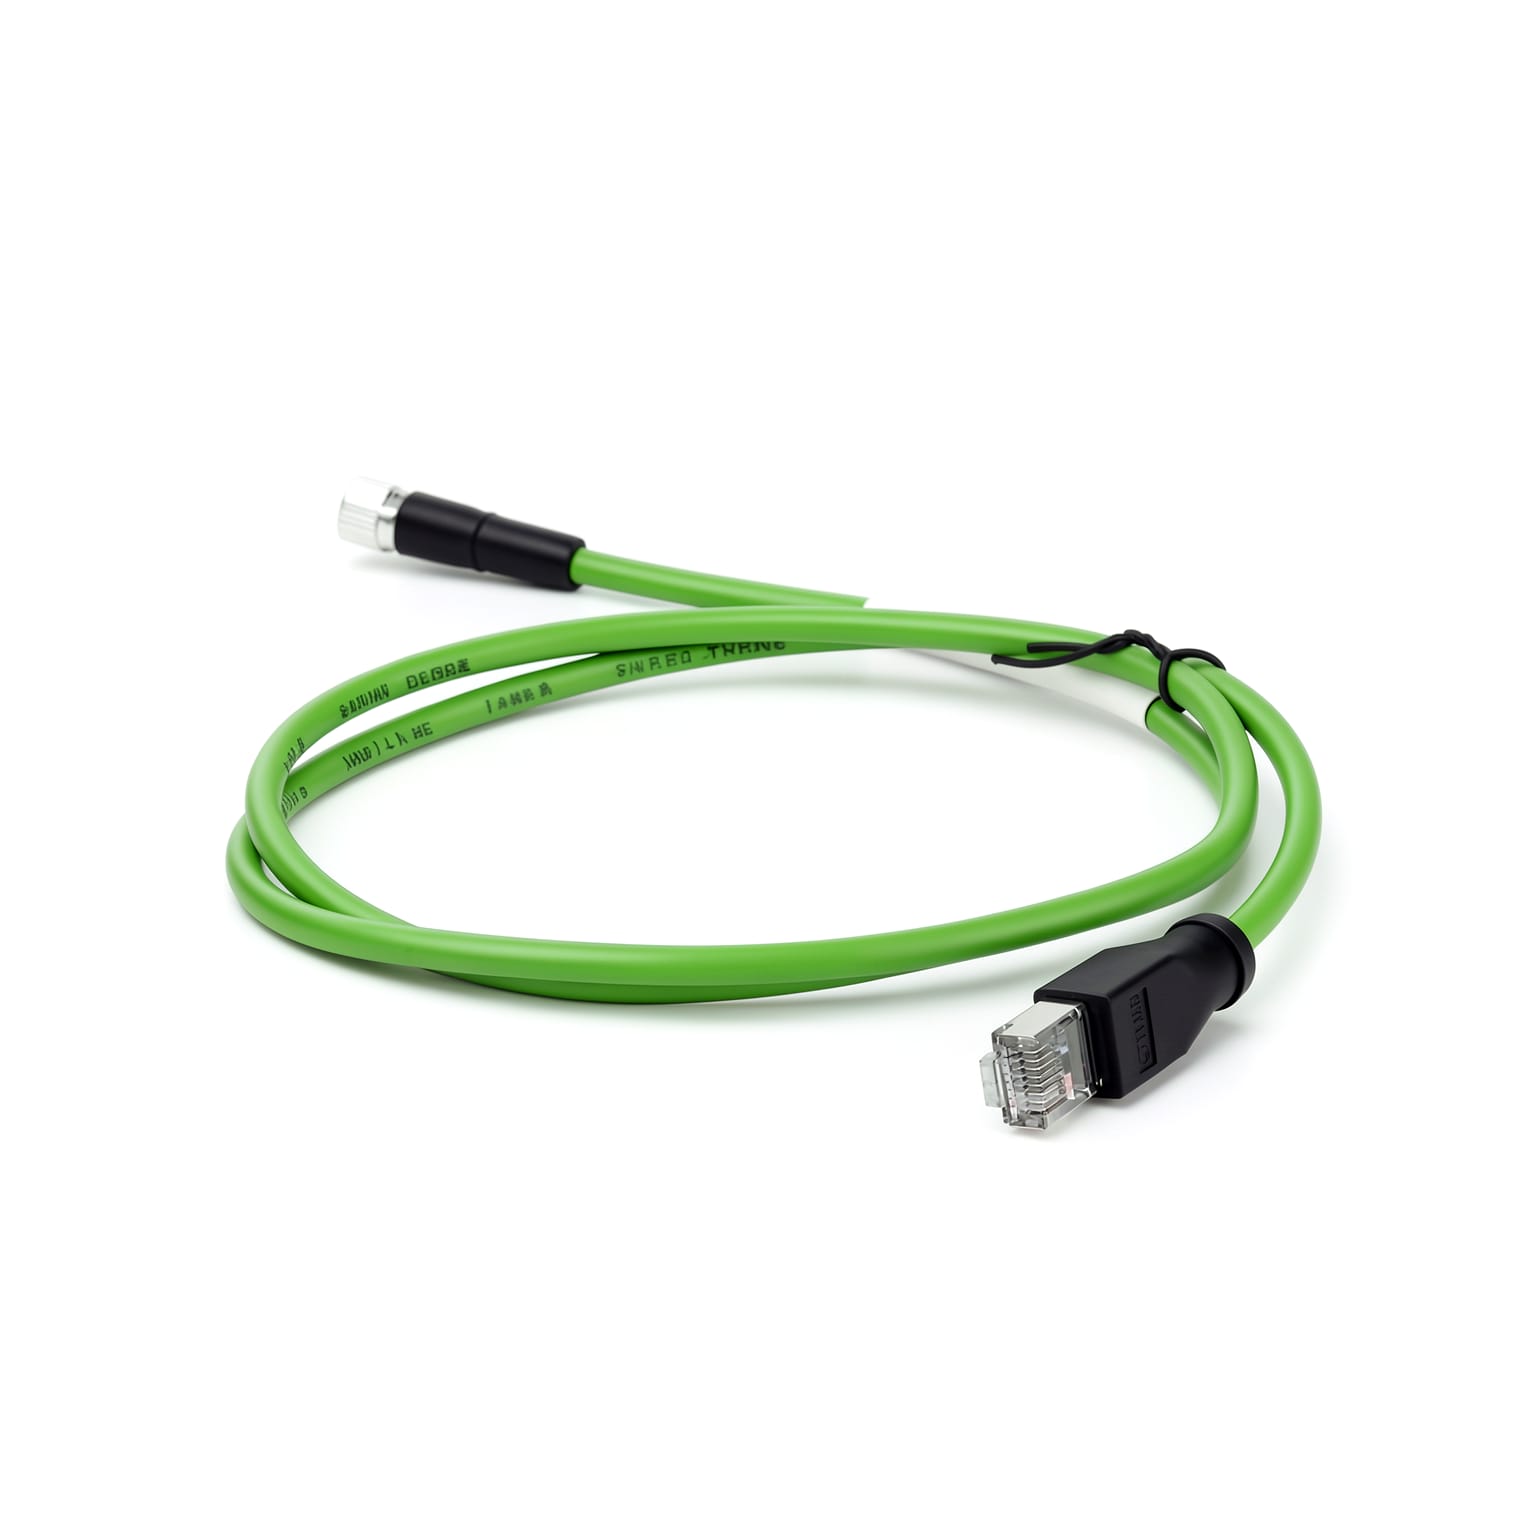
Communication cable for NiMotion integrated motors.
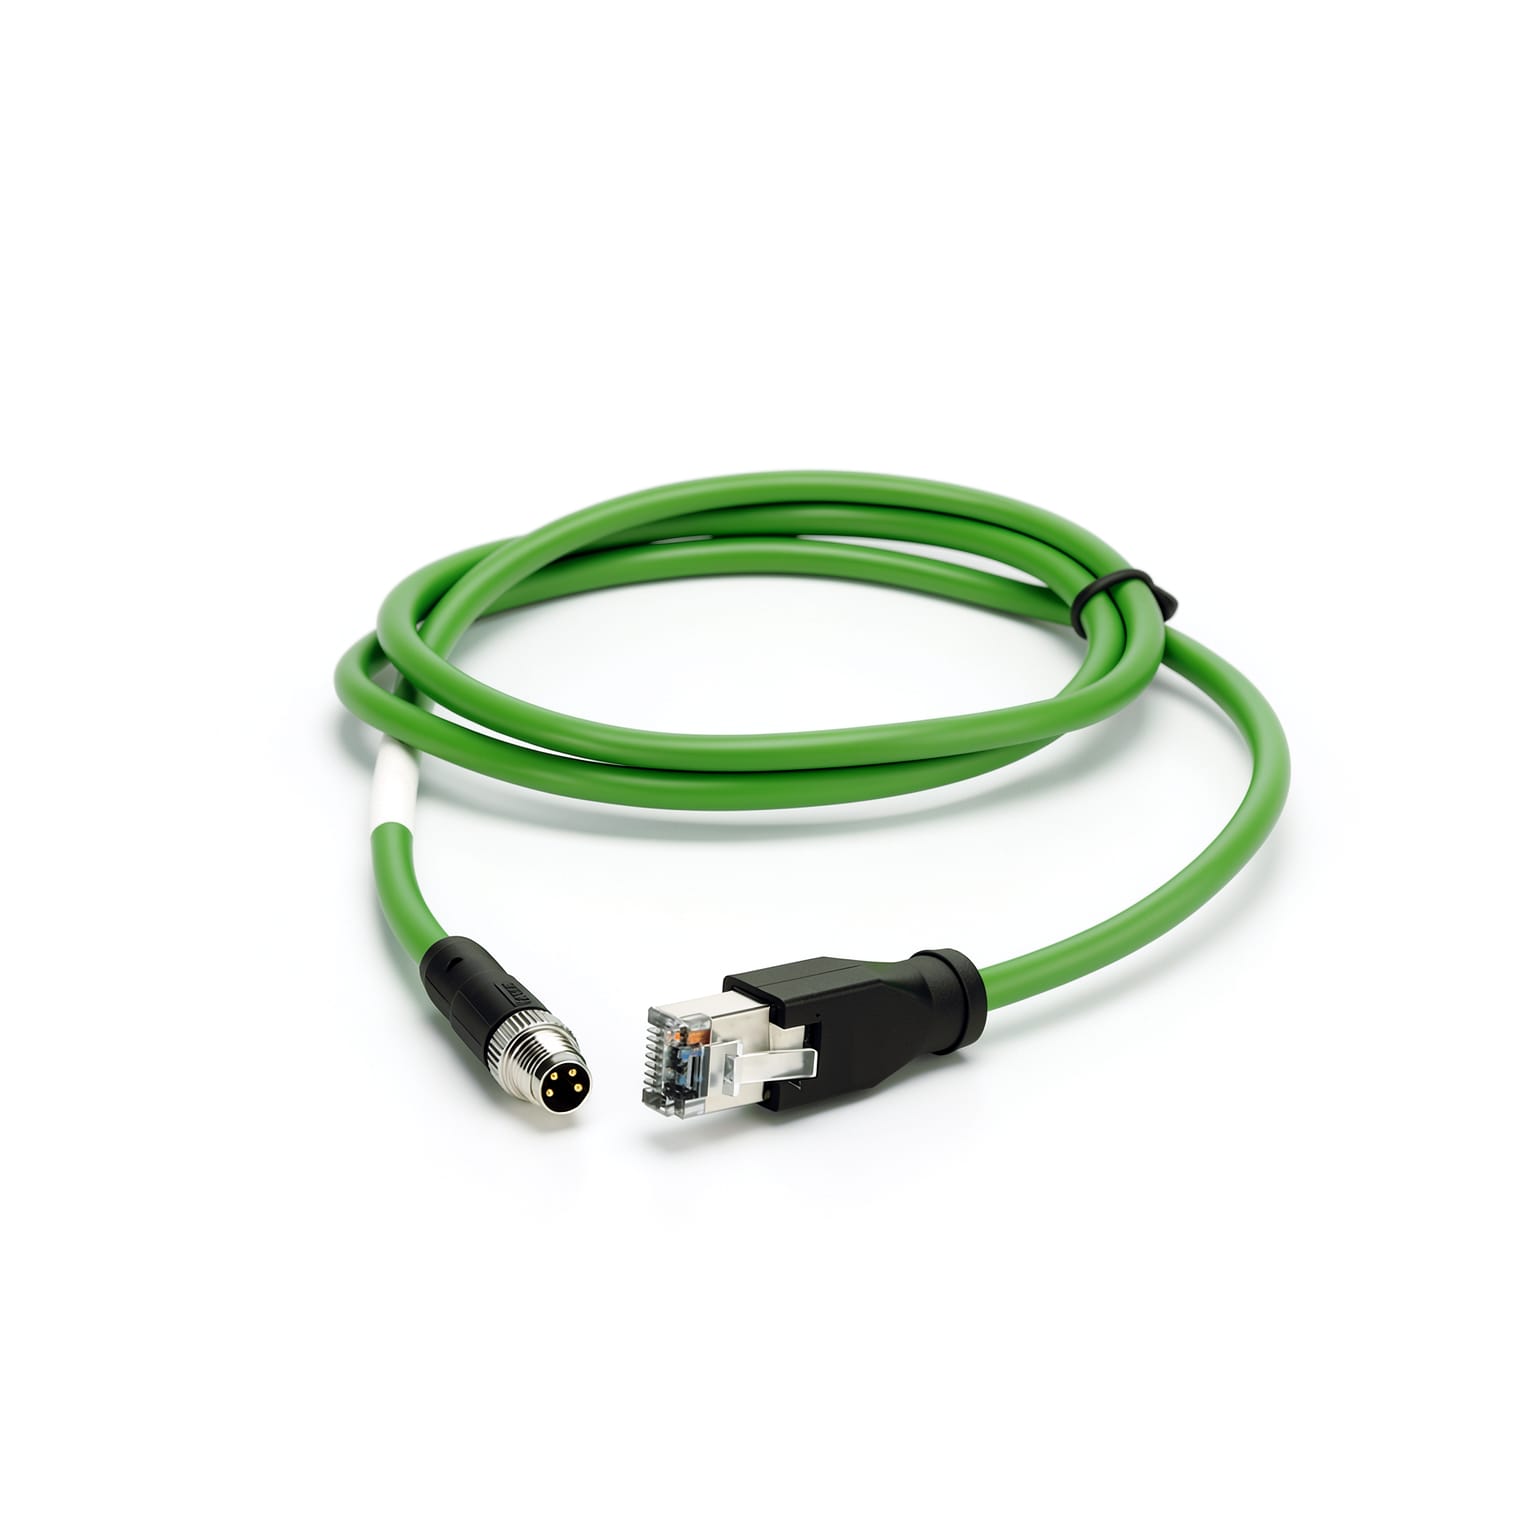
Communication cable for NiMotion integrated motors.
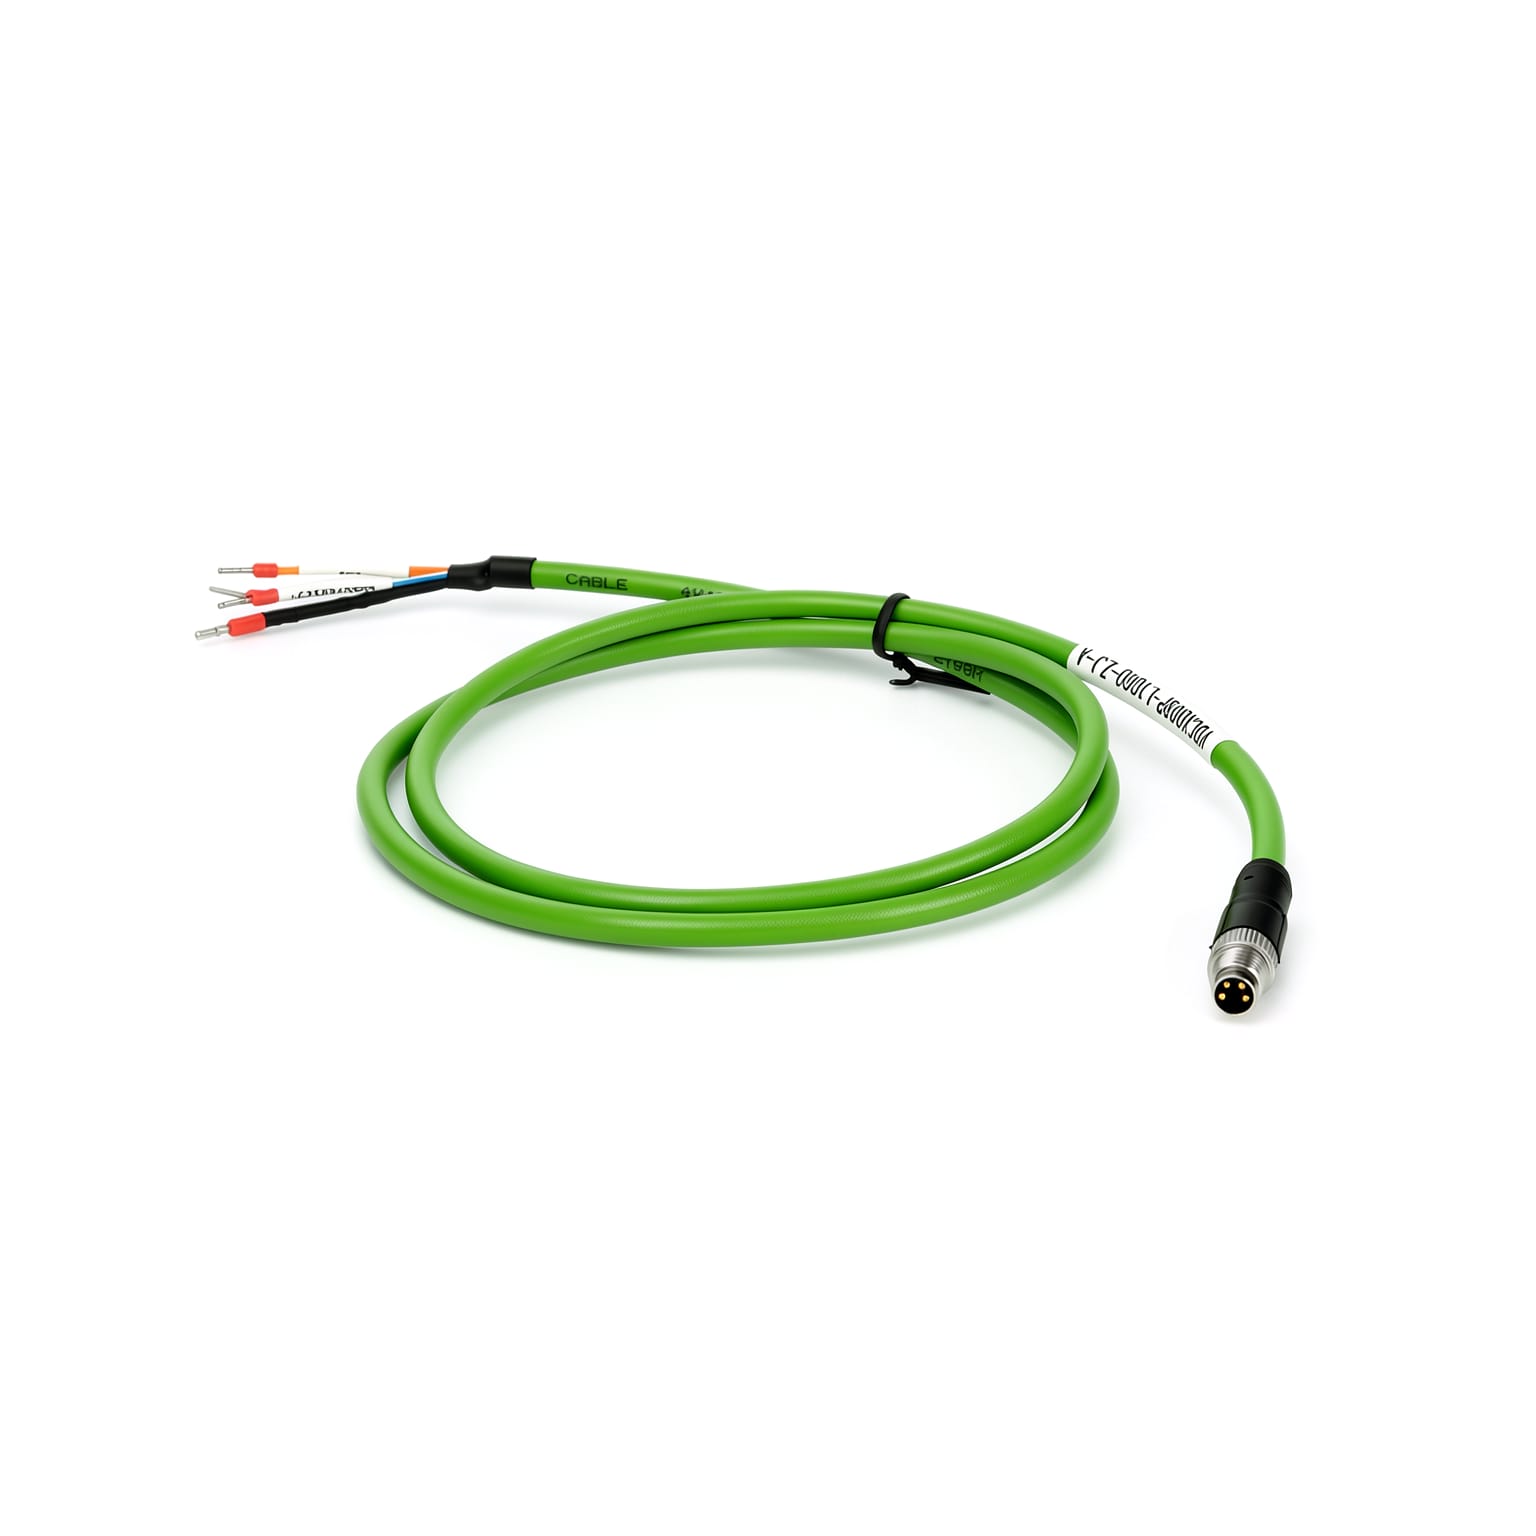
Communication cable for NiMotion integrated motors.

Communication cable for NiMotion integrated motors.
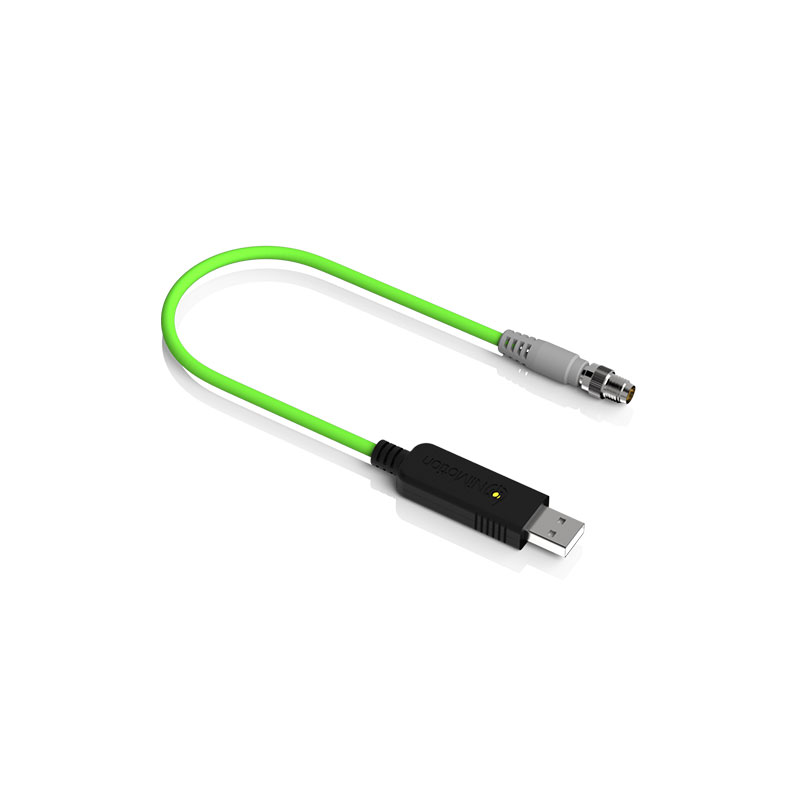
USB to CAN converter with isolation, IP65 protection, and secondary development SDK support.
USB to RS485 converter with active termination, isolation, IP65 protection, and secondary development SDK support.

FAQ
The positional accuracy of a stepper motor is about 3‑5% of the step angle, and it does not accumulate errors.
Microstepping is essentially an electronic damping technique, primarily designed to reduce or eliminate low‑frequency vibration. Improved positional resolution is a secondary benefit. Different manufacturers’ microstepping drivers can vary greatly in accuracy, and higher microstepping numbers are harder to control precisely.
This is due to the motor’s pull‑in rate – the maximum pulse frequency at which it can start from standstill without losing steps. If the pulse frequency exceeds this rate, the motor cannot start properly and may lose steps or stall. The solution is to use an acceleration ramp: start at a low frequency and gradually increase to the target high frequency. Integrated stepper motors allow you to set acceleration and deceleration parameters freely.
When the motor rotates, the inductance in each phase winding generates a back‑EMF. The higher the frequency, the greater the back‑EMF, which reduces the phase current and thus lowers the torque.
Excessive temperature can demagnetise the magnetic material, reducing torque and causing step loss. The demagnetisation point is generally above 130°C, some up to 200°C. Therefore, a surface temperature of 80‑90°C is perfectly normal for a stepper motor. The most common insulation class is Class B, with a rated operating temperature up to 130°C.
Applications
Discover how this product is applied across various industrial automation scenarios.
Compatible Products
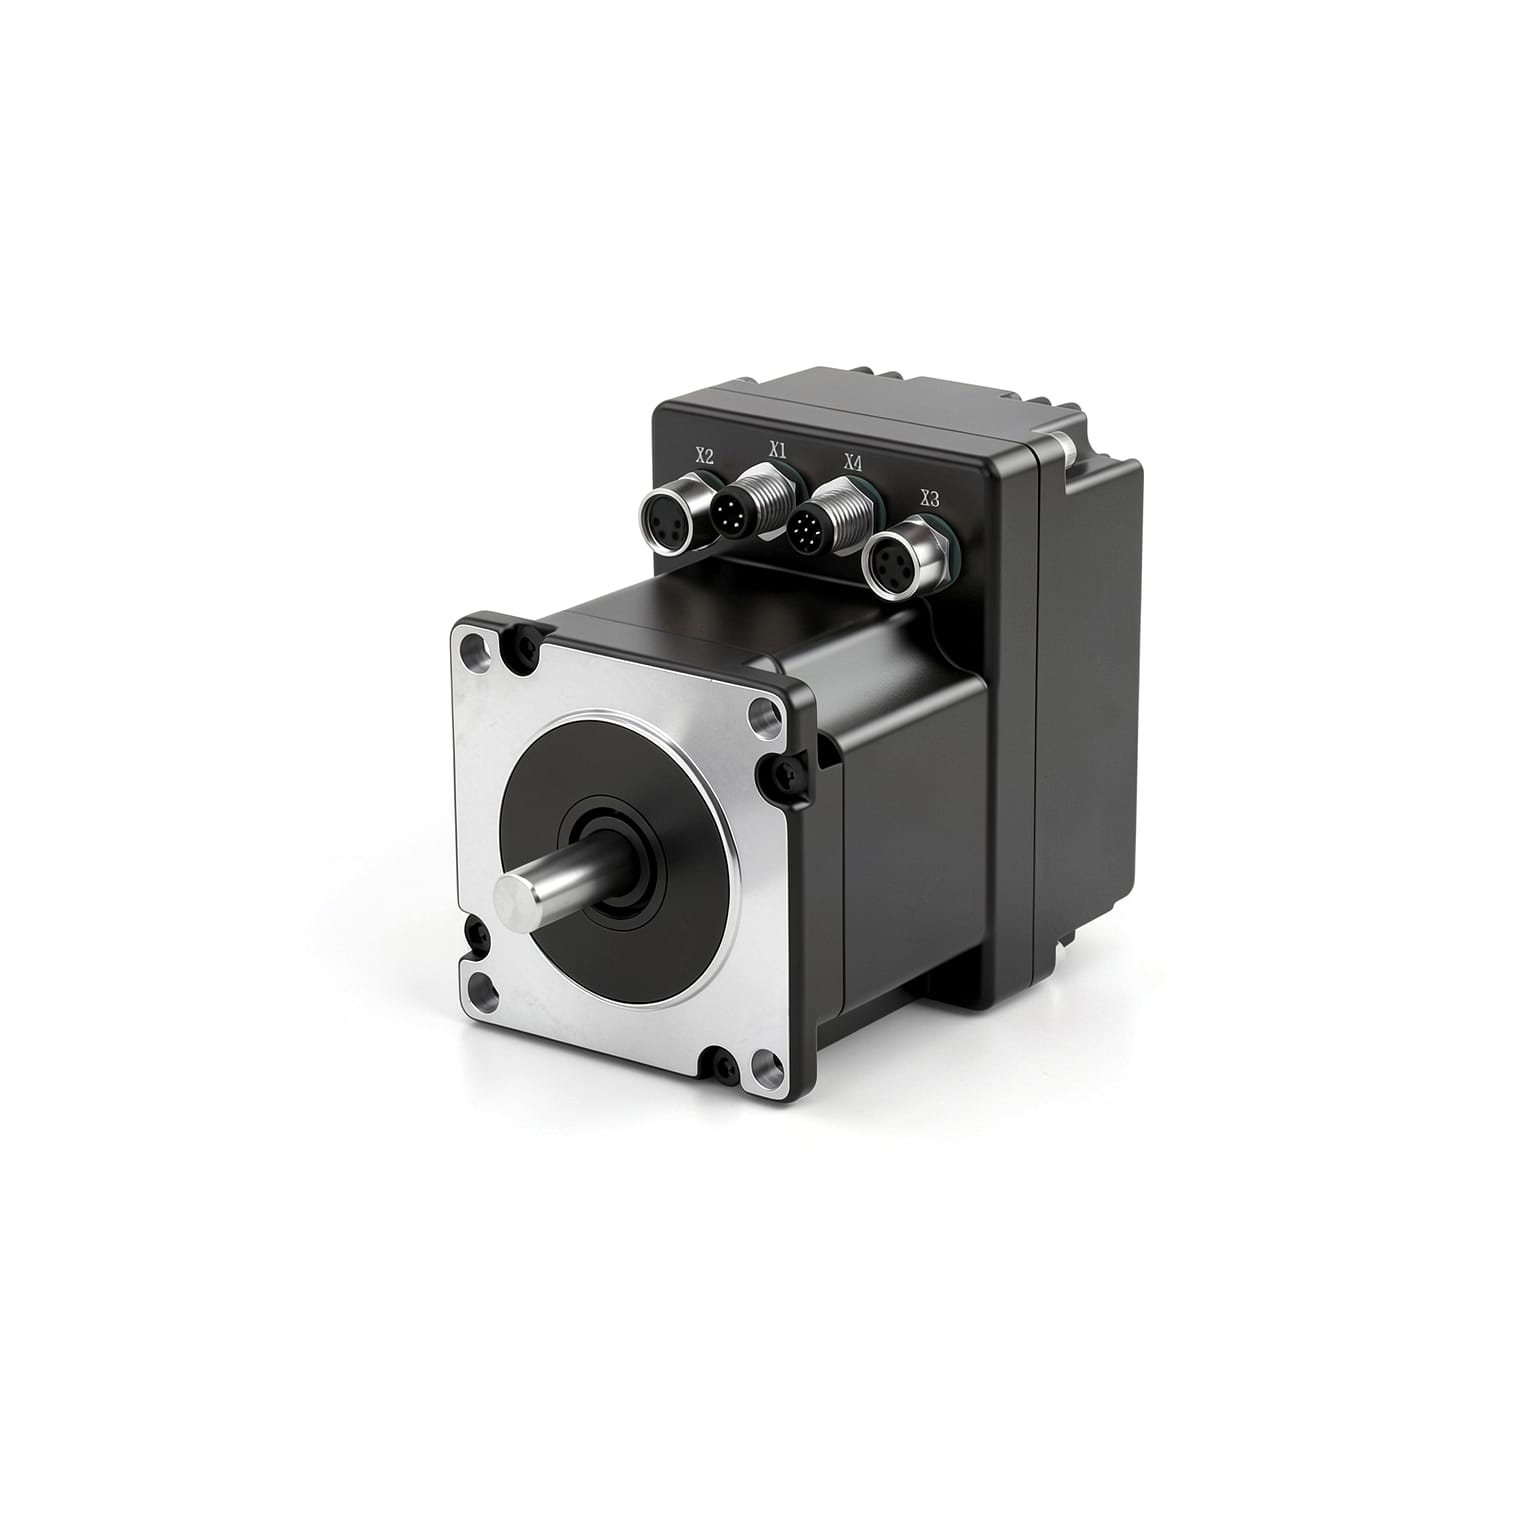
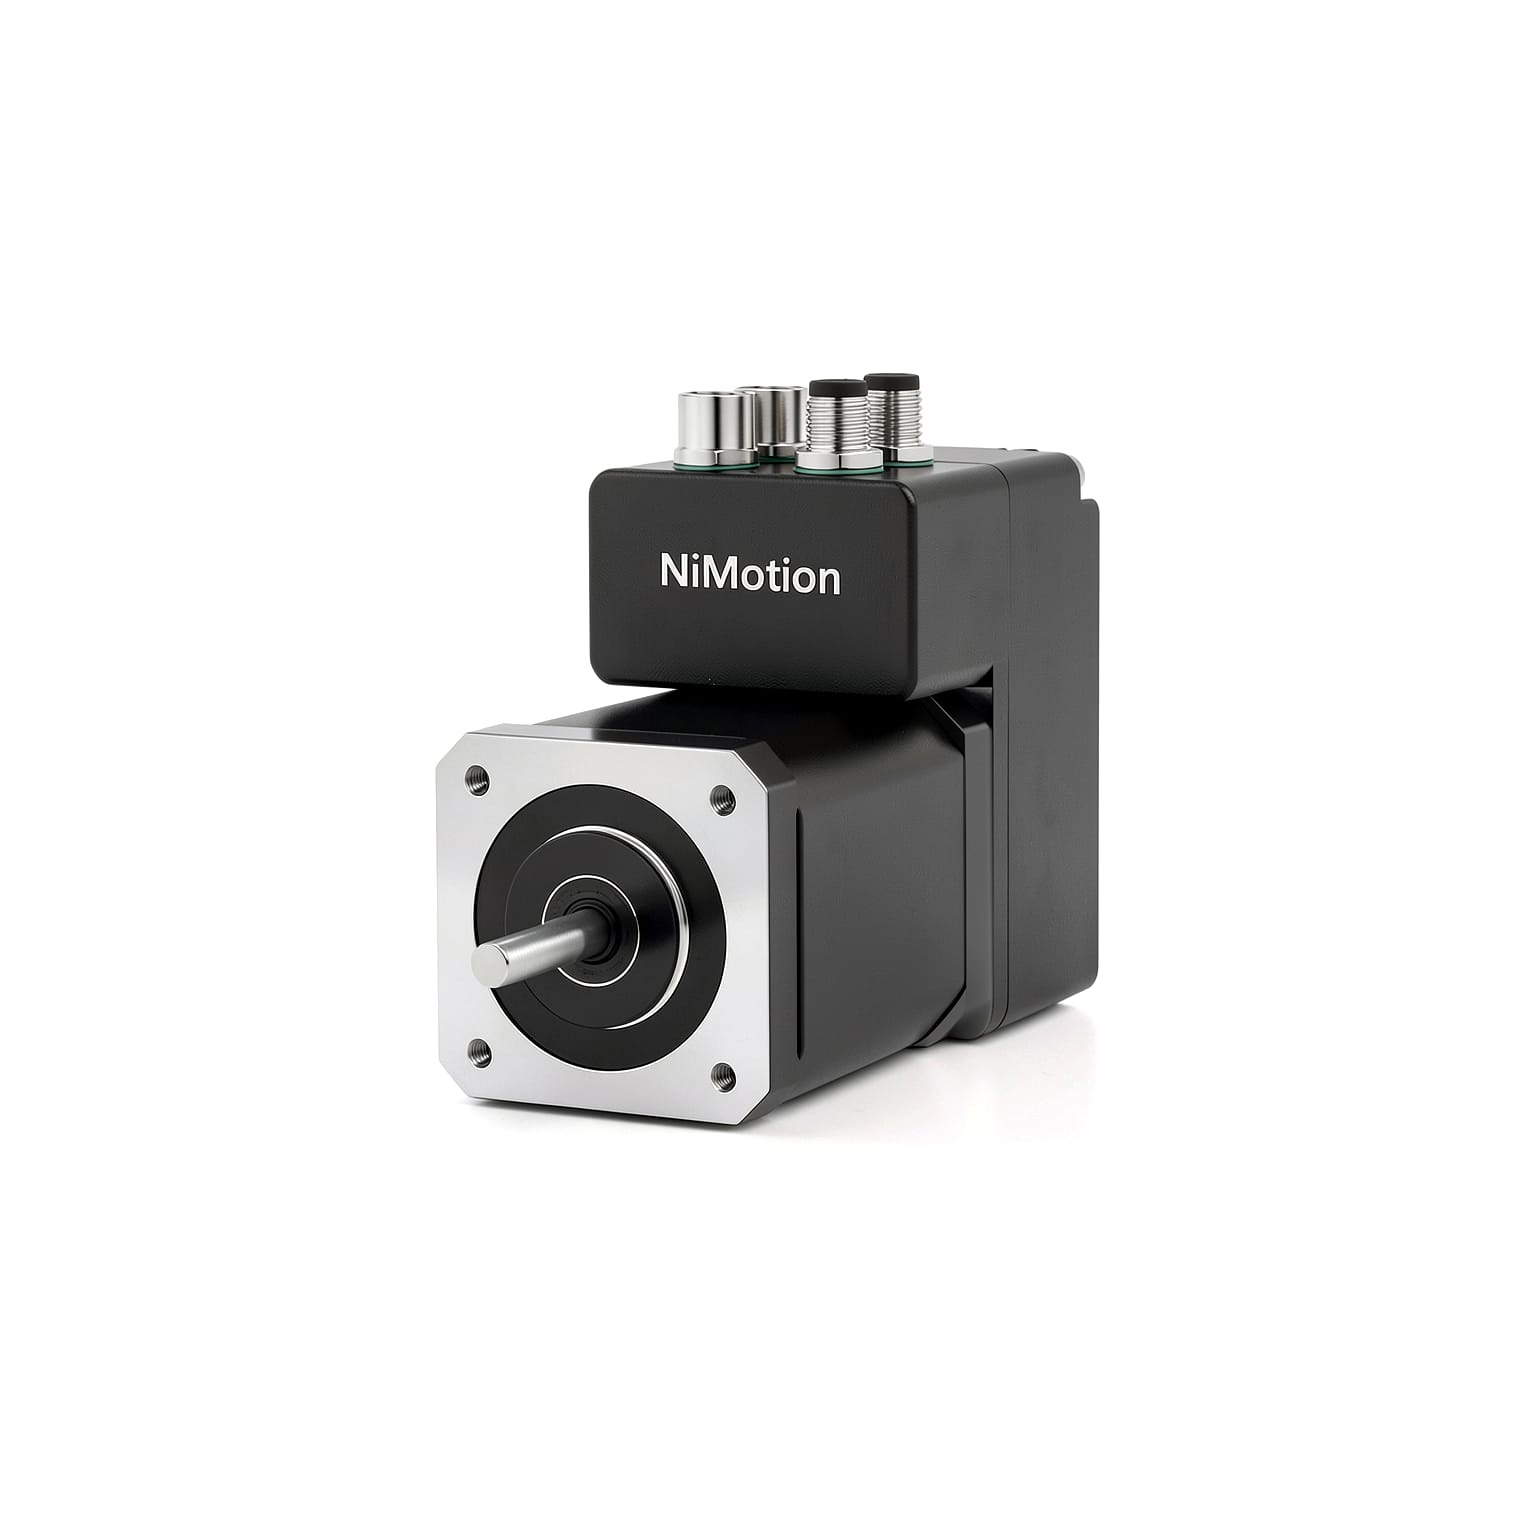
Build complete and reliable solutions with our compatible products.

Technical Resources
Technical guides, application notes, and more to help you get the most out of the product.
Ready to start your automation project?
Talk to our engineers and get a customized motion control solution within 24 hours.
Typical response time: 24 hours