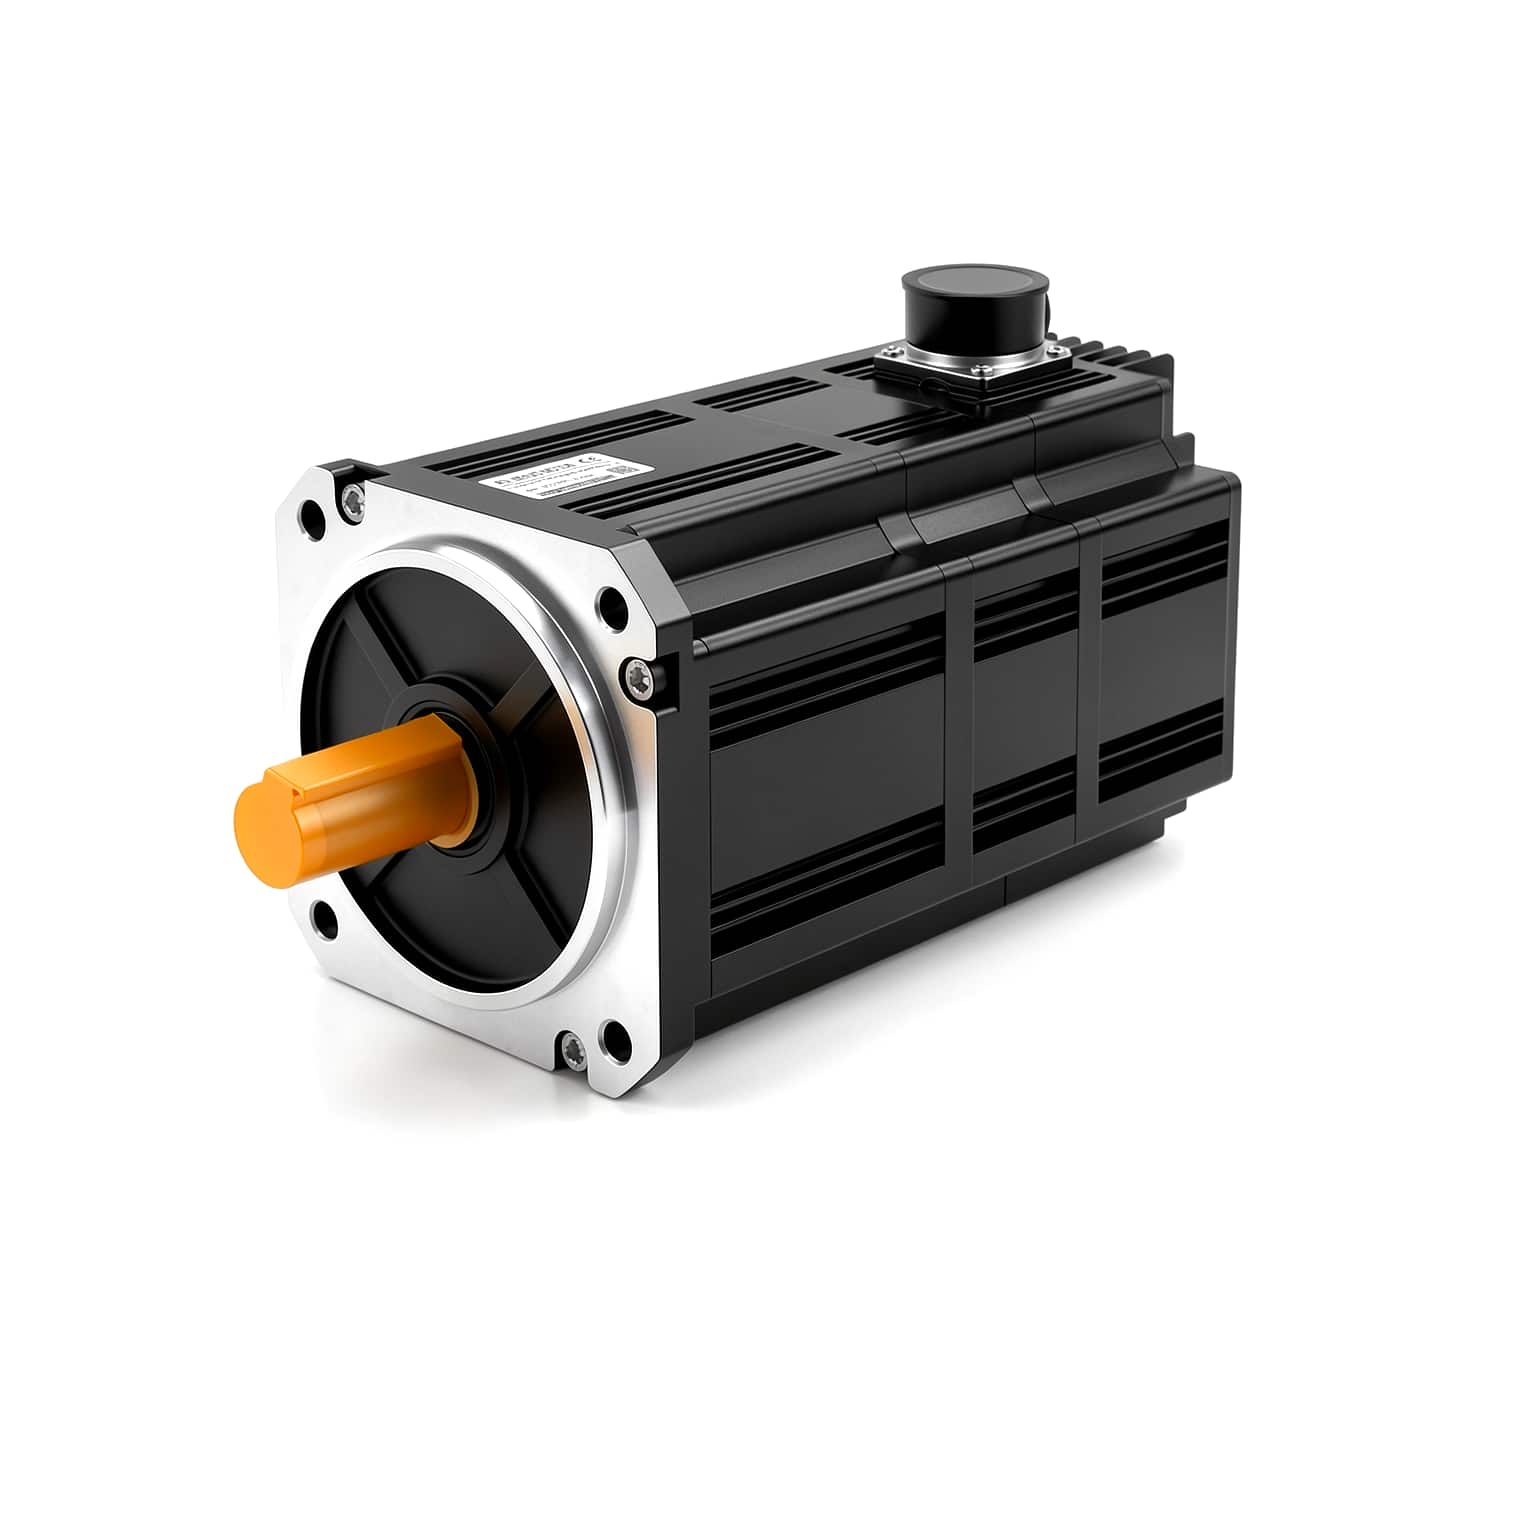
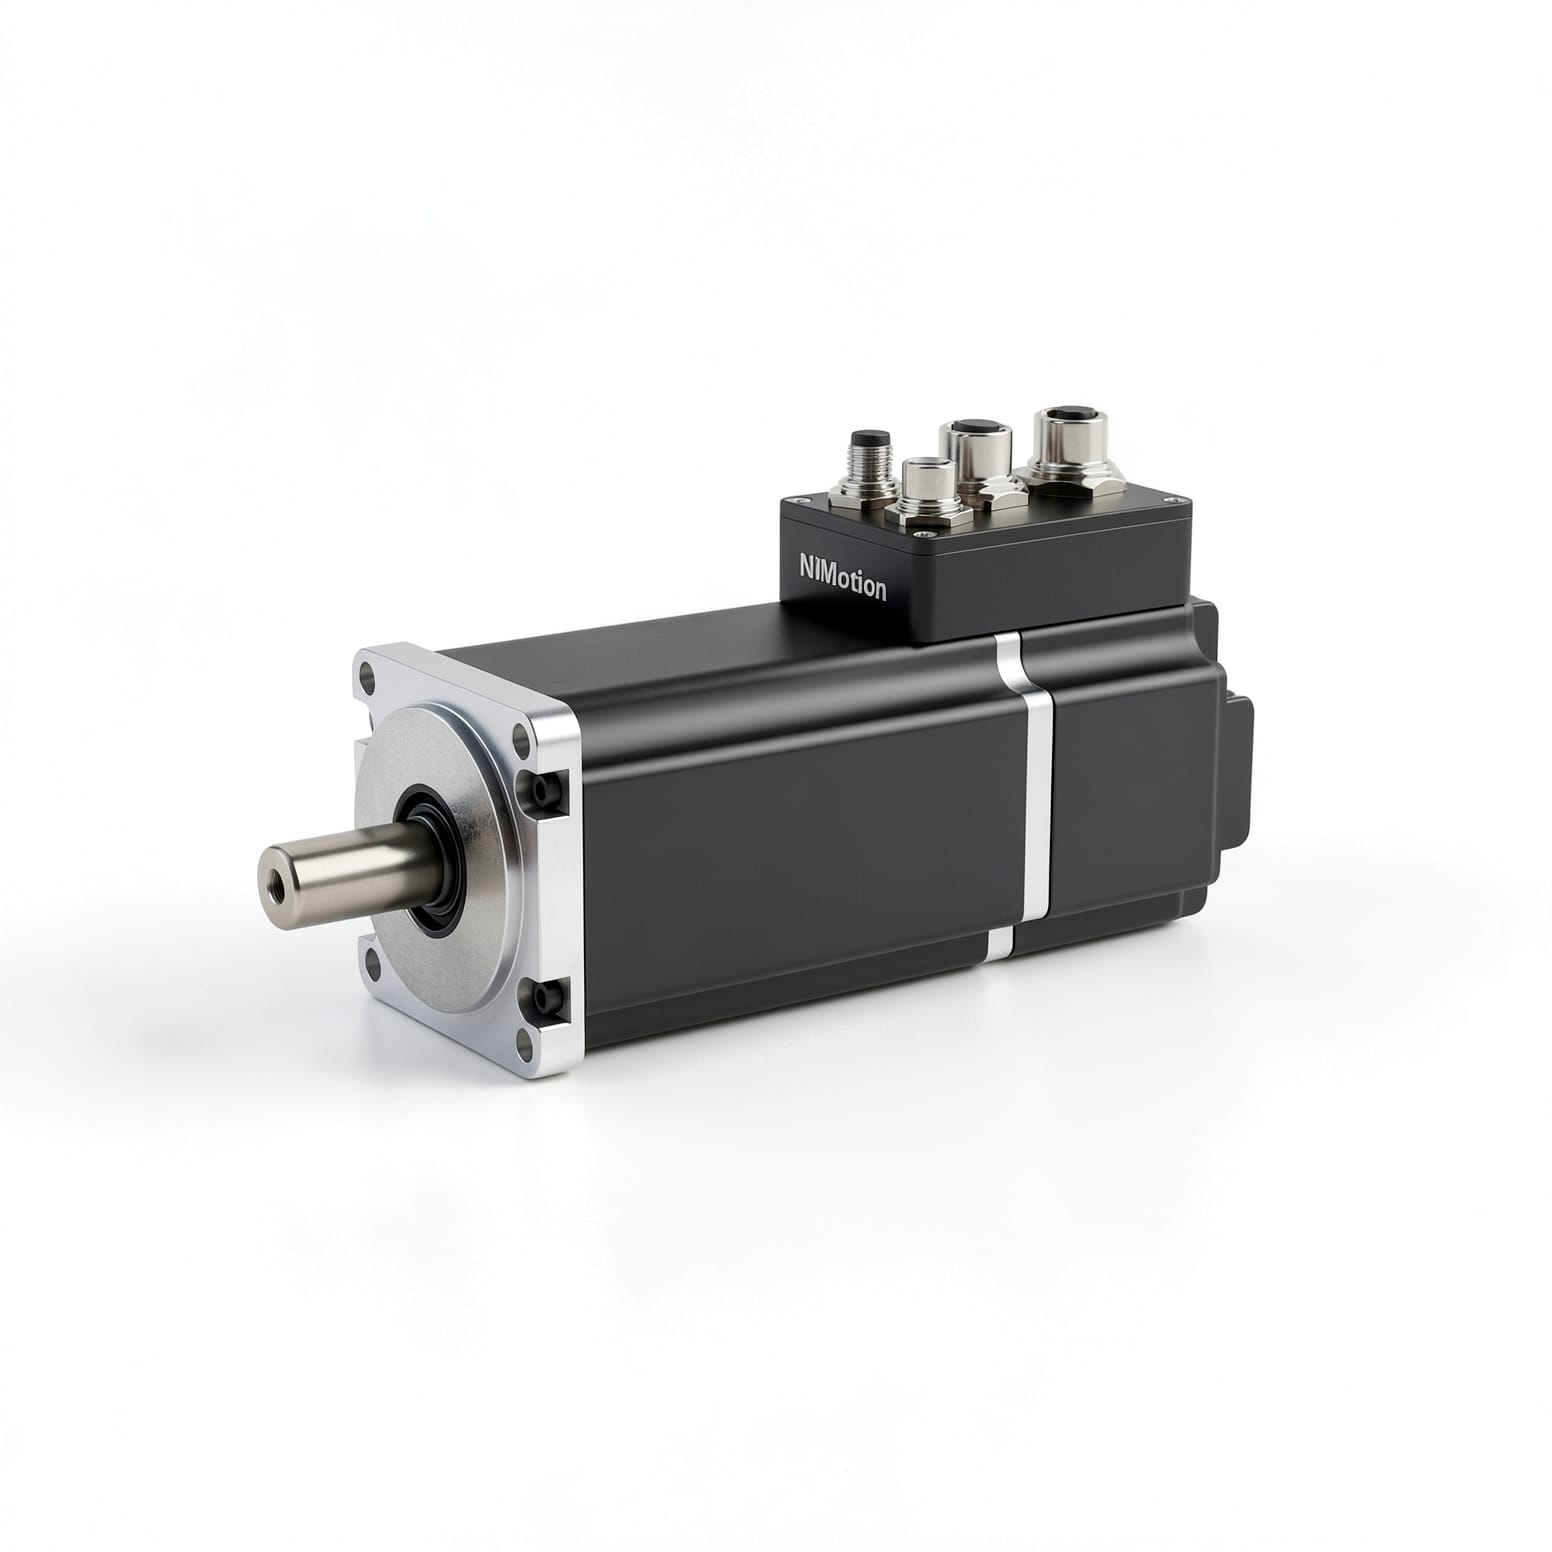
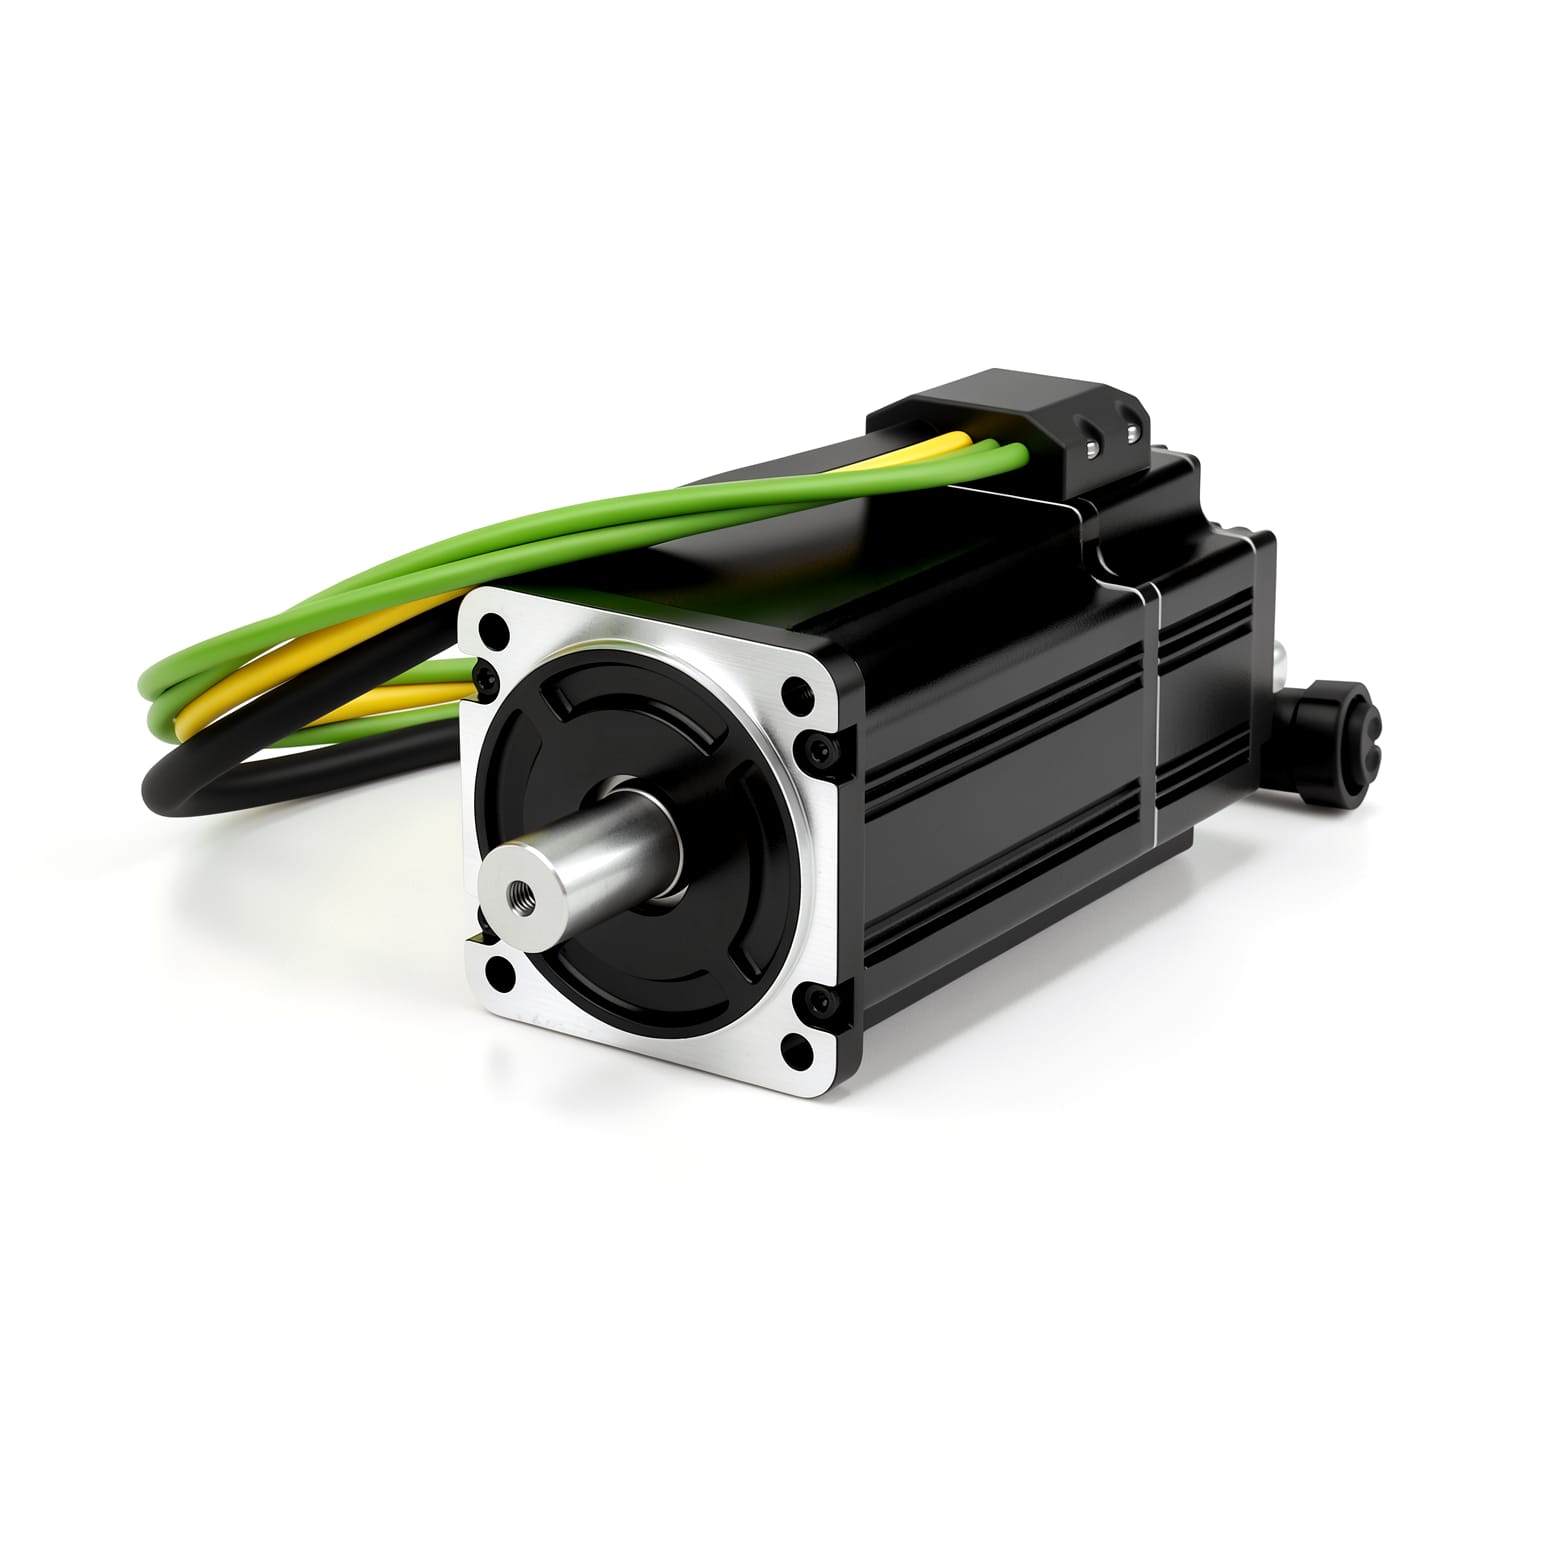
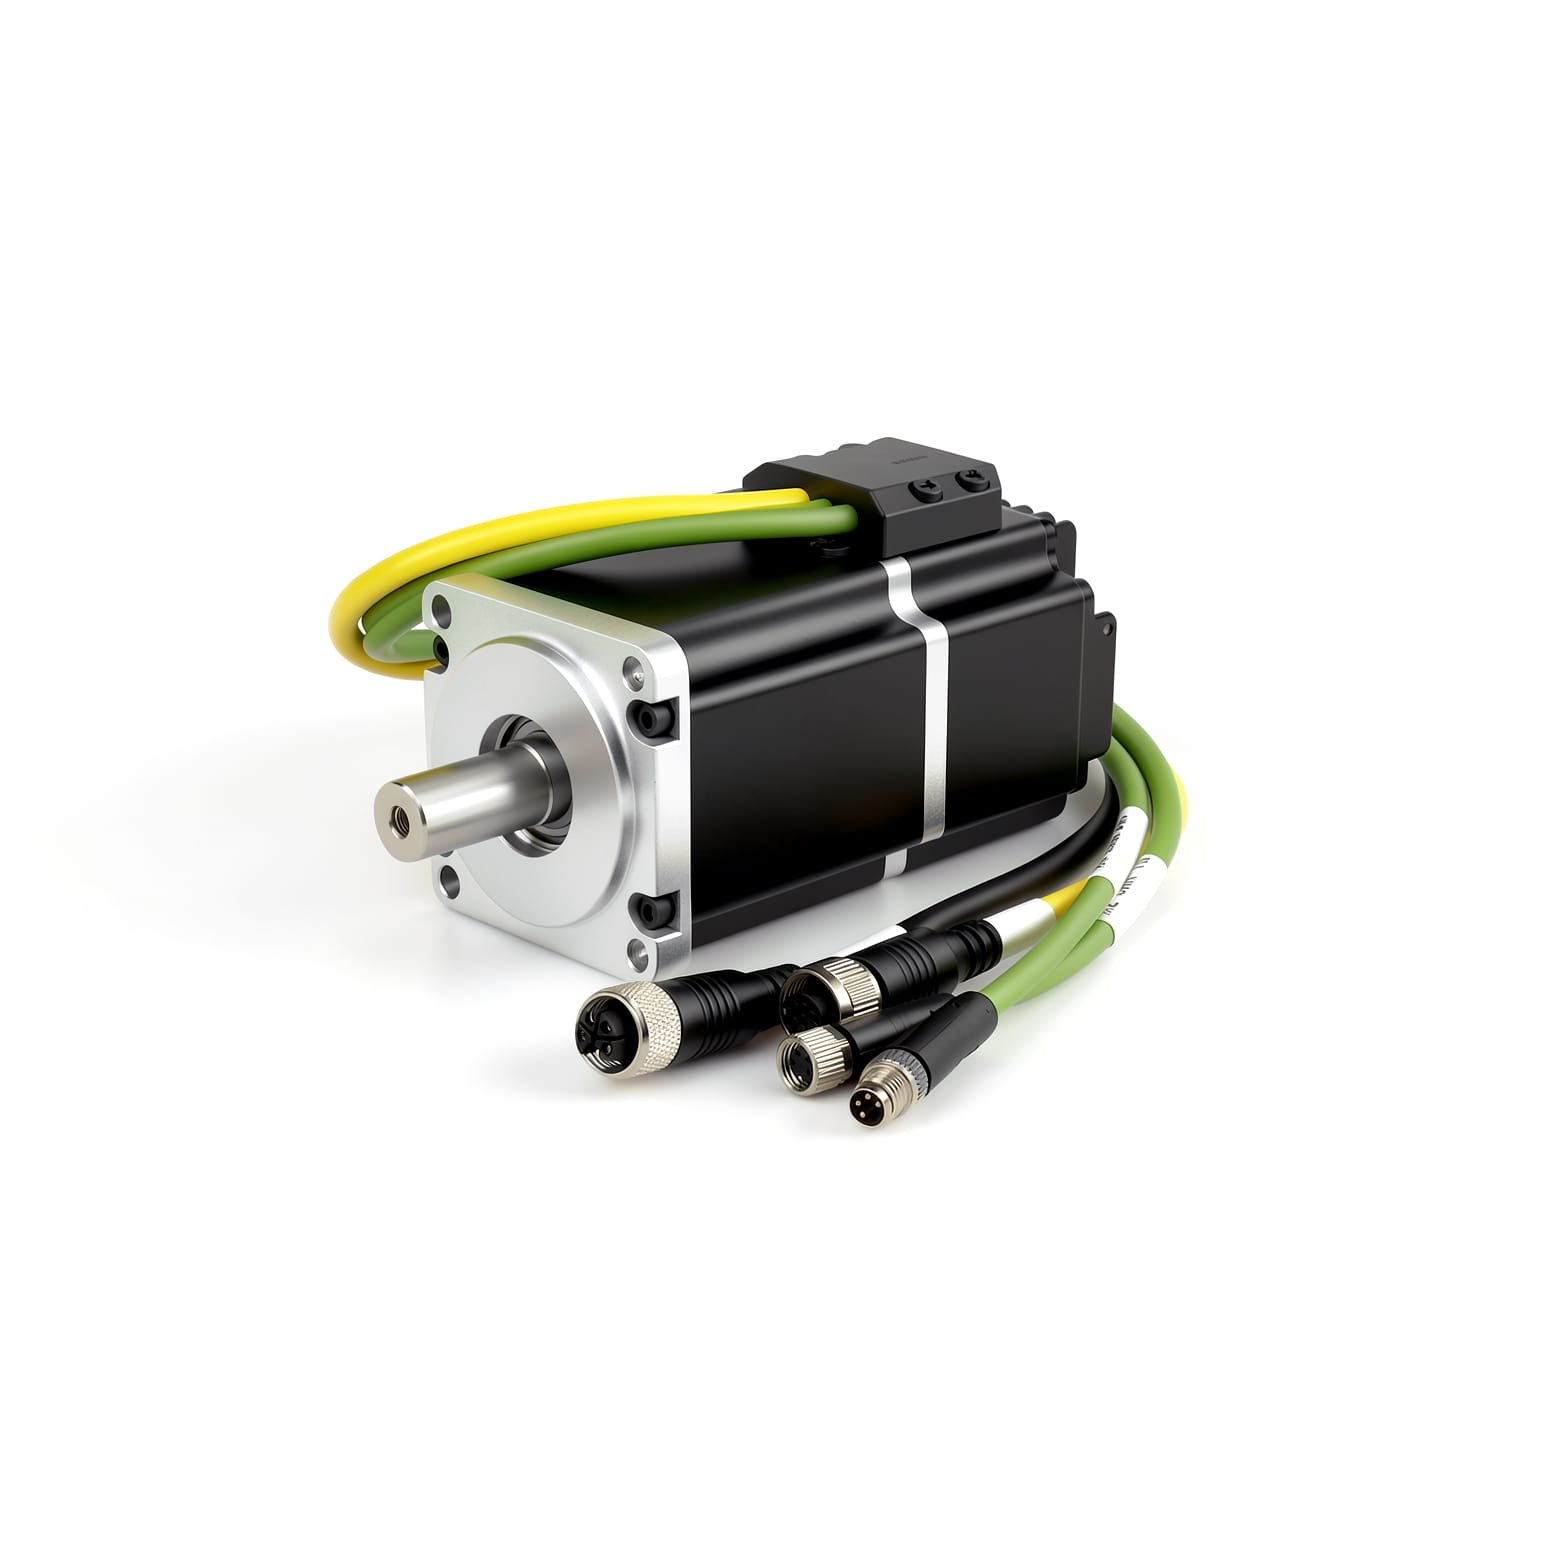
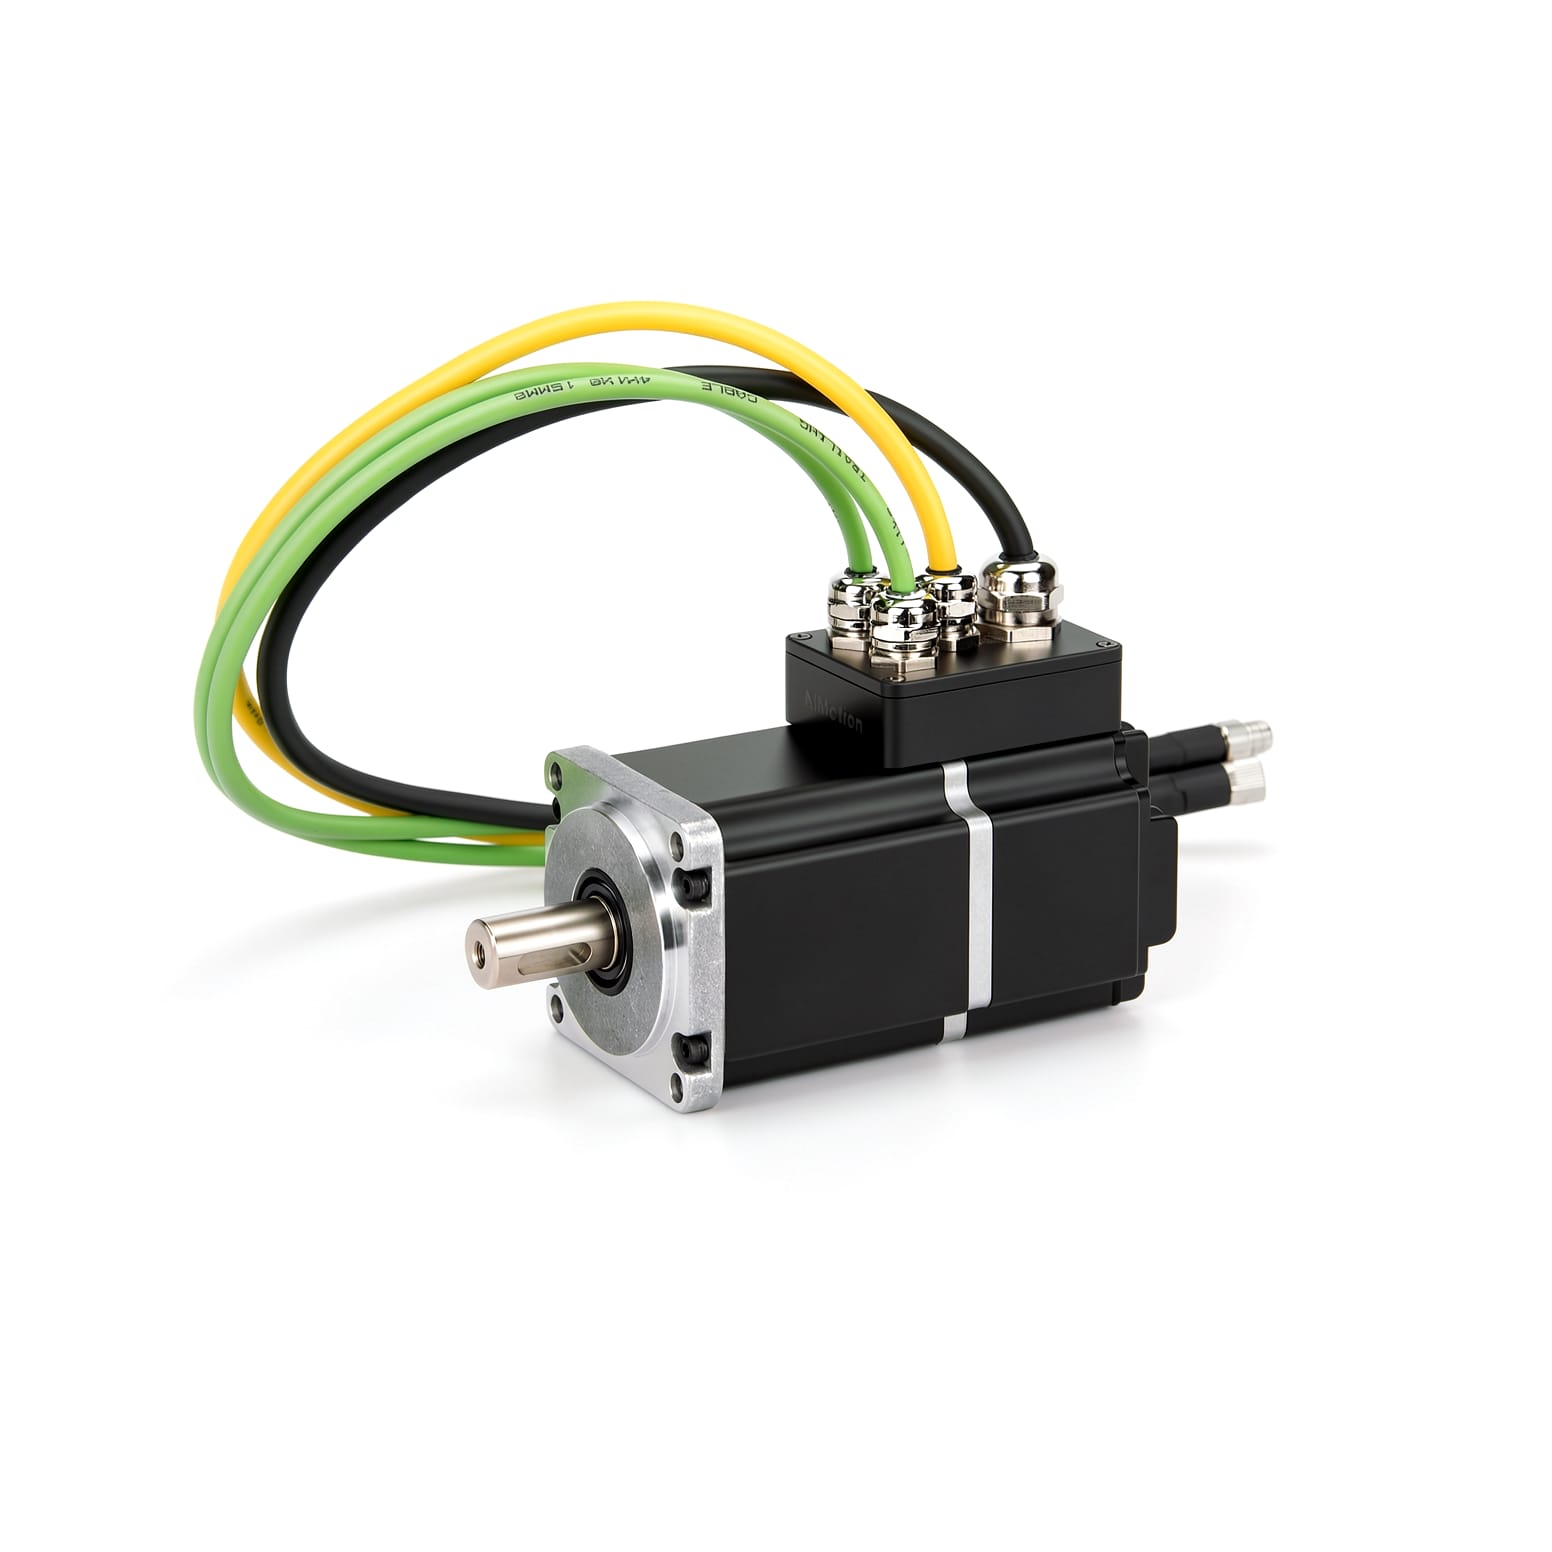
PSMP130 (IP65 Protection with STO and Brake) Integrated DC Servo Motor
Built-in Brake w/ Logic, The PSMP130 Series integrated servo motor delivers high torque output and high-speed performance with smooth and stable operation. Its IP65 protection rating withstands dust, oil, and contaminants, while the STO (Safe Torque Off) function ensures equipment safety. A built-in cooling fan in the rear cover provides active noise reduction and effectively suppresses temperature rise, ensuring stable and reliable performance during prolonged high-load operation.
Features
- IP65 protection rating
- High power 1500W
- Optional brake and STO function available
Models & Specifications
| Specifications | PSMP1301K5B-485-S-0HSB | PSMP1301K5B-COE-S-0HSB | PSMP1301K5B-CANopen-S-0HSB | PSMP1301K5D-485-S-0HSB | PSMP1301K5D-COE-S-0HSB | PSMP1301K5D-CANopen-S-0HSB |
|---|---|---|---|---|---|---|
| Flange Size | 130mm | 130mm | 130mm | 130mm | 130mm | 130mm |
| Brake | Built-in Brake w/ Logic | Built-in Brake w/ Logic | Built-in Brake w/ Logic | Built-in Brake w/ Logic | Built-in Brake w/ Logic | Built-in Brake w/ Logic |
| Encoder type | 17-bit single-turn absolute magnetic encoder | 17-bit single-turn absolute magnetic encoder | 17-bit single-turn absolute magnetic encoder | 17-bit multi-turn absolute magnetic encoder | 17-bit multi-turn absolute magnetic encoder | 17-bit multi-turn absolute magnetic encoder |
| Rated Speed | 3000 rpm | 3000 rpm | 3000 rpm | 3000 rpm | 3000 rpm | 3000 rpm |
| Rated Power | 1500 W | 1500 W | 1500 W | 1500 W | 1500 W | 1500 W |
| Rated Voltage | 48 VDC | 48 VDC | 48 VDC | 48 VDC | 48 VDC | 48 VDC |
| Inertia | 12×10^-4 kg·m² | 12×10^-4 kg·m² | 12×10^-4 kg·m² | 12×10^-4 kg·m² | 12×10^-4 kg·m² | 12×10^-4 kg·m² |
| Voltage Range | 16-52 | 16-52 | 16-52 | 16-52 | 16-52 | 16-52 |
| Protection Level | IP65 | IP65 | IP65 | IP65 | IP65 | IP65 |
| STO Function | Supported | Supported | Supported | Supported | Supported | Supported |
| Body Length | 246.5 mm | 246.5 mm | 246.5 mm | 246.5 mm | 246.5 mm | 246.5 mm |
| Weight | 9.2 kg | 9.2 kg | 9.2 kg | 9.2 kg | 9.2 kg | 9.2 kg |
| Rated Current | 45 A | 45 A | 45 A | 45 A | 45 A | 45 A |
* Scroll horizontally within the table area when the content is wide.
Specifications
| Shaft Diameter | Φ22 |
| Drive Mode | Adopting FOC field-oriented control technology and SVPWM |
| Encoder | 17-bit single-turn absolute encoder (multi-turn absolute counting, automatic storage upon power failure) or 17-bit multi-turn absolute encoder (external battery backup) |
| CiA402 Mode | PP, VM, PV, PT, HM, IP, CSP, CSV, CST |
| NiMotion mode | Position mode: Pulse control, multi-segment position control, digital input control, analog input control Speed mode: Pulse control, multi-segment speed control, digital input control, analog input control Torque mode: Digital input control, analog input control |
| Control Modes | CiA402 Mode,Manufacturer Mode |
| External Control Interface | DI – Non-isolated NPN Input,DI – Non-isolated PNP Input,DI – Non-isolated Switch Input,DI – Isolated Opto Single-Ended Input,DI – Isolated Opto Differential Input,DO – Isolated Open-Drain Output,AI – ±10V Analog Input |
| DI (Digital Input) | Quantity: 3 units; high-speed unidirectional optocoupler; supports maximum PWM pulse frequency: 2MHz; compatible with PNP, NPN, and differential input; high level: 5–24V, low level: 0–0. 5V. Configurable functions 1. Can be used as a switch.2. Can be used as a pulse input channe,(this DI is unavailable for motors with STO function). |
| DO (Digital Output) | Quantity: 1 unit; Output method: Supports optocoupler output, open collector; Maximum current 100mA, maximum voltage 55V (≥1kHz). 1.General-purpose DO port.2 Motor run/stop 3. Target reached.4.Alarm output.(When the motor status meets the above conditions, the DO switch status changes.) |
| DX (Digital Input / Output) | - |
| AI (Analog Input) | Quantity: 1; Input method: single-ended input; Signal type: voltage signal; Resolution: 12-bit; Voltage: -10~10V; Accuracy: reference error ≤1%; Configurable functions: dead zone, filtering, offset, scaling, direction. |
| Operating Temperature | 0°C to 40°C |
| Operating Altitude | <1000m |
| Fault Alarm | Overvoltage, undervoltage, overtemperature, locked rotor, overload, overspeed |
| Servo Function | Soft limit, gain switching, S-curve planning, vibration suppression, parameter identification, online upgrade |
Torque-Speed Characteristics
PSMP1301K5X-COE/CANopen/485-XX
Product Details
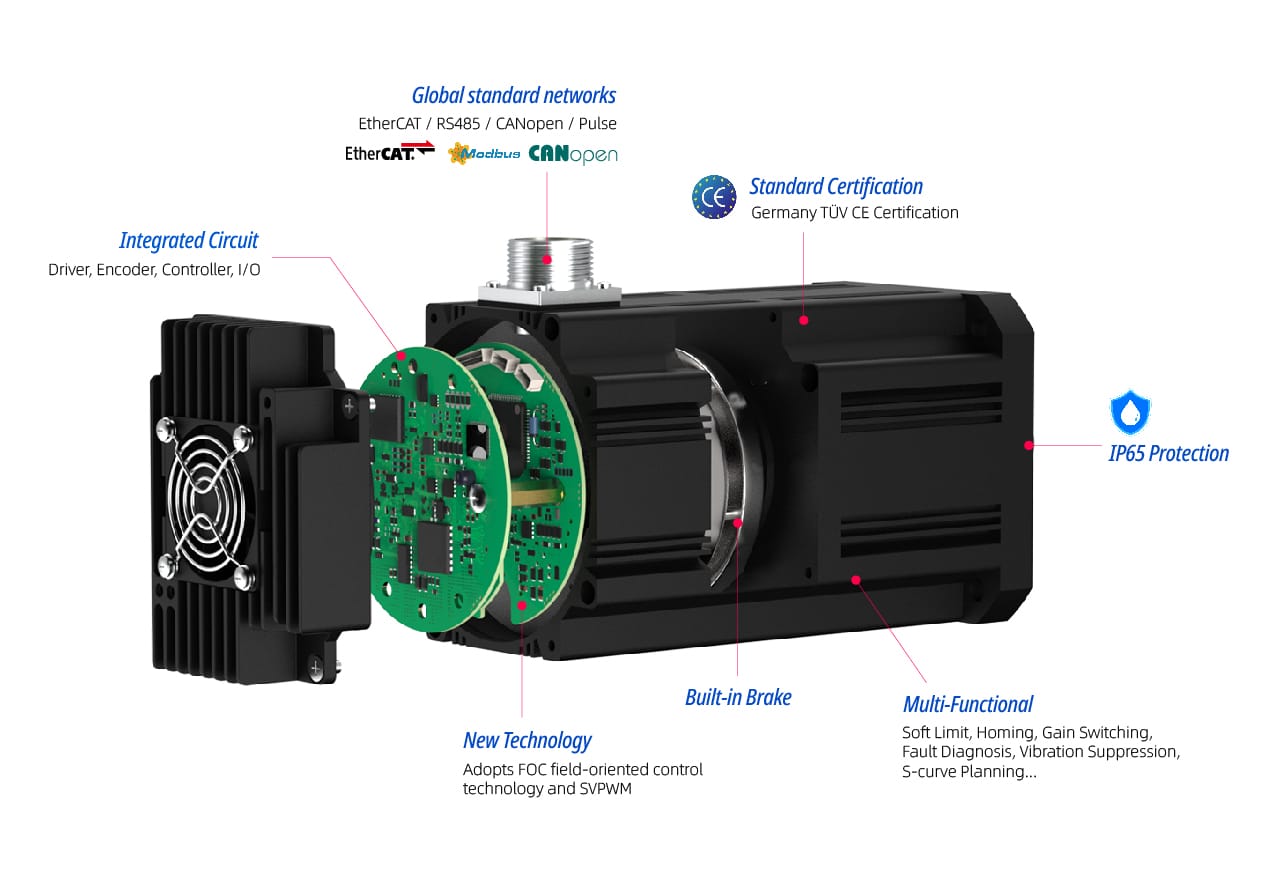
The PSMP130 series of integrated low-voltage servo motors is a servo product with a protective STO function developed by NiMotion. Based on the concept of highly compact integrated development, this product integrates a permanent magnet synchronous motor, absolute encoder, bus-type servo drive and digital I/O. It adopts FOC (field-oriented control) and SVPWM, supports EtherCAT, CANopen and RS485 bus control, and has the characteristics of compact structure and simple wiring.
Product Features
Highly integrated design
Integrates permanent magnet synchronous motor, absolute encoder, bus-type servo drive and digital I/O into a single compact unit, so no external drive is required. Compared with conventional separated solutions it saves considerable installation space, needs less wiring, and makes commissioning and maintenance easier.
Advanced Drive Algorithm
Adopts FOC (field-oriented control) and SVPWM for smooth torque output, excellent low-speed performance and lower operating noise and vibration.
High Precision Encoder Feedback
Built-in 17-encoder or 17-bit multi-turn absolute encoder (external battery slack) provides real-time position and speed feedback for more accurate closed-loop control; multi-turn absolute counting and automatic position storage on power loss mean no re-homing is needed after power-up.
Multi-bus communication support
Supports EtherCAT, CANopen and RS485 communication, allowing quick connection to mainstream PLCs, motion controllers and host systems, with flexible networking and easy expansion.
Multiple Control Modes
Supports multiple control modes and standard CiA 402 motion modes (PP, PV, HM, CSP, etc.), switchable via fieldbus, pulse train, analog input or digital I/O to suit different host systems.
Wide Voltage Input
Wide input voltage range of 16-52 VDC, suitable for various power-supply environments and giving greater flexibility in system integration and retrofitting.
Digital Inputs / Outputs
Built-in digital inputs and outputs (DI/DO) that can be configured for enable, forward/reverse limit switches, home sensor, alarm output, brake control and more, allowing direct interfacing with sensors and PLCs without additional I/O modules and simplifying field wiring.
Integrated High-precision Encoder
An integrated high-resolution absolute encoder provides real-time rotor position and speed feedback for full closed-loop control. Multi-turn absolute versions store the position when power is lost, so no re-homing is required after power-up, giving more accurate positioning and smoother low-speed operation.
Homing and Origin Setting
Multiple homing (origin return) modes with configurable homing direction, speed and origin offset, allowing the mechanical origin to be re-established quickly after power loss or an abnormal stop and ensuring repeat positioning accuracy.
Gain Switching
Several gain sets can be stored and switched, with online auto-tuning available. Gains can be changed automatically or manually according to load inertia and operating speed, balancing fast response with smooth low-speed operation for quicker commissioning.
16-segment Position / Velocity & S-curve Planning
A built-in 16-segment position and velocity instruction function combined with S-curve acceleration/deceleration planning enables smooth multi-point positioning with reduced start/stop shock and mechanical vibration, improving cycle time and motion smoothness.
Resonance Suppression
Resonance suppression automatically identifies and sets mechanical resonance frequencies and uses notch filtering to suppress mid- and high-frequency resonance, reducing operating noise and improving positioning stability and path accuracy.
Low-frequency Vibration Suppression
Low-frequency vibration suppression compensates the residual sway of long arms, belts and other flexible loads, giving faster settling and more stable positioning in high-speed point-to-point applications.
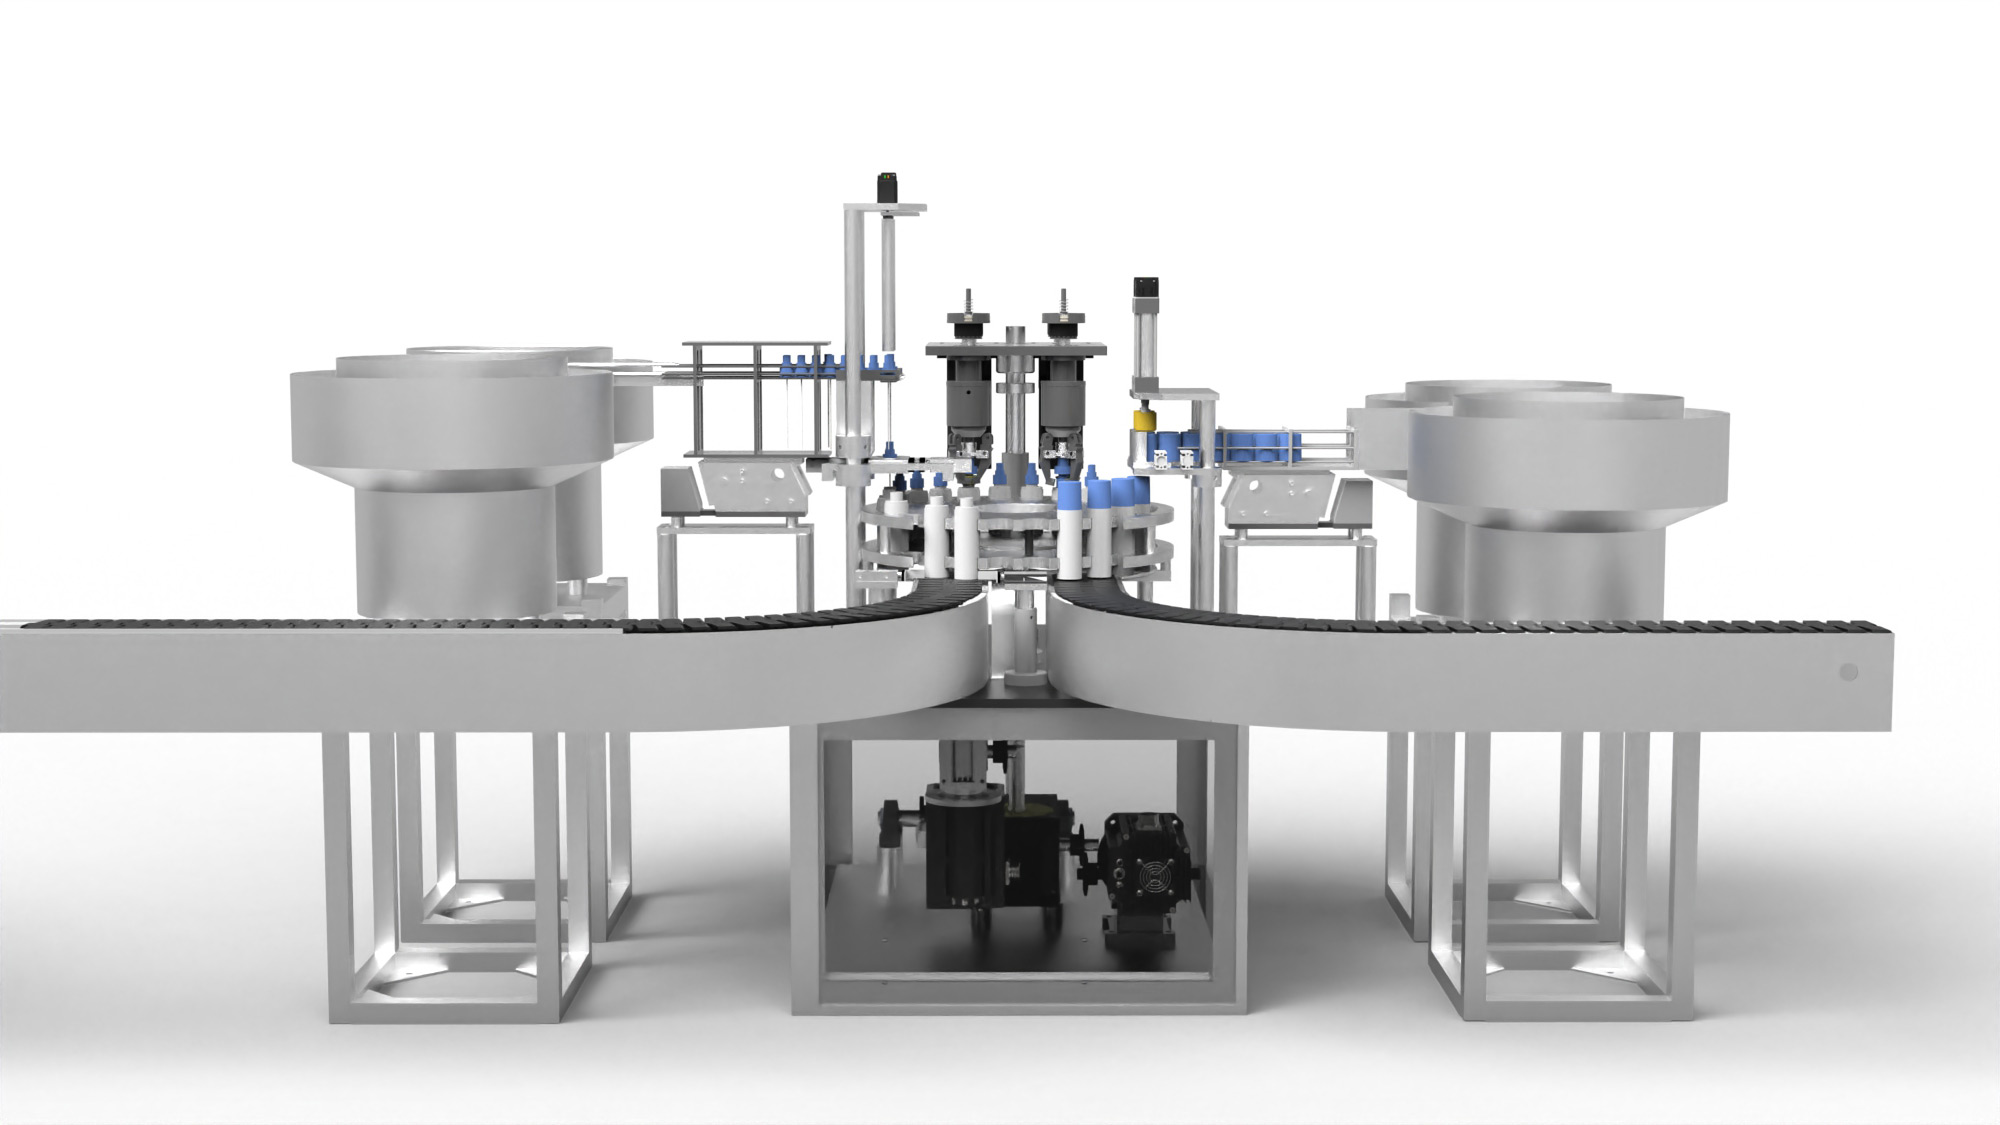
Application of filling machine equipment
The integrated motor is applied to the filling machine equipment. It has a small size, and the servo motor meets high precision, high speed, high reliability requirements as well as those for specific industries. It supports rapid start-stop and speed adjustment to match efficient production. The PSMP series is equipped with IP65 protection to prevent liquid and dust from entering.
Downloads
Companion Products
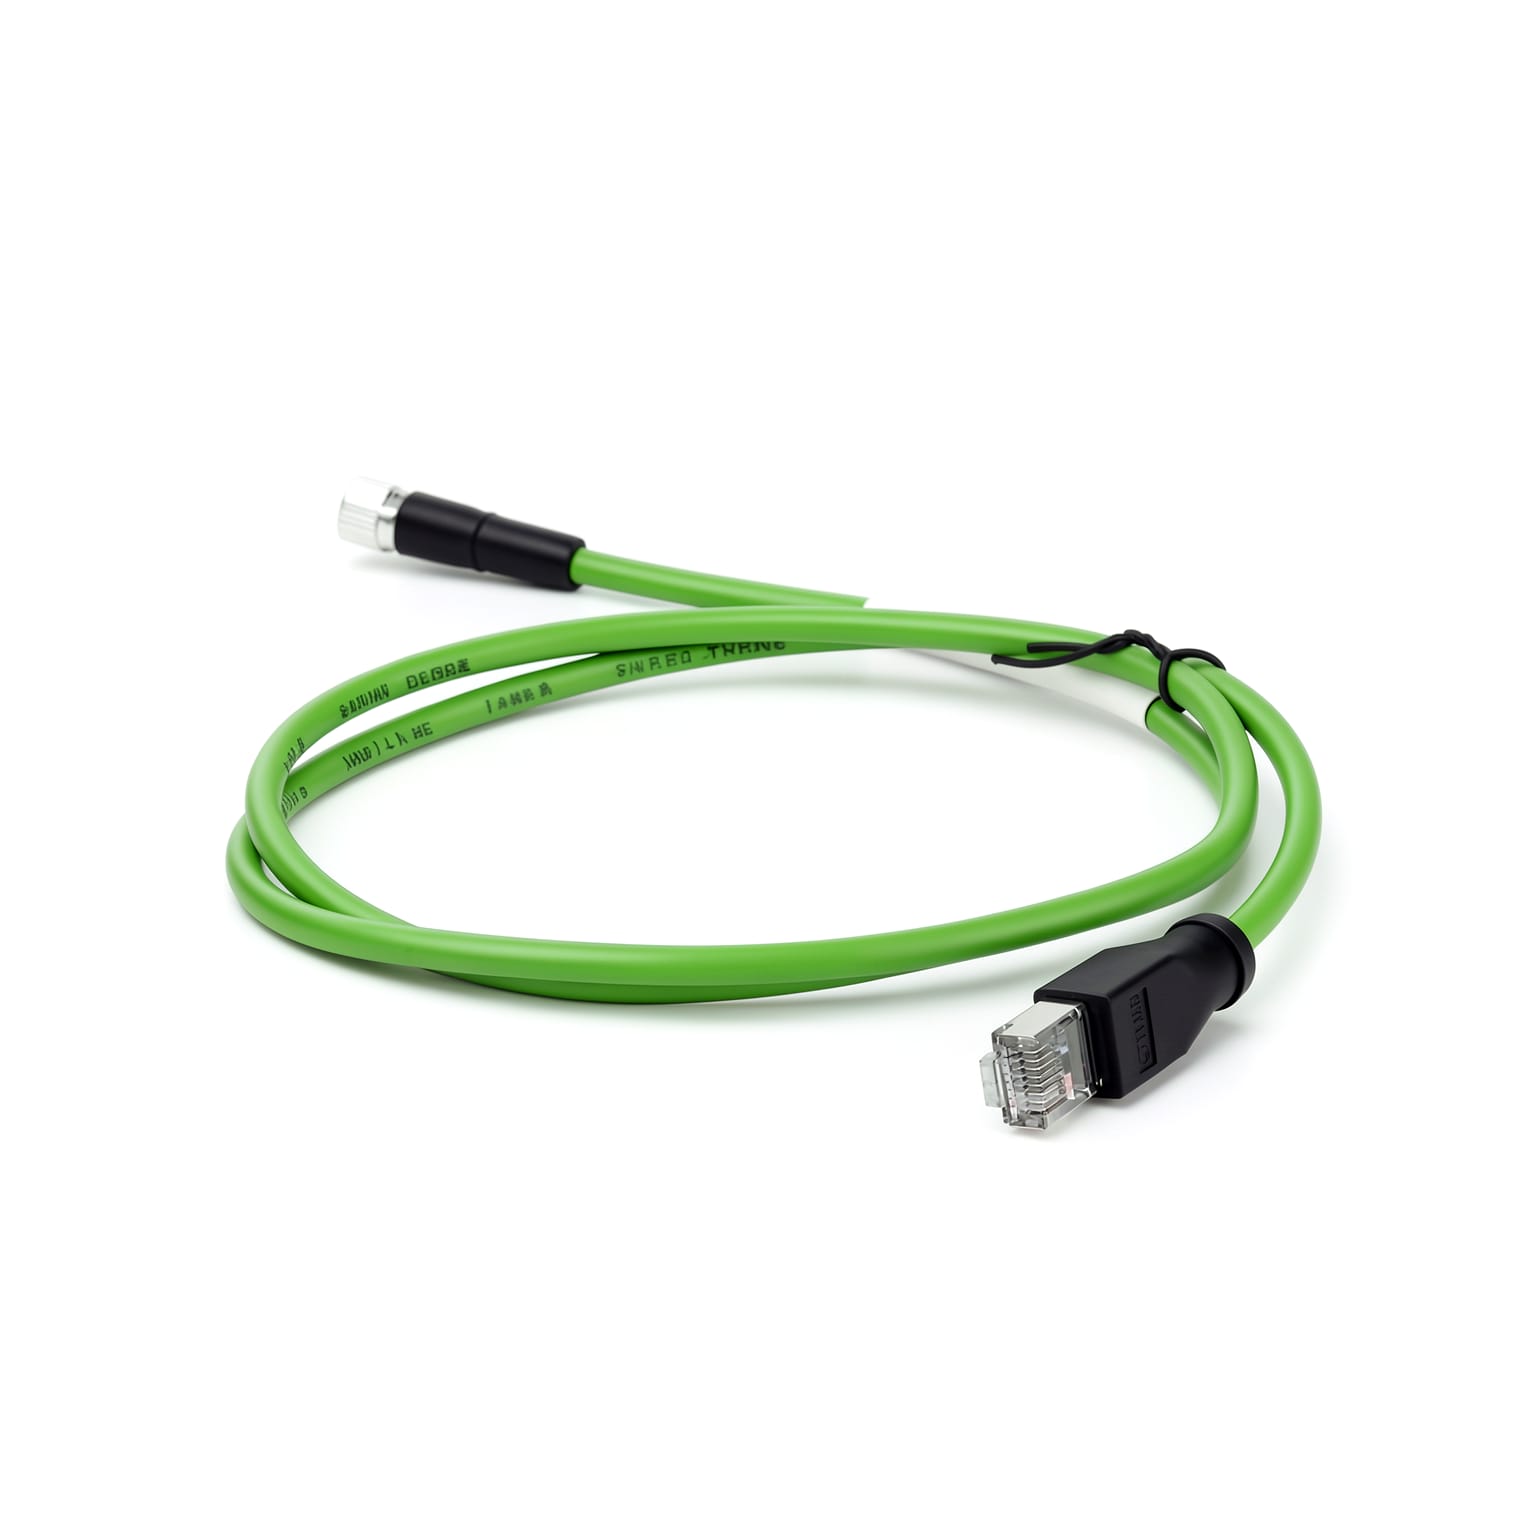
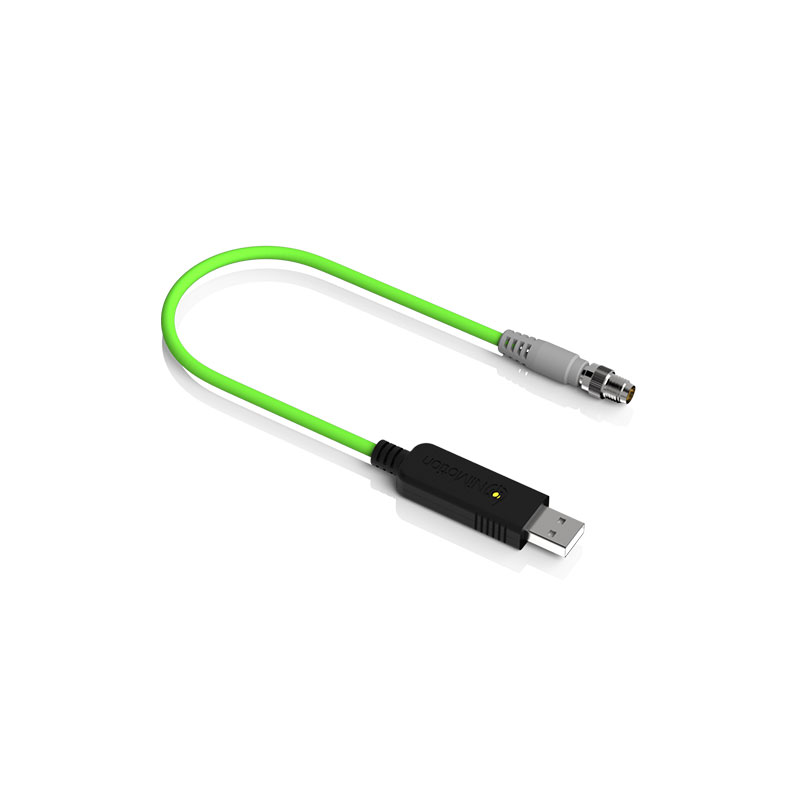
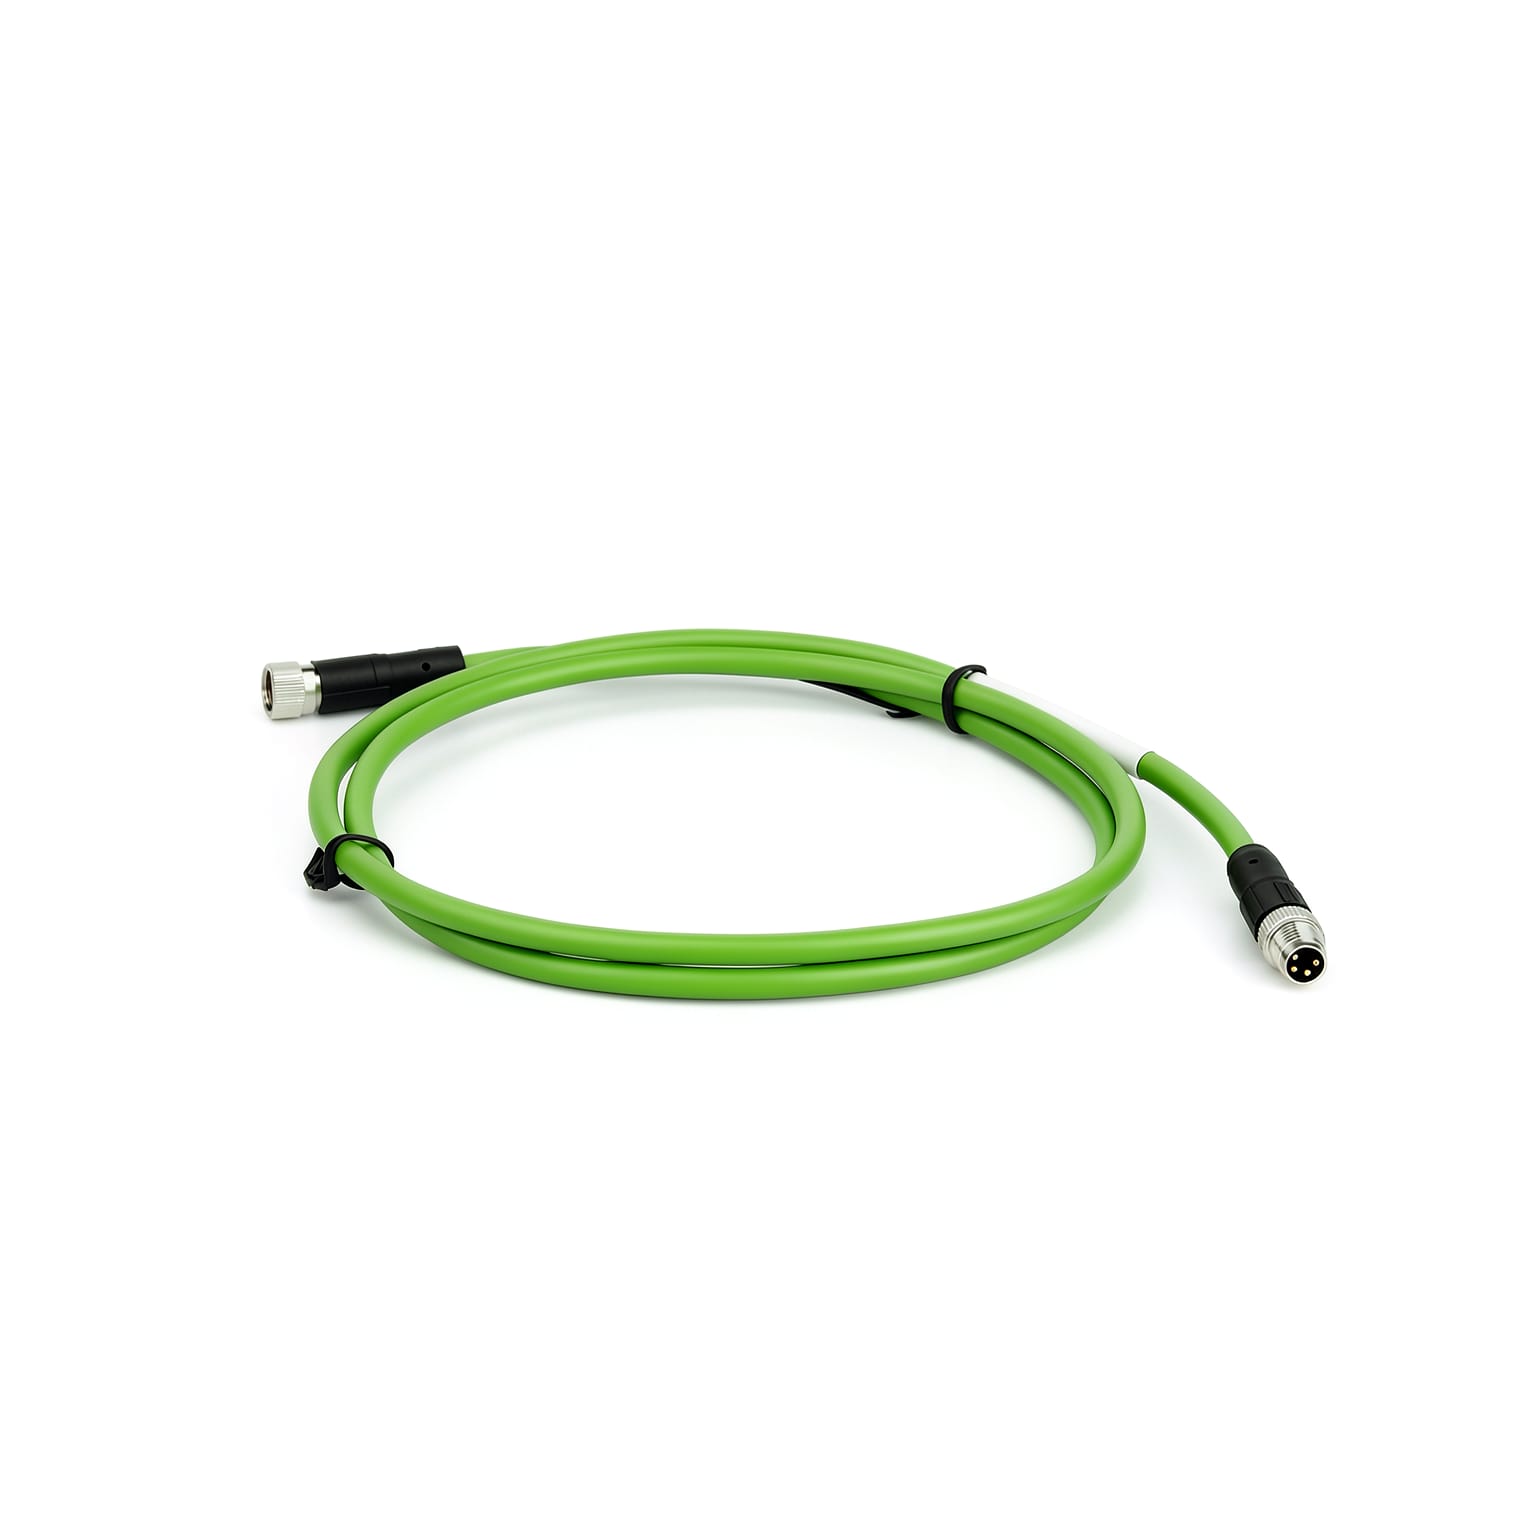
Communication cable for NiMotion integrated motors.
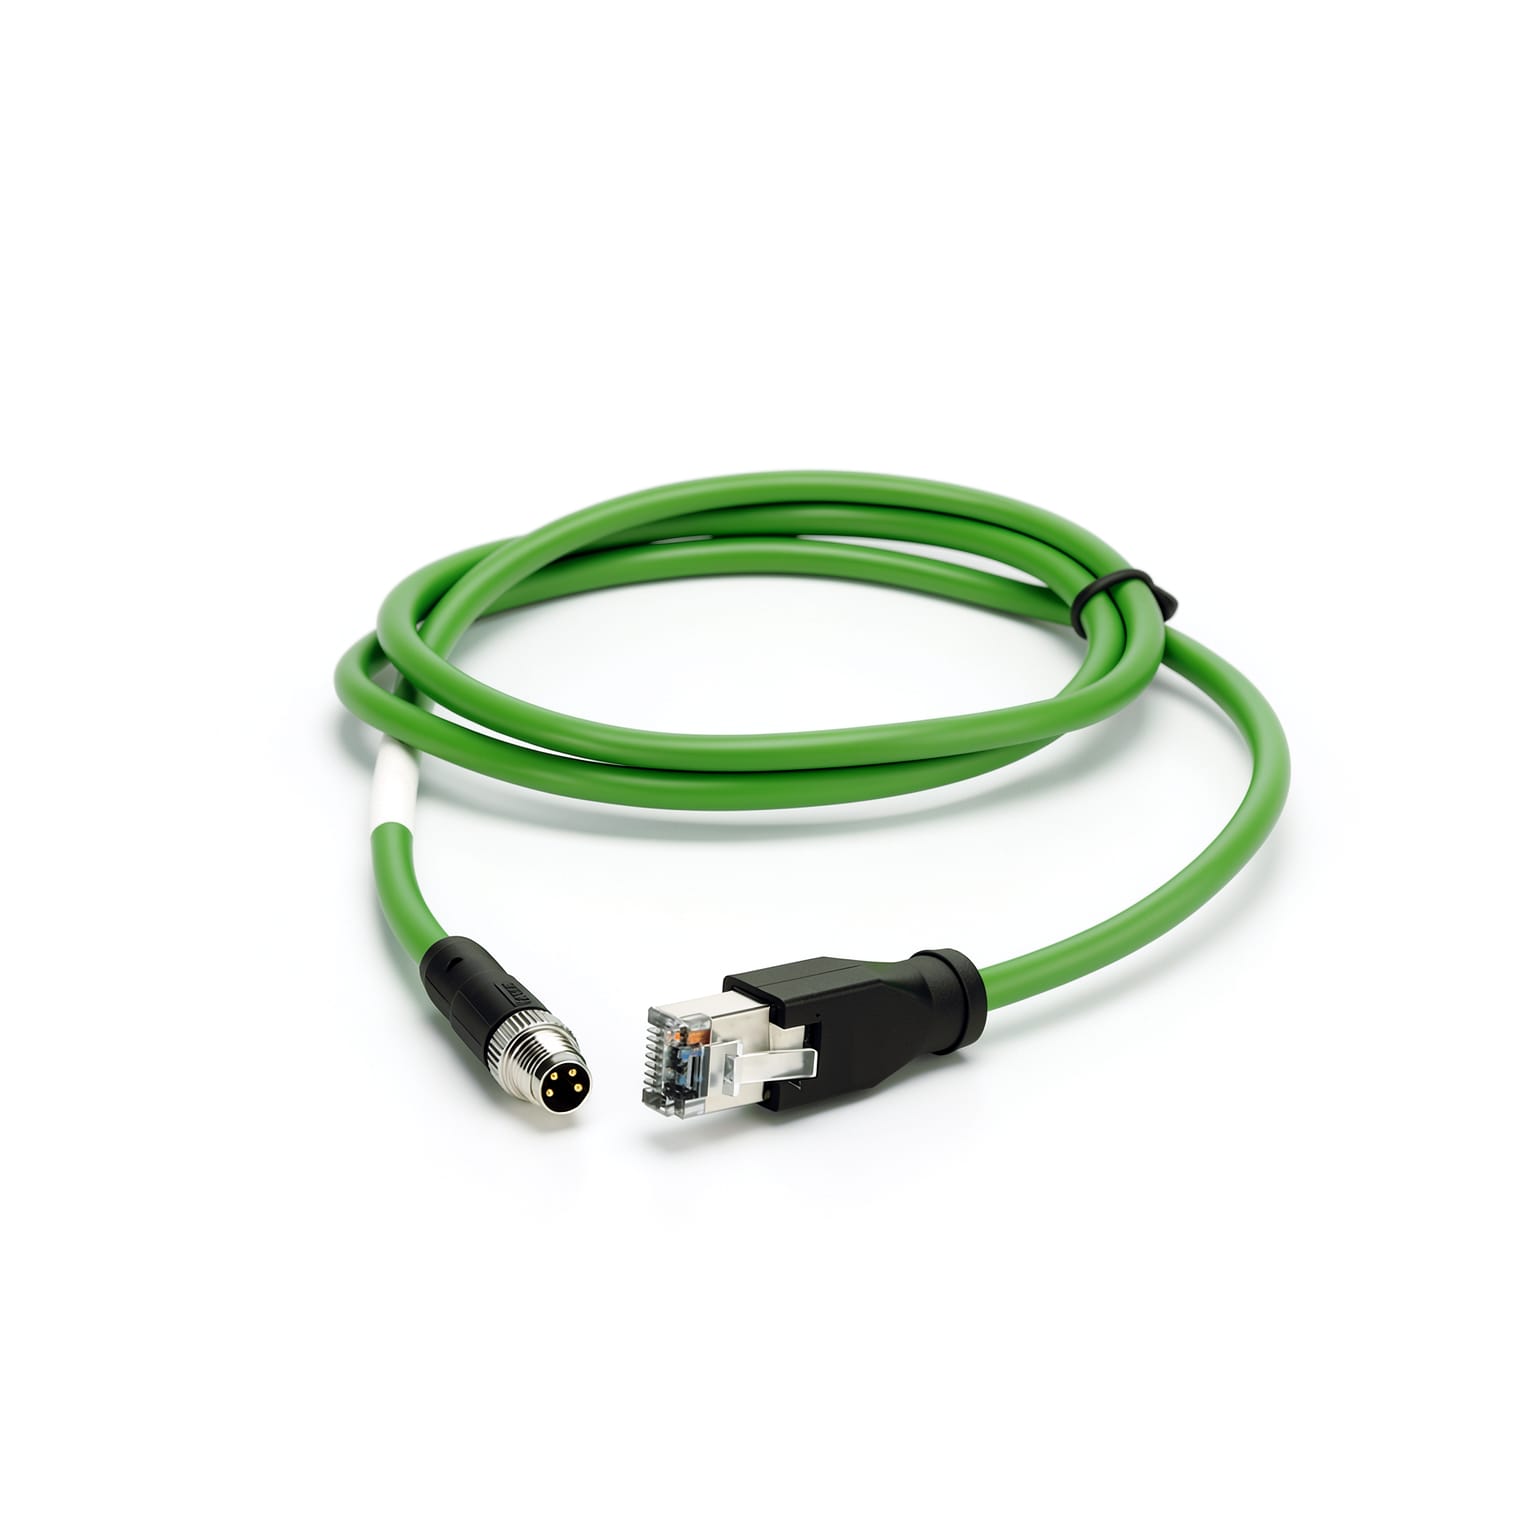
Communication cable for NiMotion integrated motors.
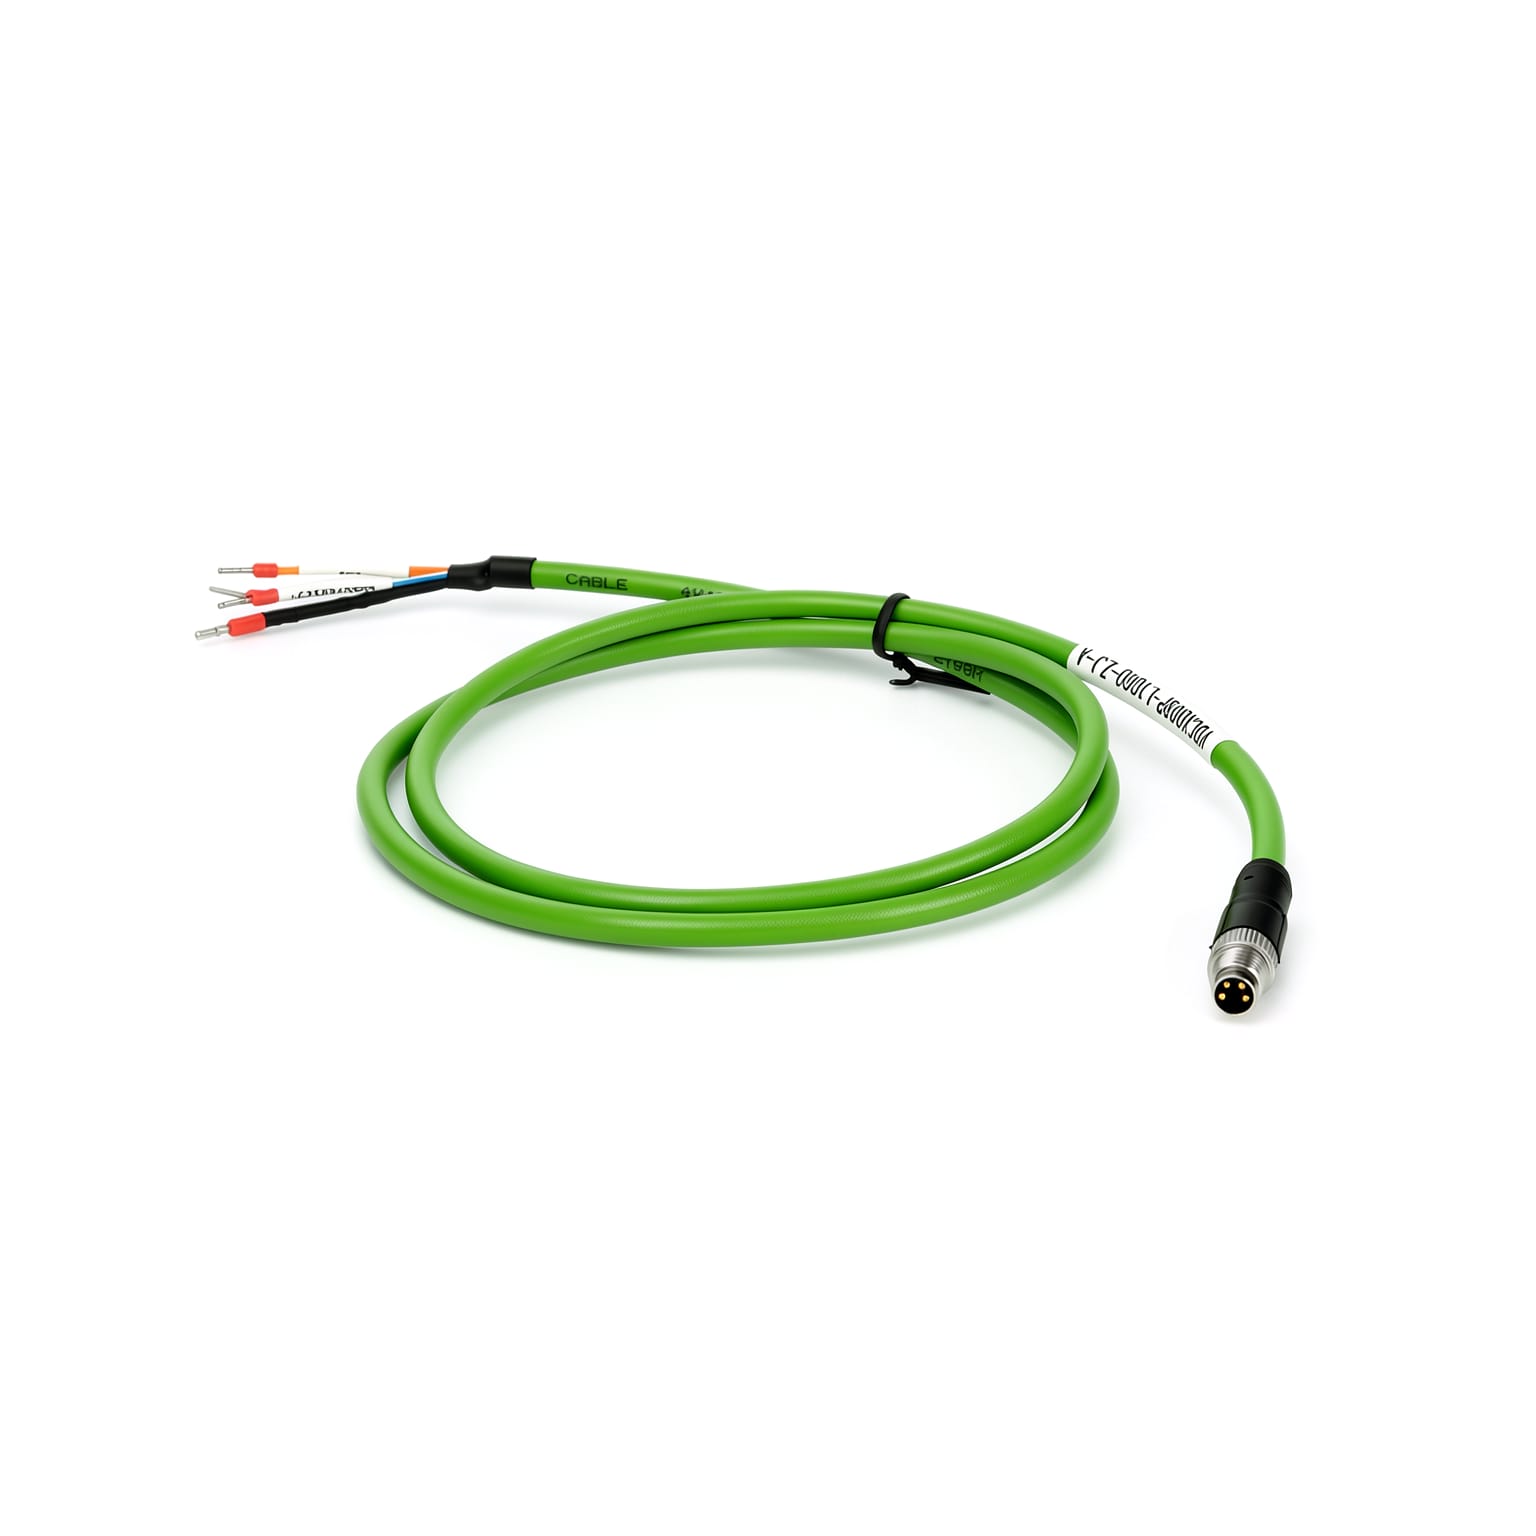
Communication cable for NiMotion integrated motors.
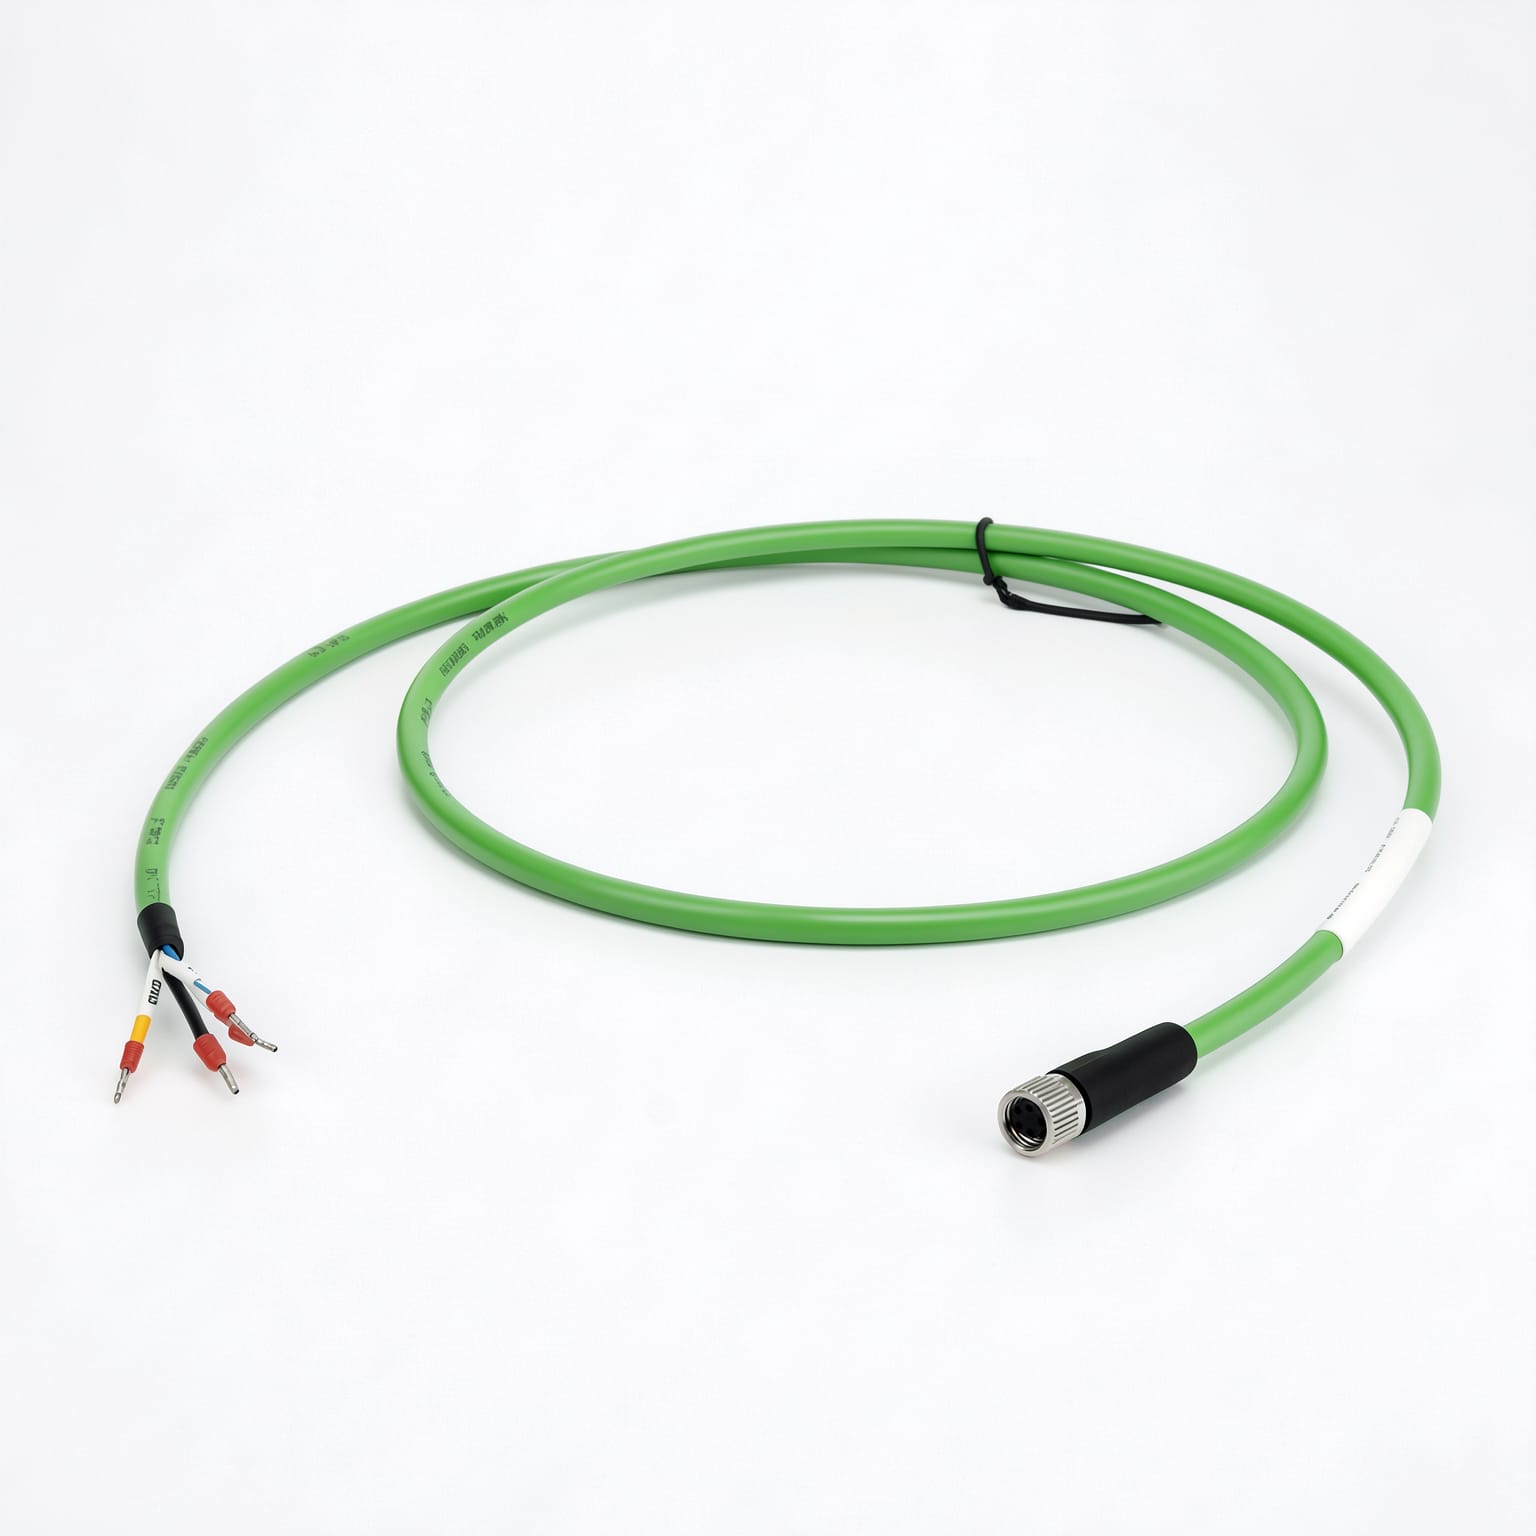
Communication cable for NiMotion integrated motors.
USB to CAN converter with isolation, IP65 protection, and secondary development SDK support.
USB to RS485 converter with active termination, isolation, IP65 protection, and secondary development SDK support.
FAQ
The positional accuracy of a stepper motor is about 3‑5% of the step angle, and it does not accumulate errors.
Microstepping is essentially an electronic damping technique, primarily designed to reduce or eliminate low‑frequency vibration. Improved positional resolution is a secondary benefit. Different manufacturers’ microstepping drivers can vary greatly in accuracy, and higher microstepping numbers are harder to control precisely.
This is due to the motor’s pull‑in rate – the maximum pulse frequency at which it can start from standstill without losing steps. If the pulse frequency exceeds this rate, the motor cannot start properly and may lose steps or stall. The solution is to use an acceleration ramp: start at a low frequency and gradually increase to the target high frequency. Integrated stepper motors allow you to set acceleration and deceleration parameters freely.
When the motor rotates, the inductance in each phase winding generates a back‑EMF. The higher the frequency, the greater the back‑EMF, which reduces the phase current and thus lowers the torque.
Excessive temperature can demagnetise the magnetic material, reducing torque and causing step loss. The demagnetisation point is generally above 130°C, some up to 200°C. Therefore, a surface temperature of 80‑90°C is perfectly normal for a stepper motor. The most common insulation class is Class B, with a rated operating temperature up to 130°C.
Applications
Discover how this product is applied across various industrial automation scenarios.
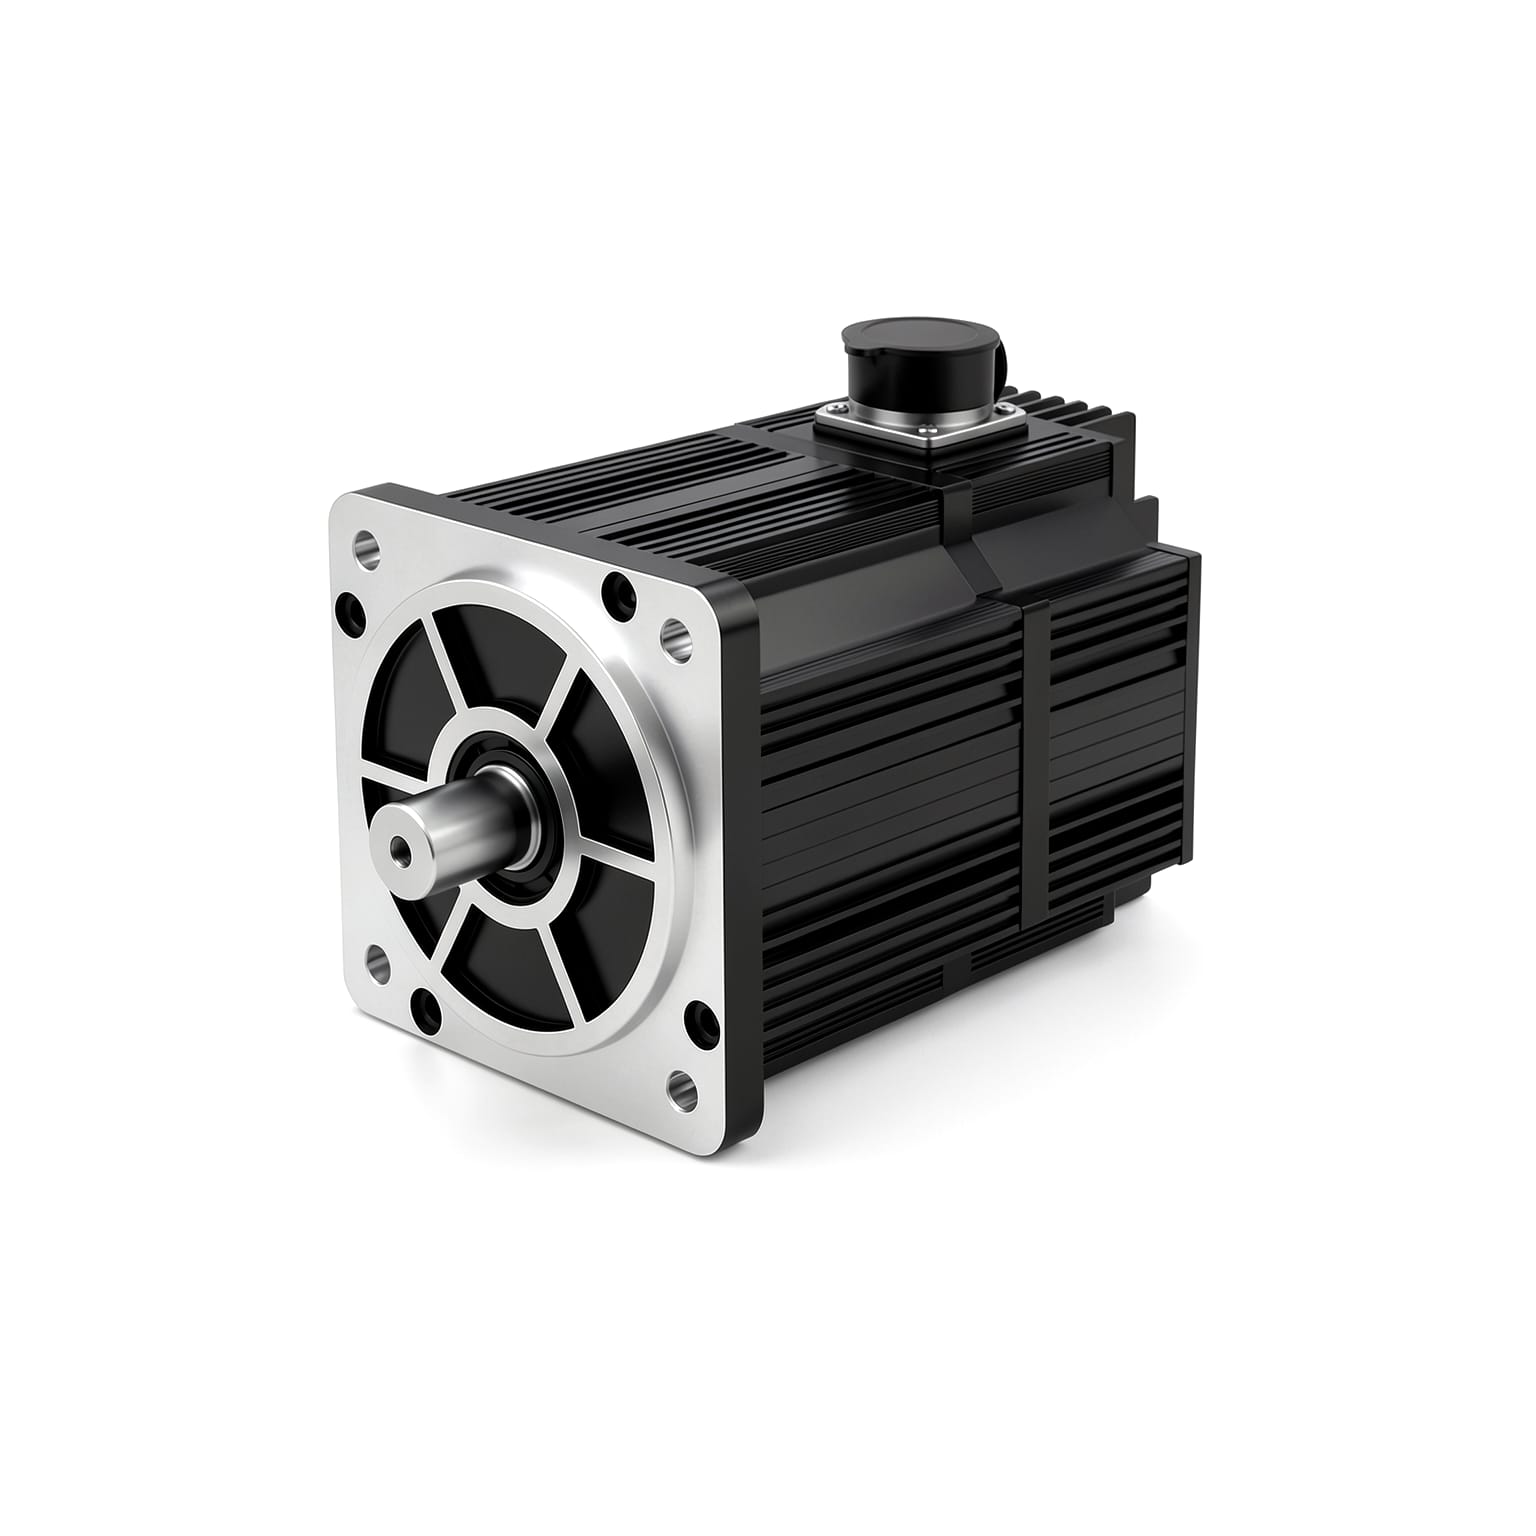
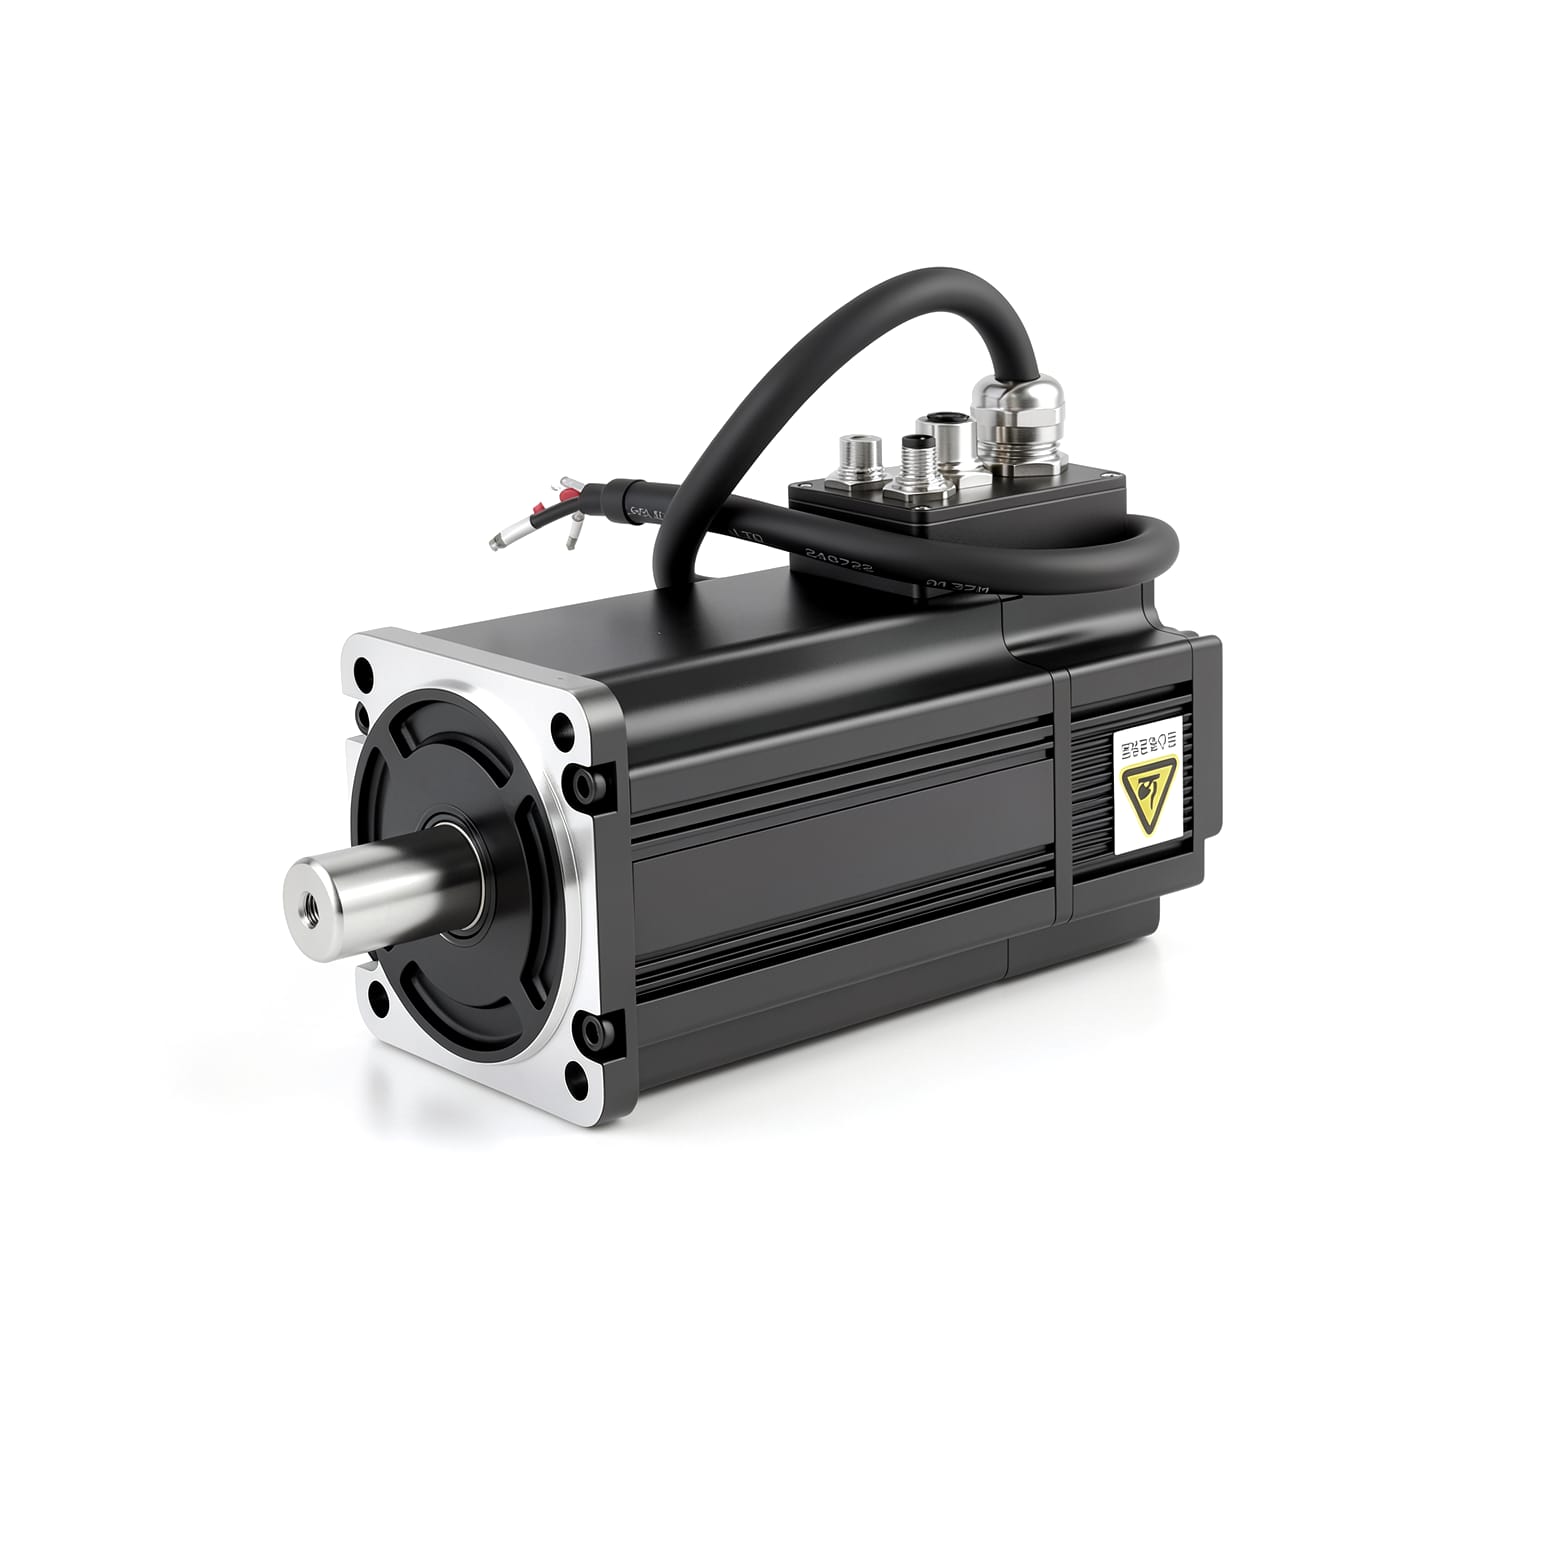
Compatible Products
Build complete and reliable solutions with our compatible products.
Technical Resources
Technical guides, application notes, and more to help you get the most out of the product.
Ready to start your automation project?
Talk to our engineers and get a customized motion control solution within 24 hours.
Typical response time: 24 hours