STM42 (Open-Loop) Integrated Stepper Motor
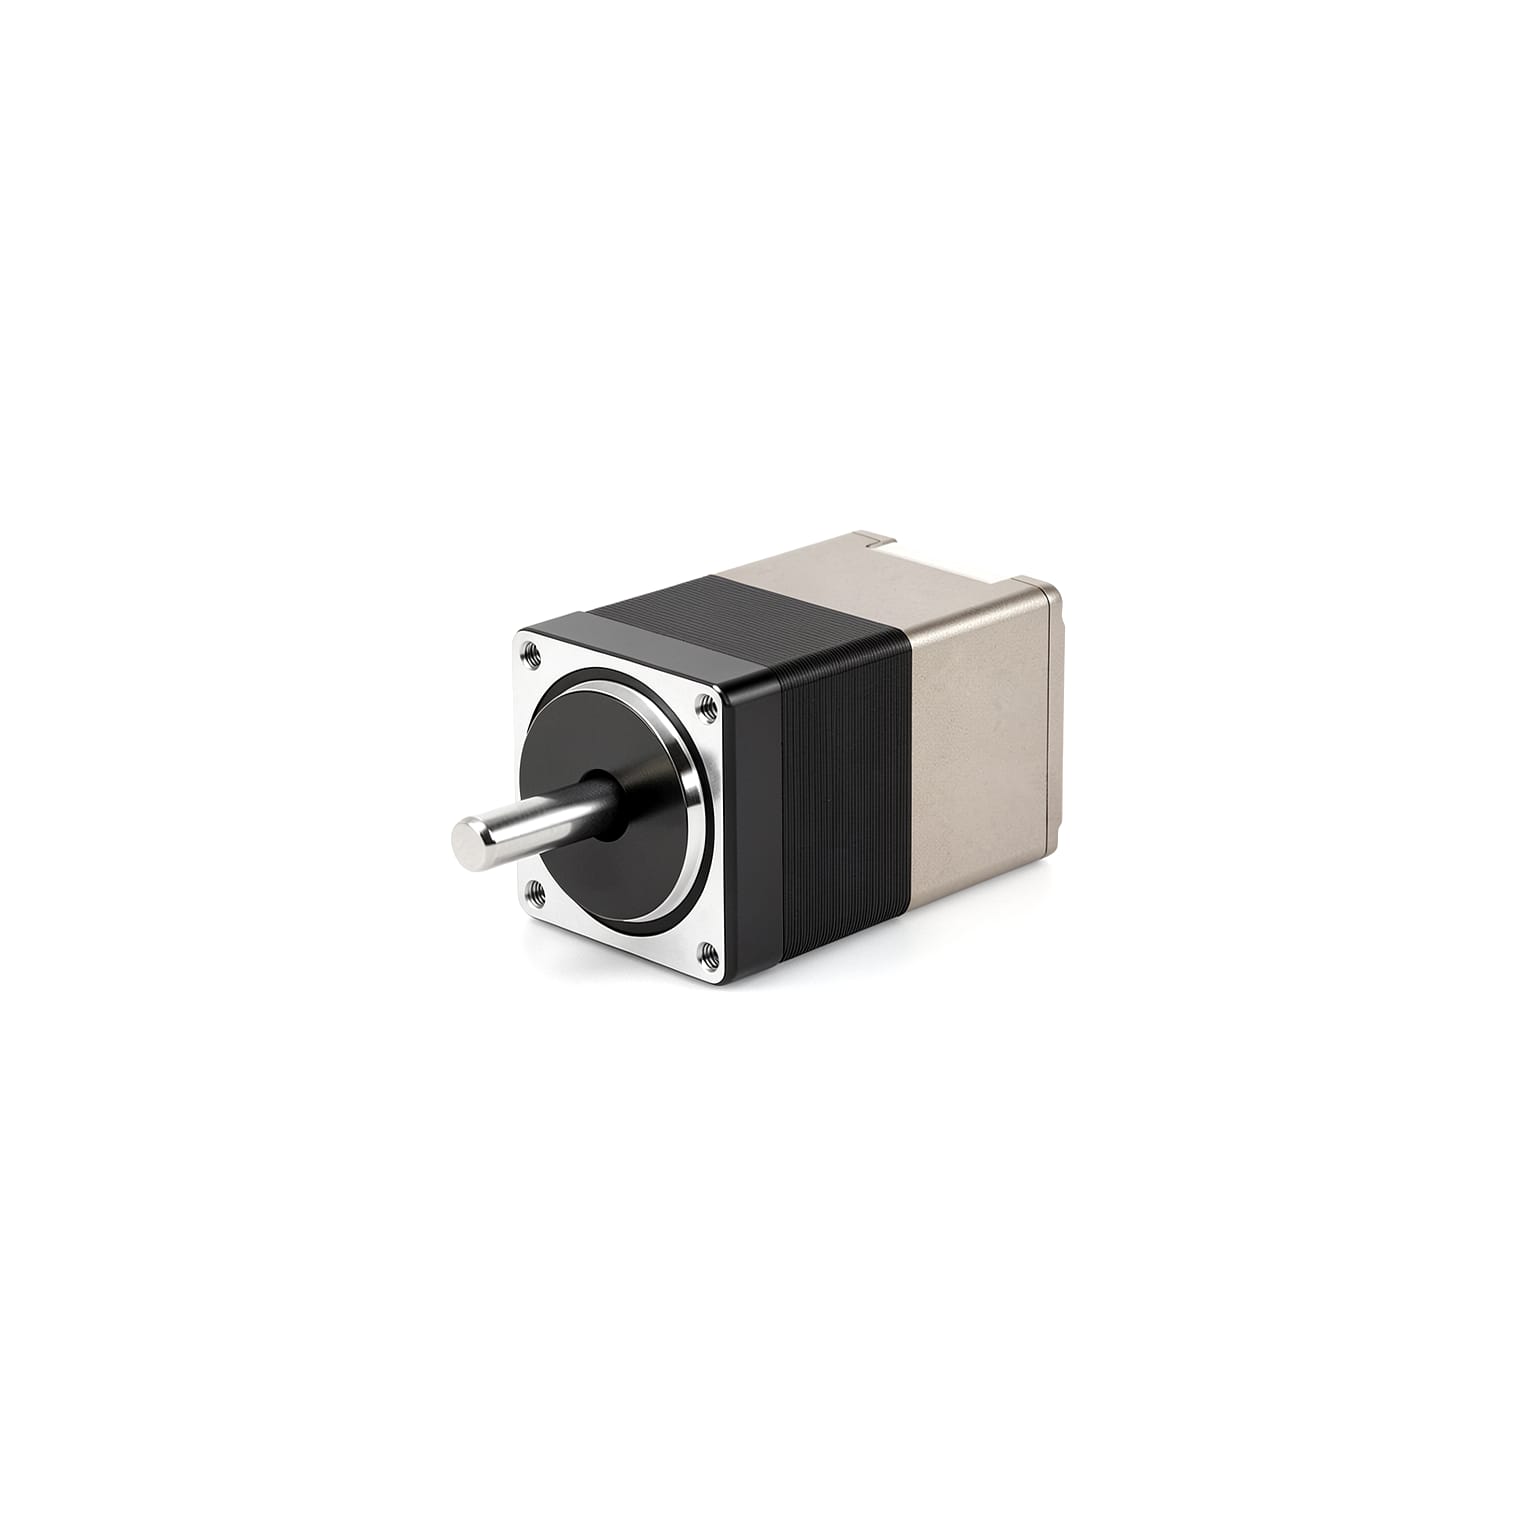
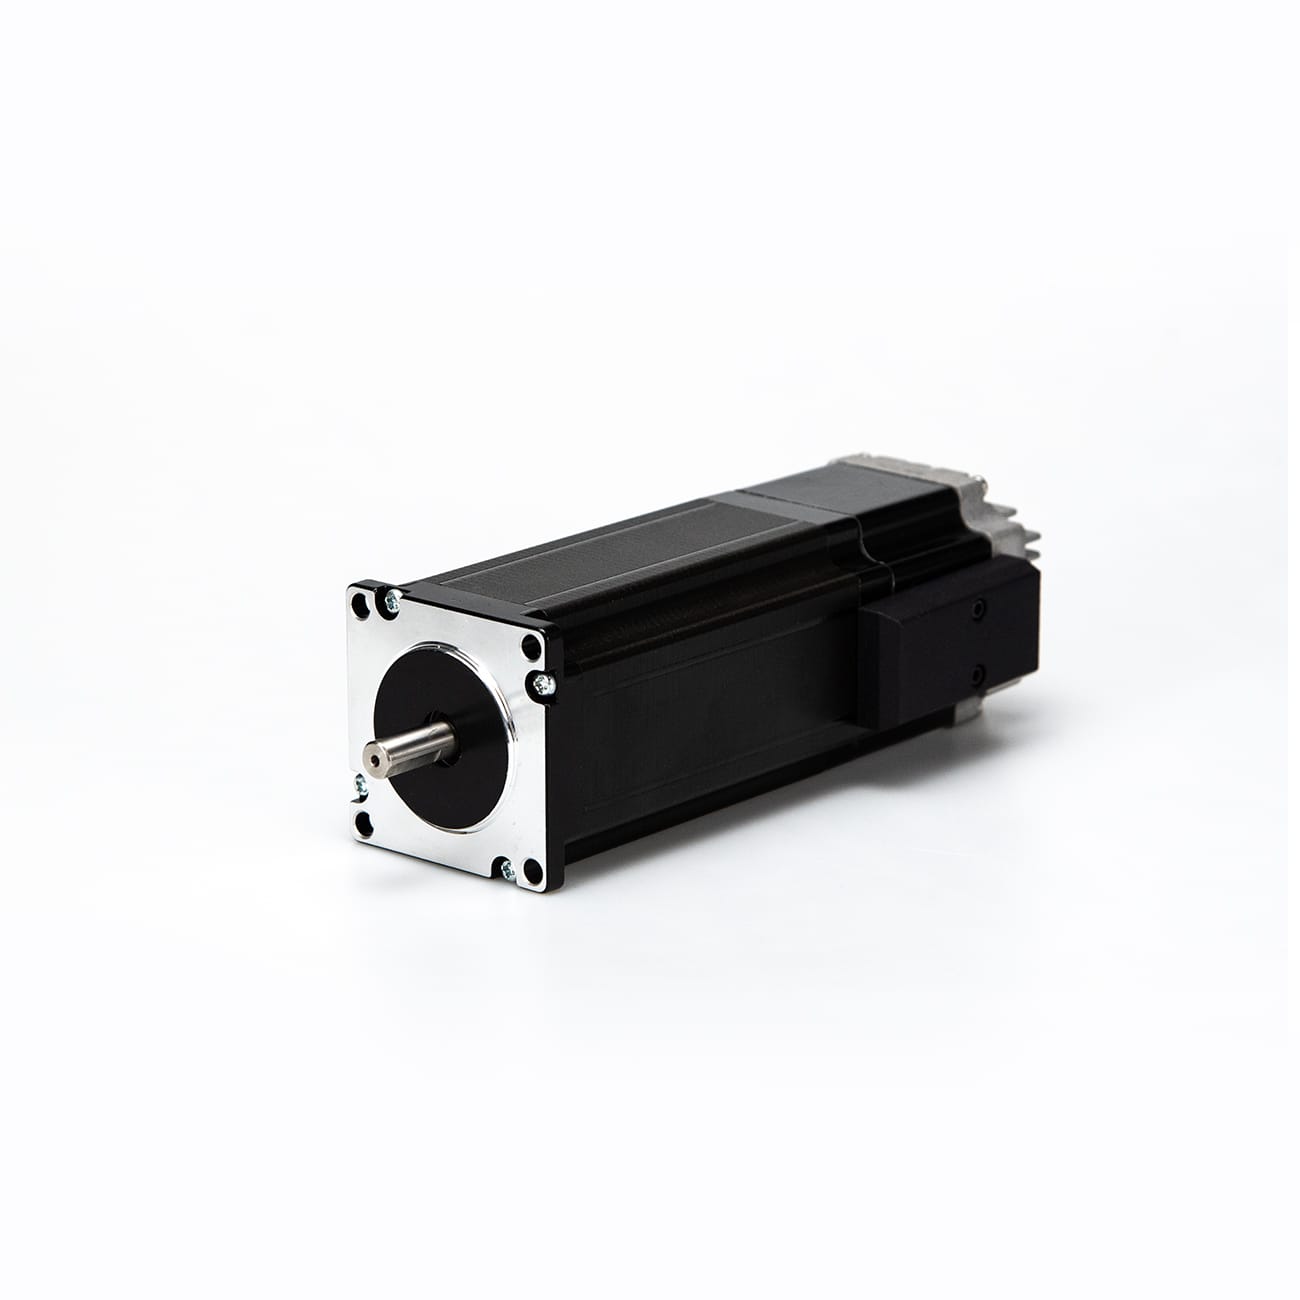
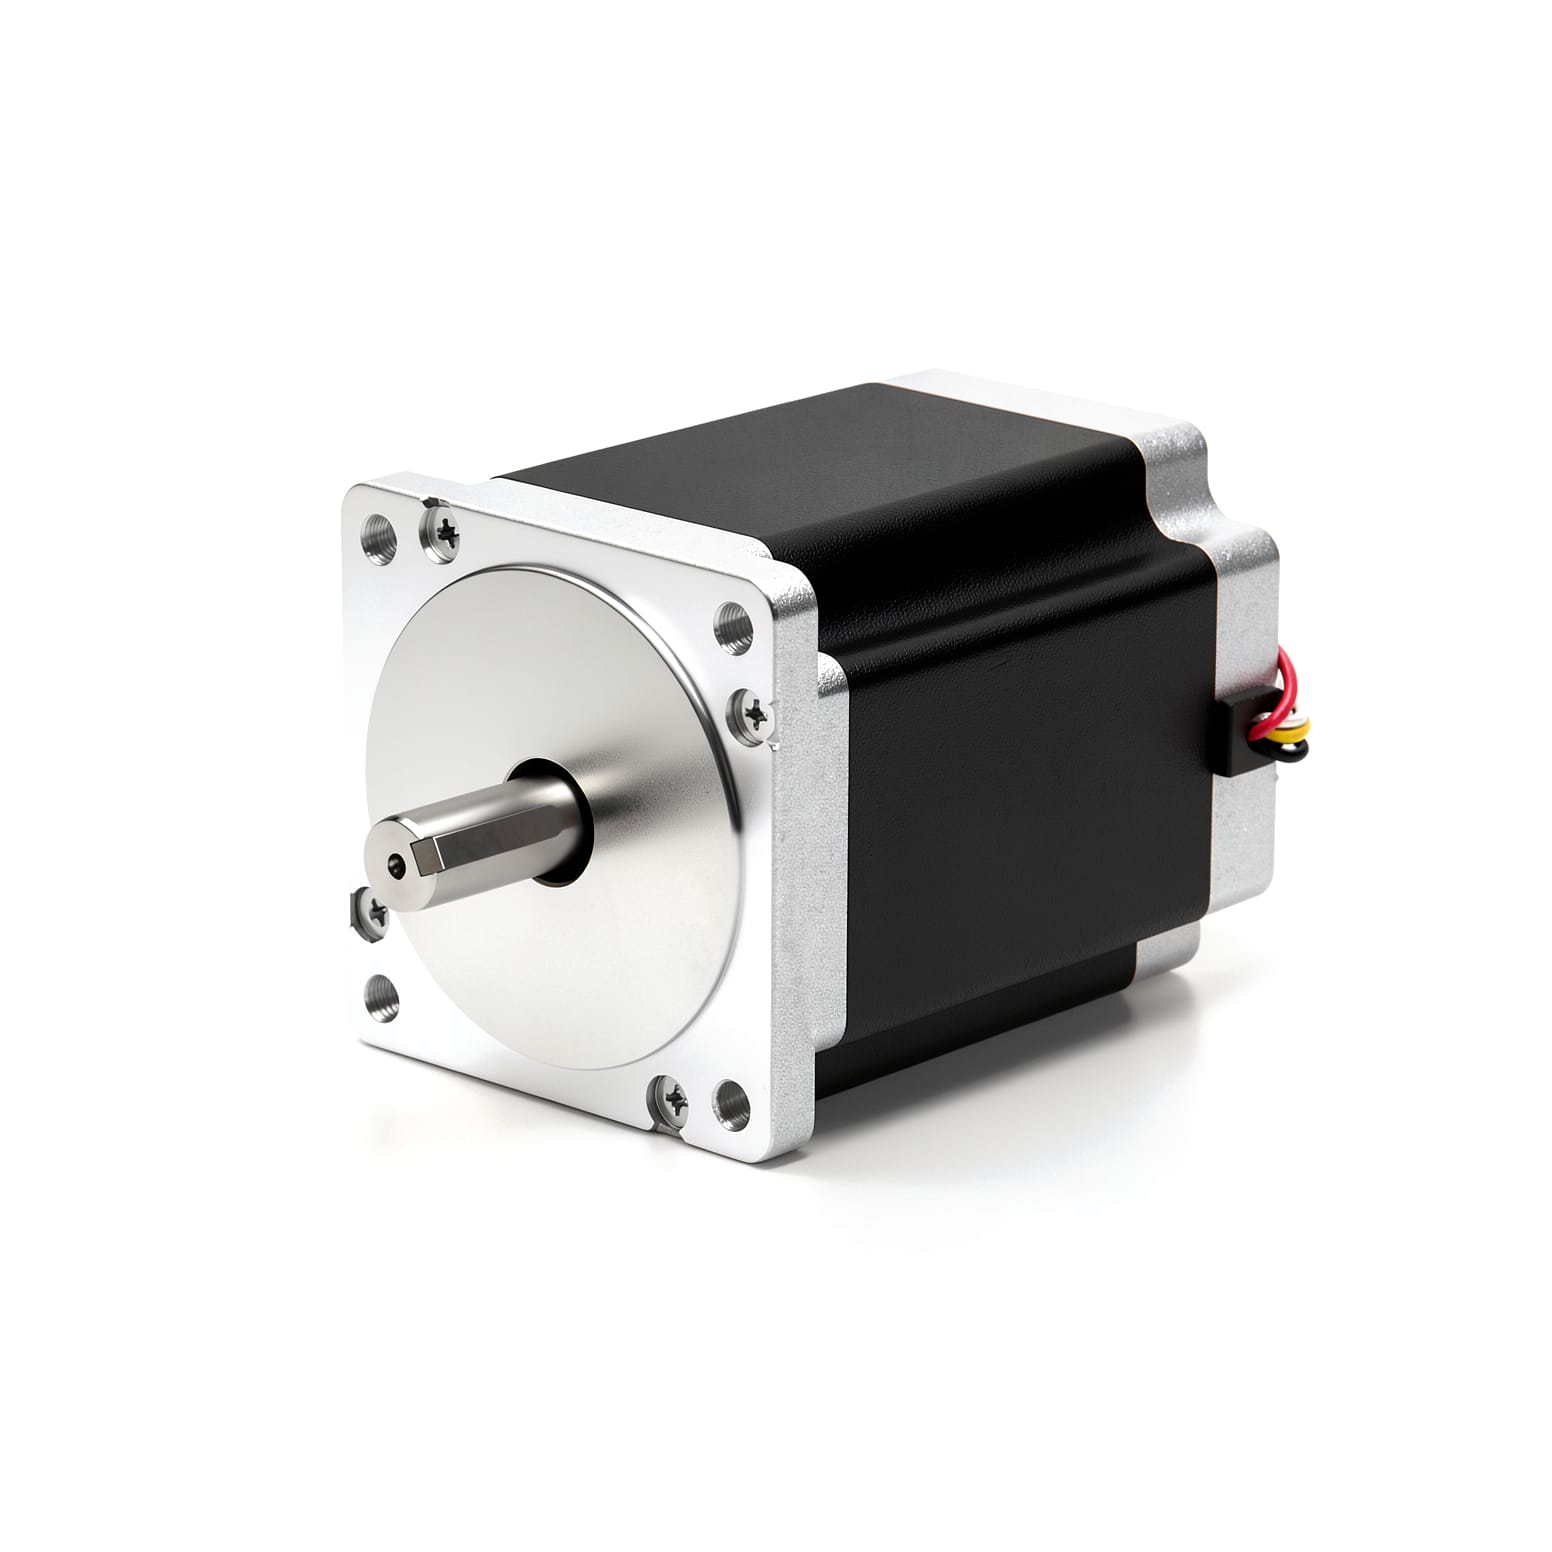
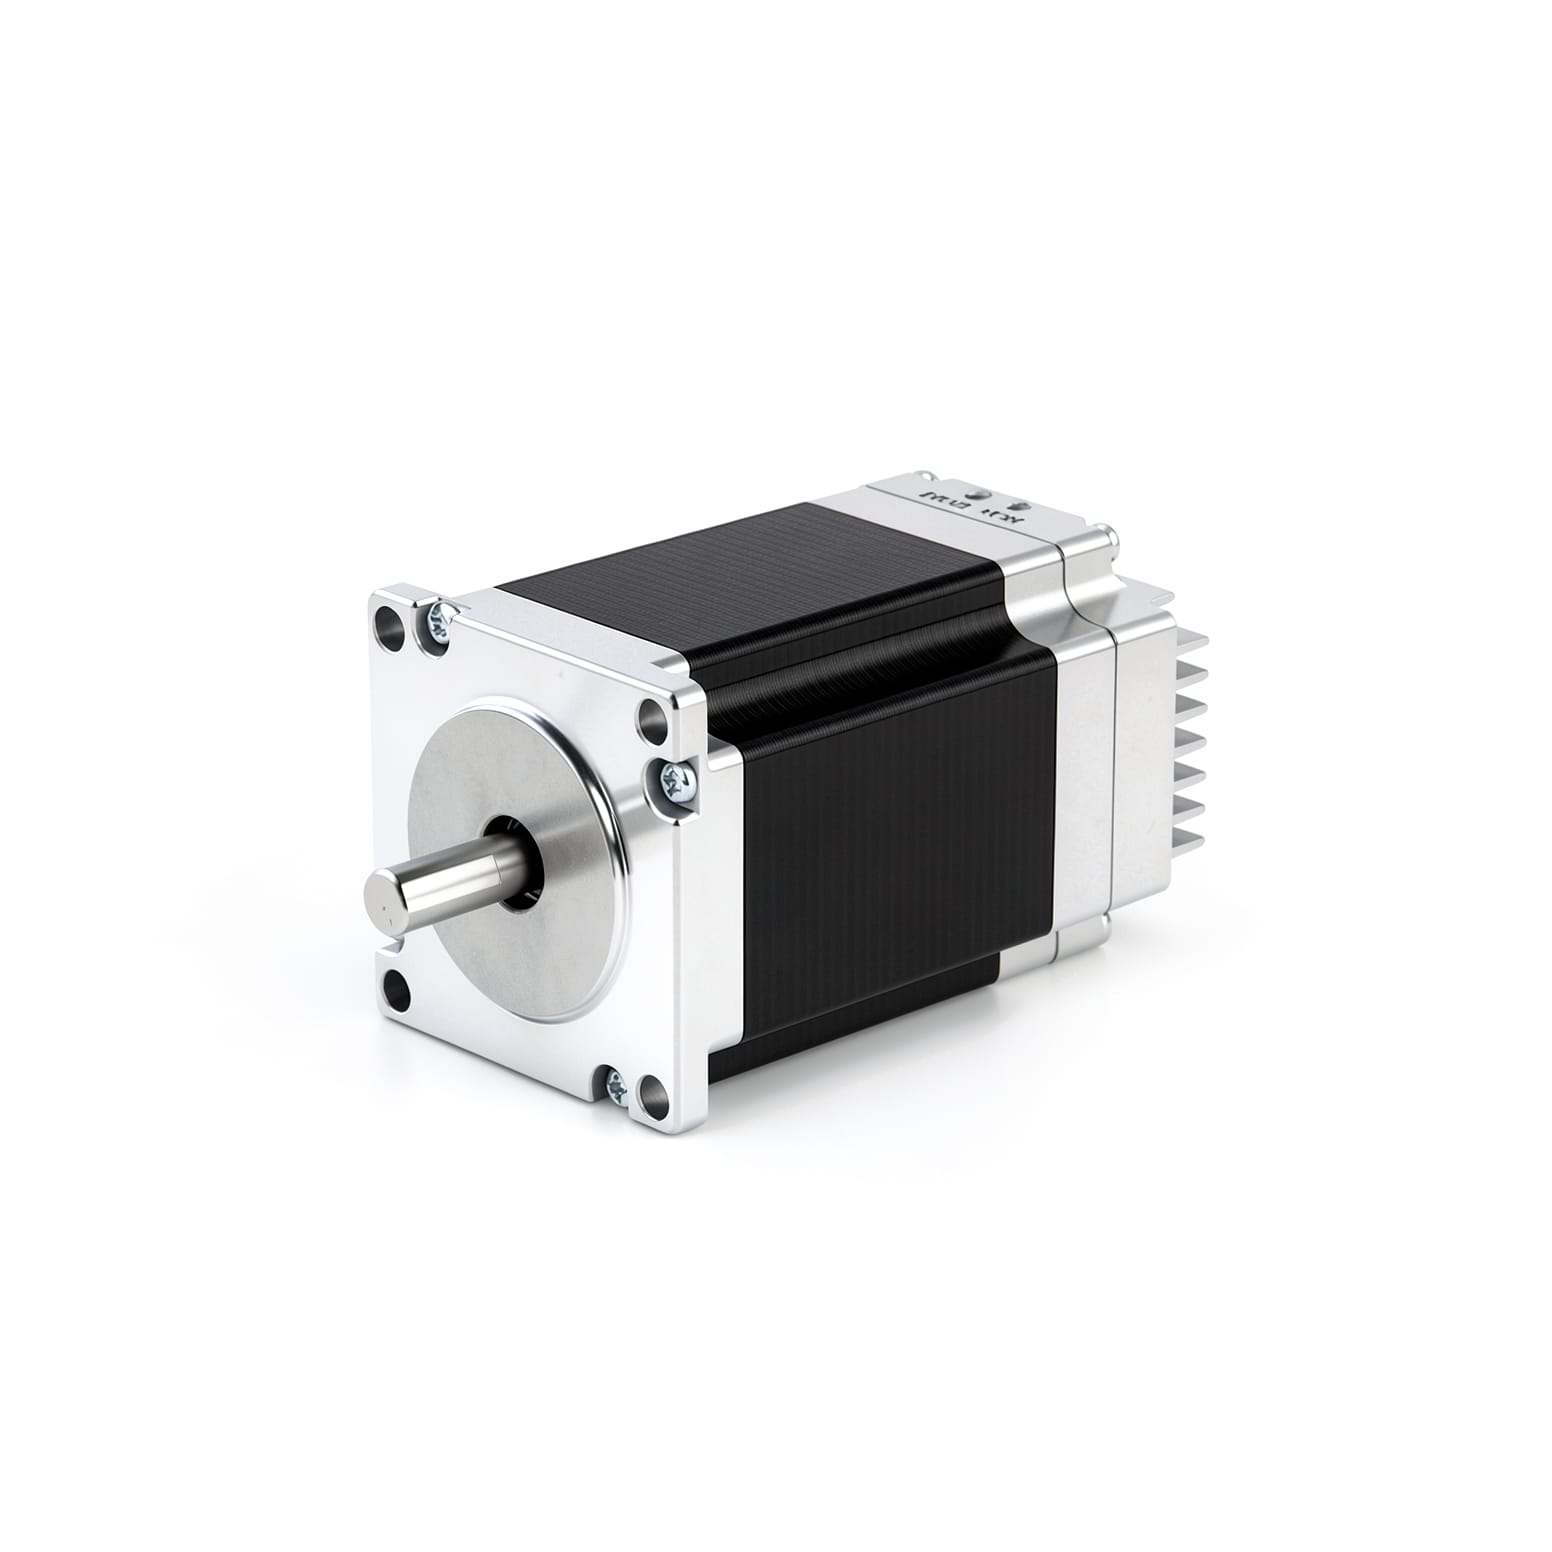
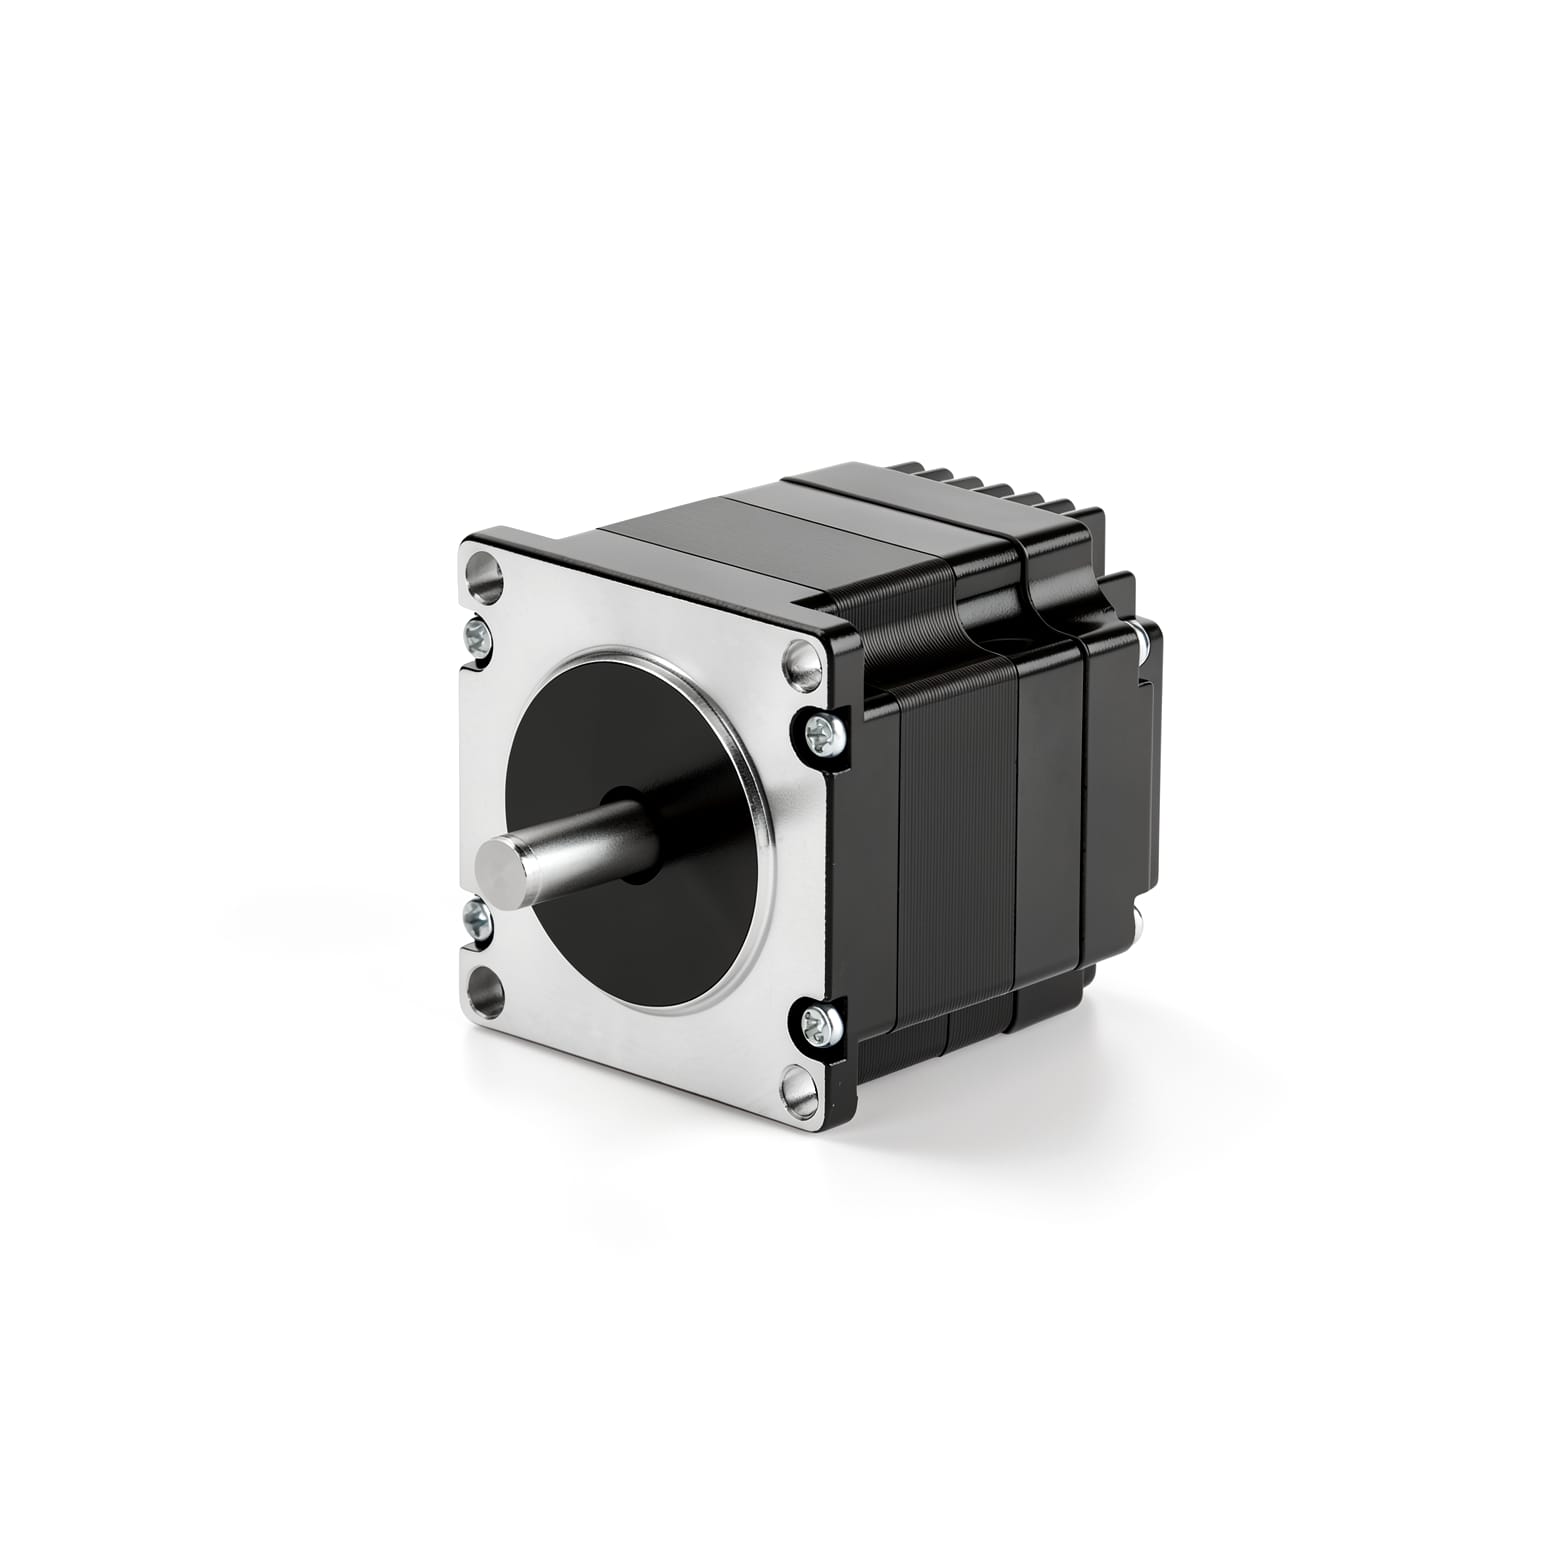
42mm flange integrated stepper motor – seamlessly combines stepper motor, driver, controller, and I/O interfaces into a single unit. Reduces wiring, lowers failure points, ensures stable motion, and is suitable for a wide range of compact automation equipment.
Features
- CAN/CANopen/RS485
- 14-bit encoder for closed-loop
- Supports DI and DO Control
Models & Specifications
| Specifications | STM4228-CAN-0FS | STM4228-CANopen-0FS | STM4228-485-0FS | STM4234-CAN-0FS | STM4234-CANopen-0FS | STM4234-485-0FS | STM4240-CAN-0FS | STM4240-CANopen-0FS | STM4240-485-0FS | STM4248-CAN-0FS | STM4248-CANopen-0FS | STM4248-485-0FS | STM4260-CAN-0FS | STM4260-CANopen-0FS | STM4260-485-0FS |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Flange Size | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm | 42mm |
| Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake | No Brake |
| Open-Loop/Closed-Loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop | Open-loop |
| Encoder Type | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder | No Encoder |
| Rated Voltage | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC | 24 VDC |
| Voltage Range | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC | 12-30VDC |
| Rated Current | 0.6 A | 0.6 A | 0.6 A | 1.3 A | 1.3 A | 1.3 A | 1.7 A | 1.7 A | 1.7 A | 1.7 A | 1.7 A | 1.7 A | 2.0 A | 2.0 A | 2.0 A |
| Inertia | - | - | - | - | - | - | - | - | - | - | - | - | - | - | - |
| Body Length | 48.5 mm | 48.5 mm | 48.5 mm | 52.5 mm | 52.5 mm | 52.5 mm | 58.5 mm | 58.5 mm | 58.5 mm | 66.5 mm | 66.5 mm | 66.5 mm | 78.5 mm | 78.5 mm | 78.5 mm |
| Weight | 0.12 kg | 0.12 kg | 0.12 kg | 0.27 kg | 0.27 kg | 0.27 kg | 0.33 kg | 0.33 kg | 0.33 kg | 0.41 kg | 0.41 kg | 0.41 kg | 0.52 kg | 0.52 kg | 0.52 kg |
* Scroll horizontally within the table area when the content is wide.
Specifications
| Shaft Diameter | Φ5 |
| Number Of Phases | 2 |
| Step Angle | 1.8° |
| Encoder Introduction | No encoder |
| Subdivision | 1,2,4,8,16 |
| Control Modes | CiA402 Mode,Manufacturer Mode,Position Mode,Velocity Mode,Homing Mode |
| External Control Interface | DI – Non-isolated NPN Input,DI – Non-isolated Switch Input,DO – Isolated Open-Drain Output,DO – Non-isolated MOSFET Output |
| CiA402 Mode | PP、VM、PV、HM、IP、CSP、CSV(via CANopen communication) |
| DI (Digital Input) | Quantity 3; Not isolated; Level input, passive contact input; Logic 1 signal: 3~3.3VDC; Logical 0 signal: 0~0.5VDC) |
| DO (Digital Output) | - |
| DX (Digital Input / Output) | Quantity 2; Not isolated; You can set it to DI or DO. High power usually 3 ~ 3.3V, low power usually 0 ~ 0.5V |
| AI (Analog Input) | - |
| Operating Temperature | 0°C to 40°C |
| Operating Altitude | <1000m |
| Fault Alarm | Overvoltage, undervoltage, overheat, locked rotor |
Torque-Speed Characteristics
STM4228(A)-CANopen-XX
STM4234(A)-CANopen-XX
STM4240(A)-CANopen-XX
STM4248(A)-CANopen-XX
STM4260(A)-CANopen-XX
Product Details
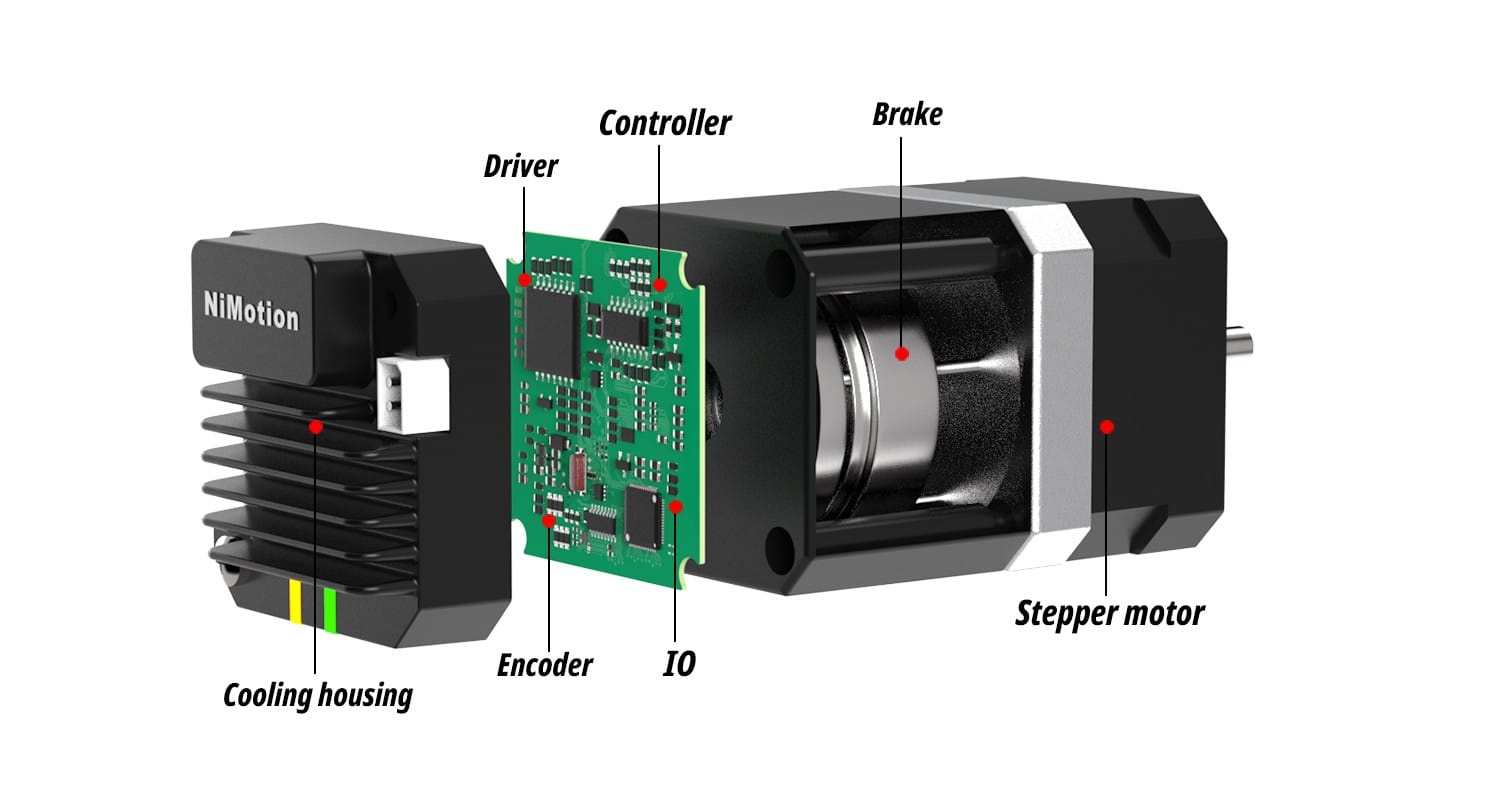
The STM42 series of integrated stepper motors is a stepper product independently developed by NiMotion. Leveraging its excellent closed-loop control system and integrated design concept, it combines stepper motors, encoders and drivers into one unit. It supports bus communication control with compact size and simplified cabling.
Product Features
Highly integrated design
All-in-one design deeply integrating the motor body with the drive and encoder, giving a compact body, simple wiring and easier machine integration.
High Precision Encoder Feedback
Built-in 14-bit high-resolution absolute encoder (closed-loop support) provides real-time position and speed feedback for more accurate closed-loop control, ensuring smoother operation and more accurate positioning.
Multi-bus communication support
Supports CANopen and RS485 communication, allowing quick connection to mainstream PLCs, motion controllers and host systems, with flexible networking and easy expansion.
Standard CiA 402 Sport Mode
Supports CiA 402 standard motion modes (PP, PV, HM, CSP, CSV, etc.) as well as position mode, velocity mode and homing mode, ensuring compatibility with mainstream fieldbus motion-control architectures and making replacement and commissioning easier.
Wide Voltage Input
Wide input voltage range of 12 ~30VDC, suitable for various power-supply environments and giving greater flexibility in system integration and retrofitting.
Segment can be set
Micro-stepping setting of 1、2、4、8、16 steps selectable effectively reduces low-speed vibration and noise and improves positioning resolution and smoothness.
Overall Dimensions
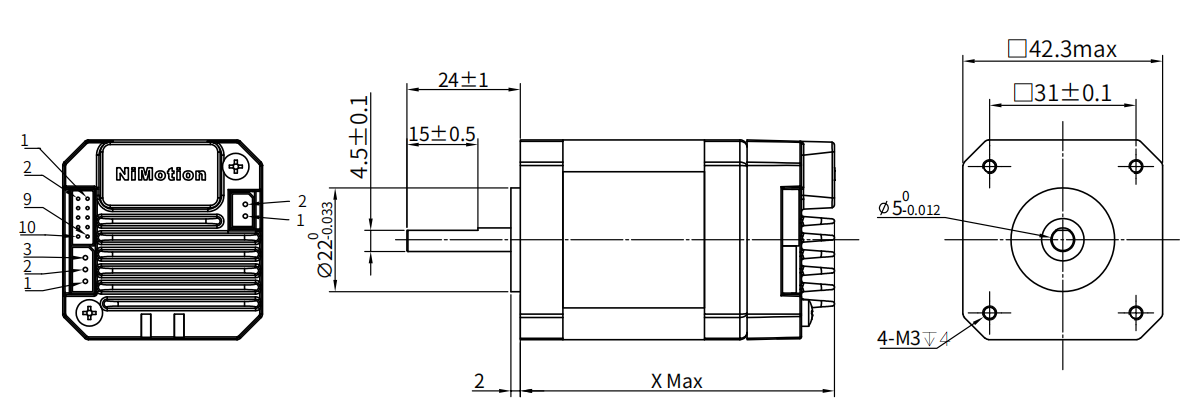
Base width: 42mm, X represents the body length. Please click the "Download" section below to view detailed drawings.
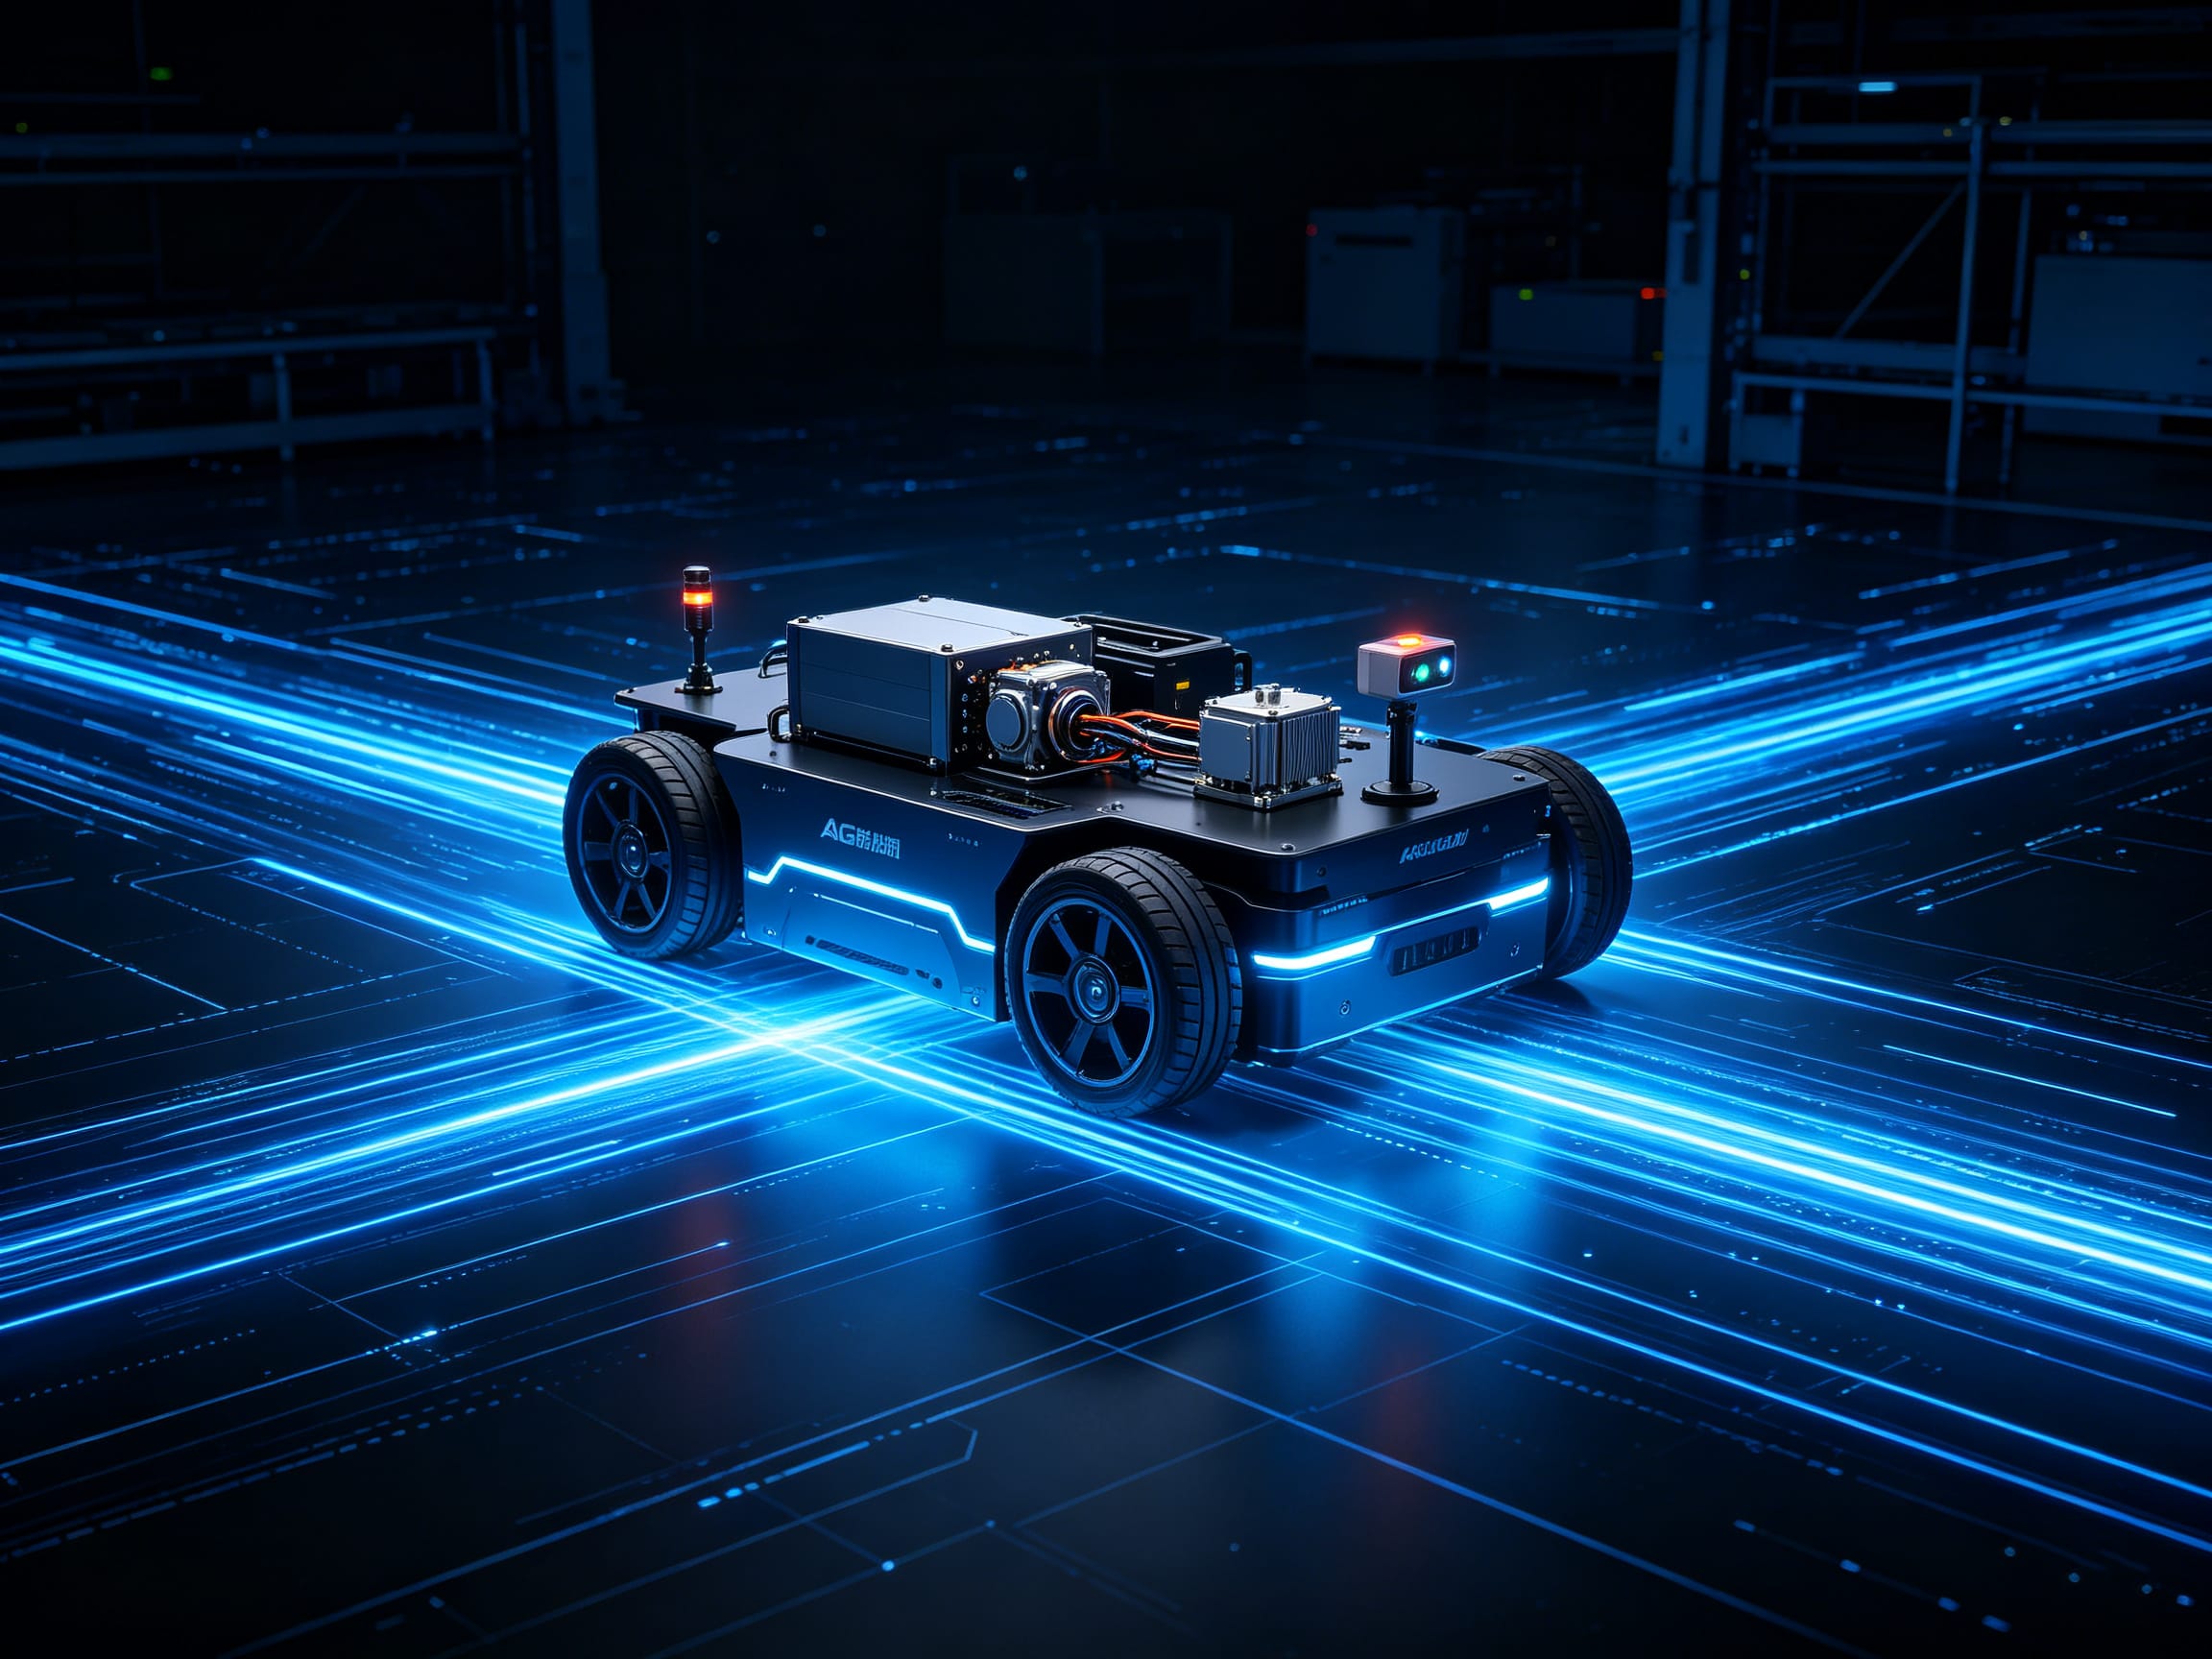
Application in AGV Equipment
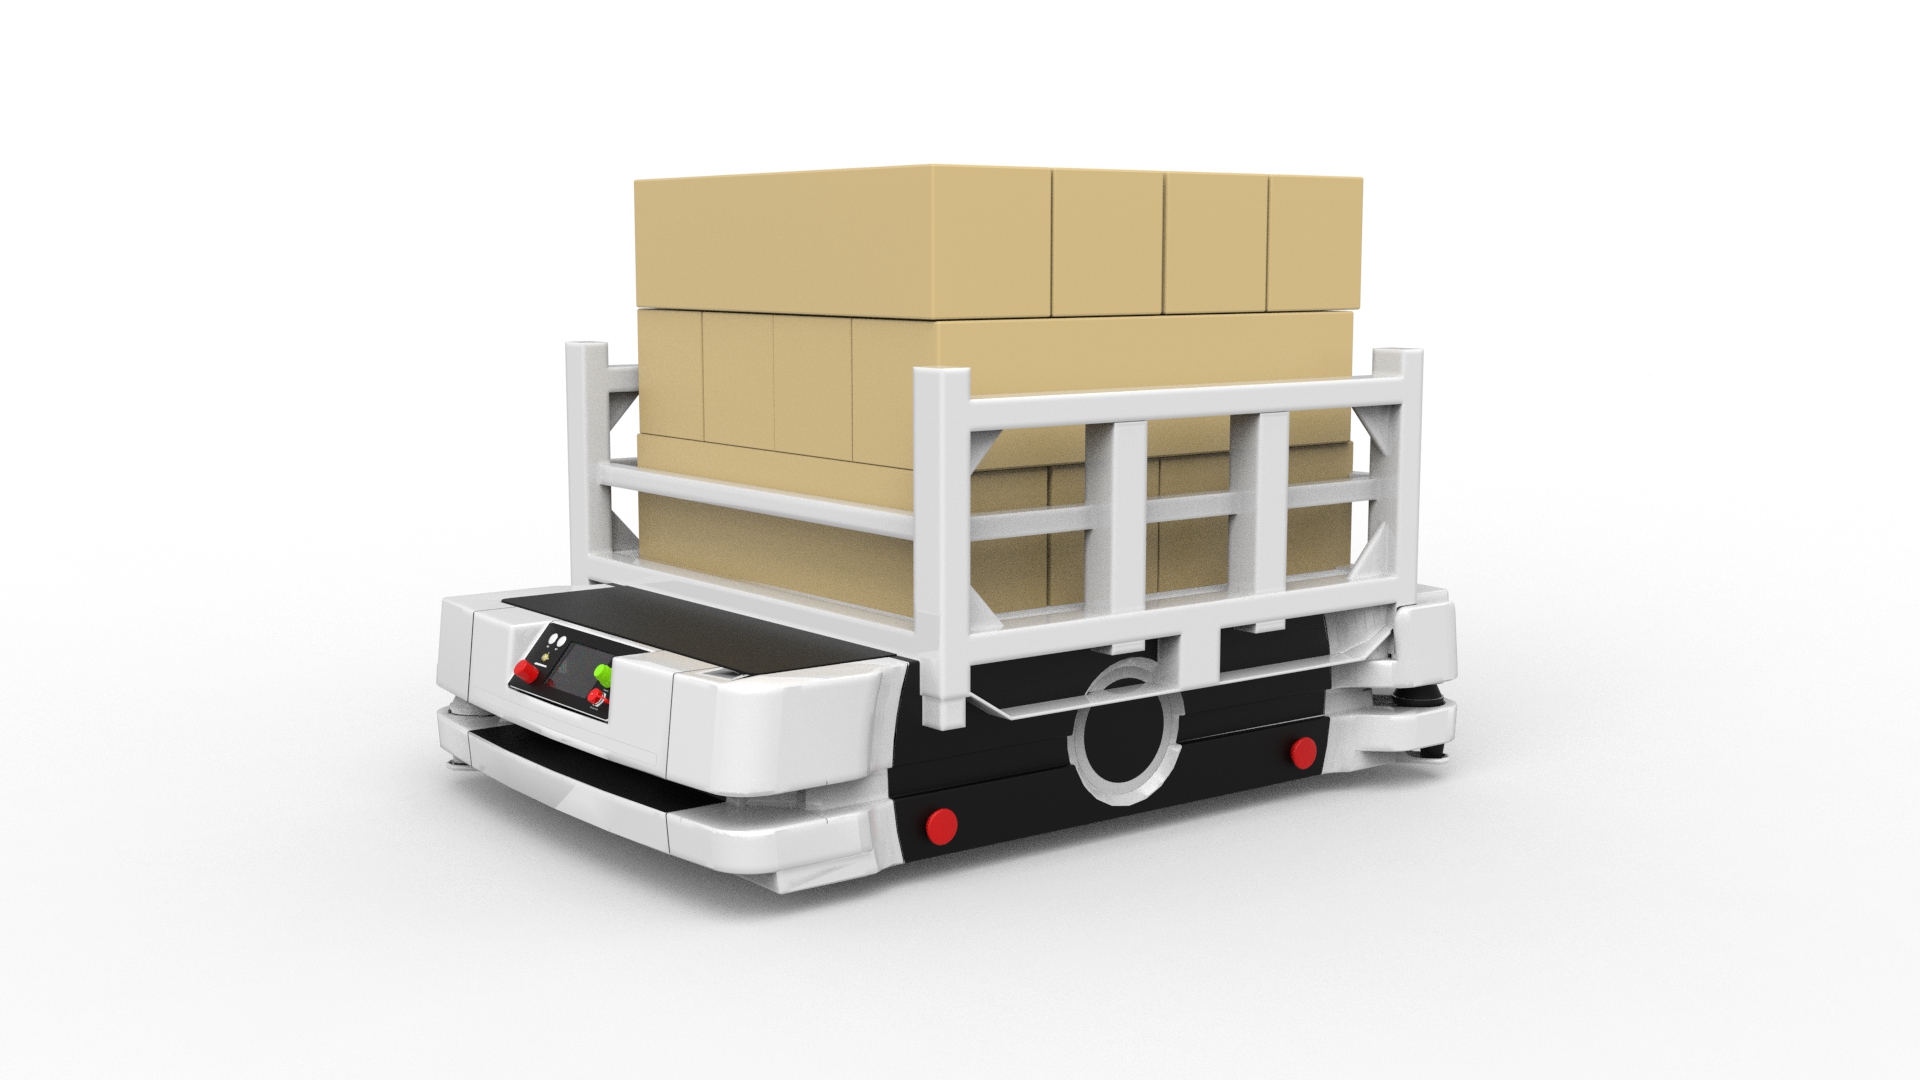
This integrated Stepper motor series is applicable to AGV drive wheels, steering actuators, lifting platforms, and fork positioning mechanisms. Its compact integrated design saves vehicle space, leaving more room for batteries and cargo. Built-in encoder enables full closed-loop control, adapting to floor irregularities and load variations. Multiple communication protocols are supported for compatibility with various navigation systems.
Downloads
Companion Products
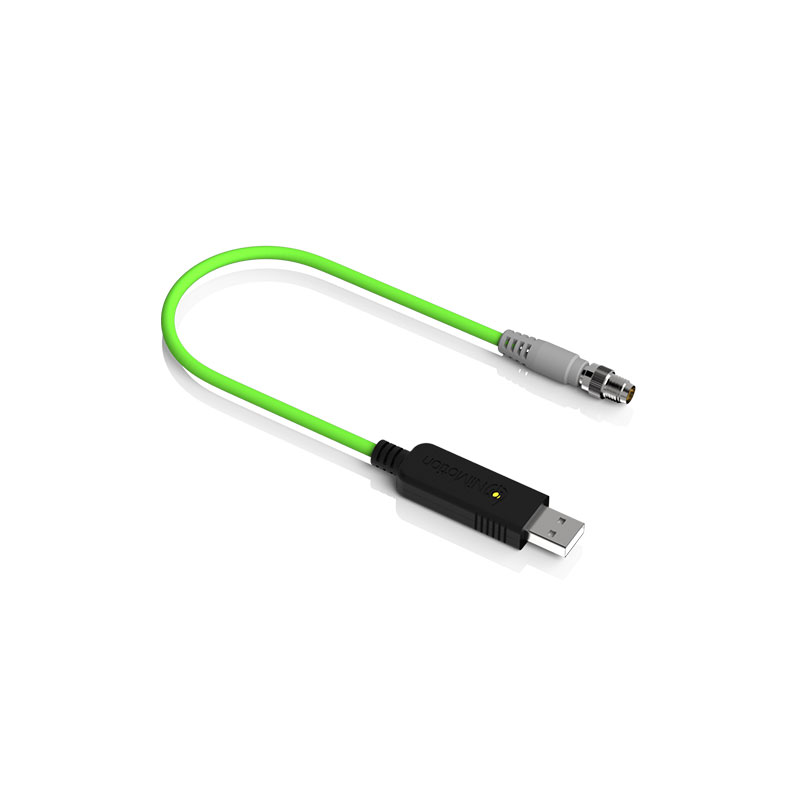
USB to CAN converter with isolation, IP65 protection, and secondary development SDK support.
USB to RS485 converter with active termination, isolation, IP65 protection, and secondary development SDK support.
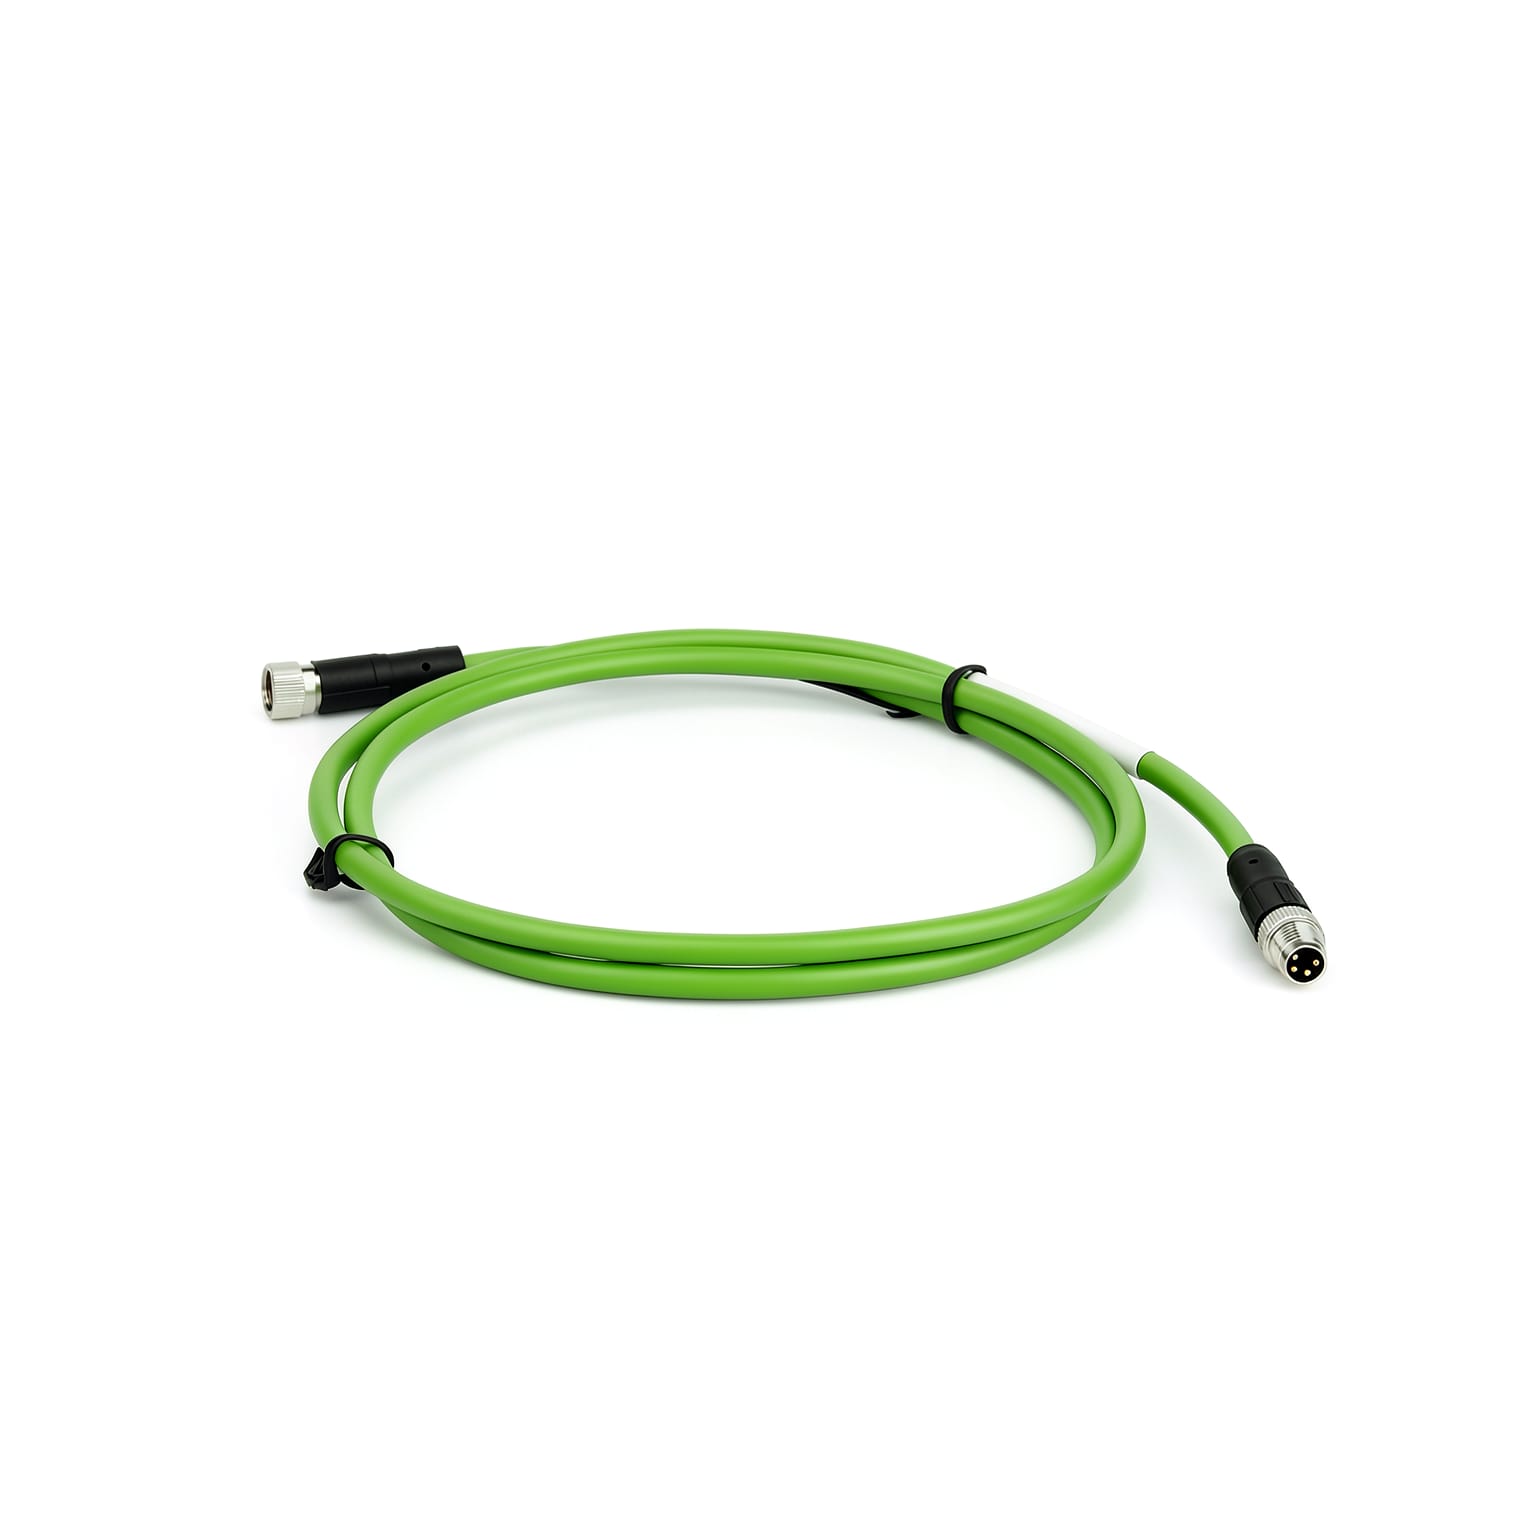
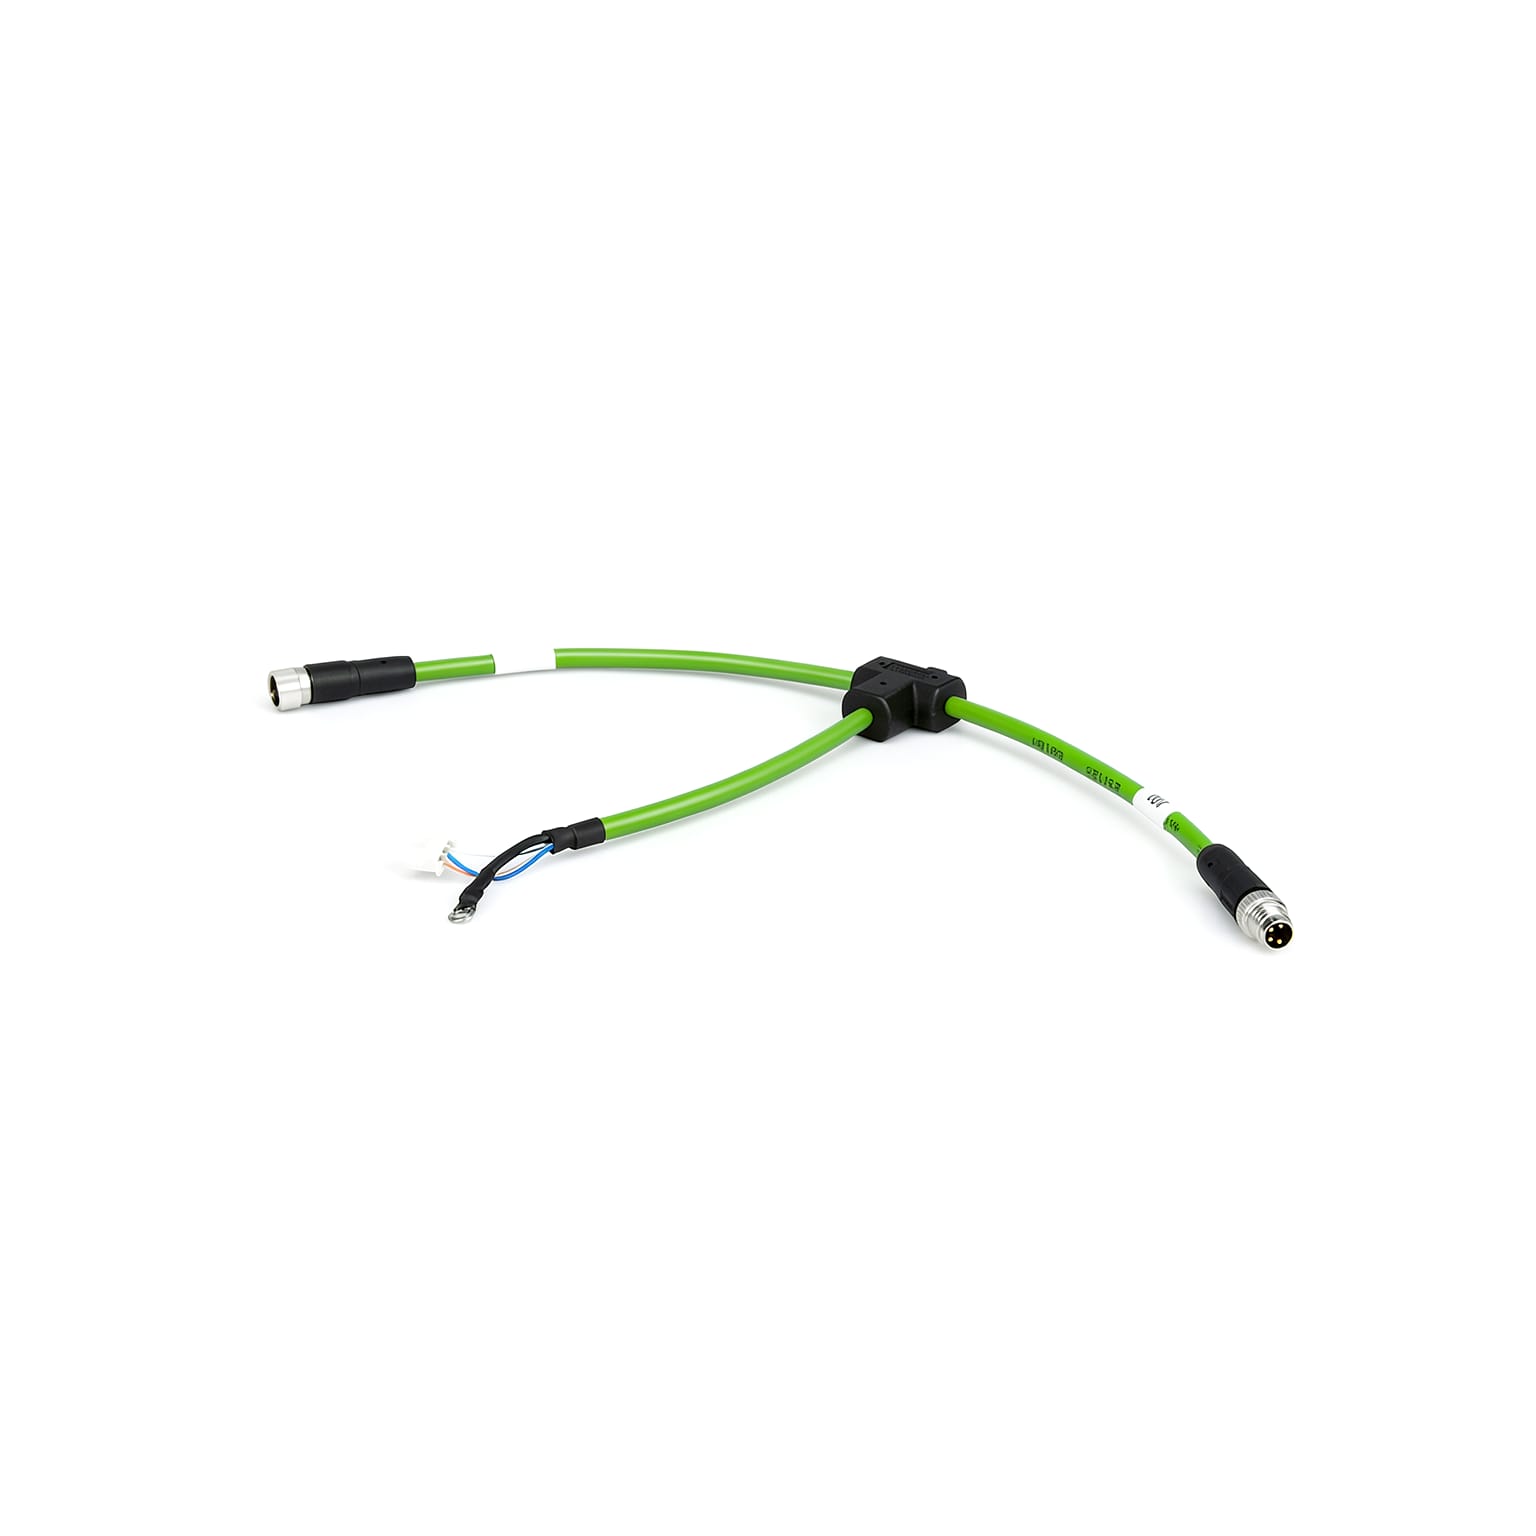
Communication cable for NiMotion integrated motors.
FAQ
Integrated stepper/servo motors combine the motor, driver, and encoder in one compact unit. They offer a smaller footprint, simpler wiring, reduced installation space, and fewer potential failure points. They also simplify commissioning and maintenance, making them ideal for automated equipment where space and reliability are critical.
A motor housing temperature of 80–90°C is completely normal.** Excessively high temperature demagnetizes the magnetic material and reduces torque; magnetic materials generally demagnetize around 130°C. A rough judgment: if you can keep your hand on it for more than 3 seconds, it is usually < 70°C; if you pull your hand away on contact, it is generally above 80°C. Use a thermometer for precise measurement.
Ball is **point contact** with low friction and high speed, but lower load capacity and rigidity — suitable for general automation, semiconductor and medical. Roller is **line contact** with far higher load capacity and rigidity than a ball guide of the same size, but a slightly lower maximum speed — suitable for heavy-load, high-rigidity applications such as large machine tools, stamping and automotive lines. **Criterion: heavy load and high rigidity → roller; high speed and general use → ball.** --- **Further Reading** - [Planetary Gearbox Working Principle and Selection: Reduction Ratio, Backlash and Inertia Matching](./16_行星减速机原理与选型_en.md) - [Integrated Leadscrew Motor (Leadscrew Stepper Motor) Selection Guide](./18_一体化丝杆电机选型_en.md) - [Servo Motor Selection Step-by-Step: From Load Torque to Inertia Matching](../01_选型对比/02_伺服电机选型步骤详解_en.md)
Both domestic and international players have a presence. International brands focus mainly on low-voltage servo modules; among domestic brands, manufacturers such as Limaisheng NiMotion offer a full range of **integrated low-voltage stepper/servo/brushless** products from 20mm to 86mm frames, covering DC 24V and 48V, supporting CANopen, RS485, and EtherCAT buses, and widely used in AGV, medical, and robotics fields. When selecting, focus on verifying: power range coverage, protection rating, encoder type, bus protocol, and master compatibility.
For ball guides use **L = (C / P)³ × 50 km** (L in km, C is the basic dynamic load rating, P is the equivalent dynamic load); for roller guides the exponent is **10/3**. Key insight: **halving the load increases life 8×** — so underestimating the load by a little causes life to drop off a cliff.
Applications
Discover how this product is applied across various industrial automation scenarios.
Compatible Products
Build complete and reliable solutions with our compatible products.
Technical Resources
Technical guides, application notes, and more to help you get the most out of the product.
Ready to start your automation project?
Talk to our engineers and get a customized motion control solution within 24 hours.
Typical response time: 24 hours